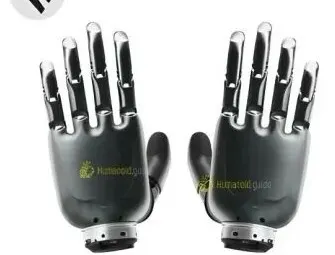
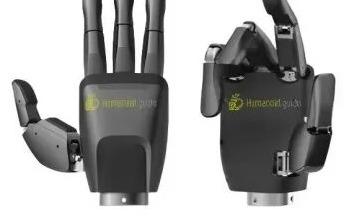
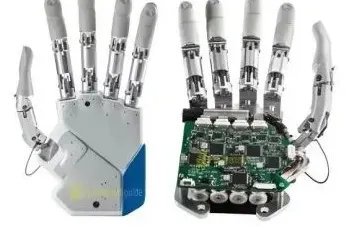
OceanTrix robotic hand for underwater and complex environments.
Paxini five-finger hand integrating tactile sensing and force control.
WiRobotics five-finger hand for service and industrial robots.
Prensilia bionic hand for research and prosthetics.
Unitree five-finger dexterous hand at 1100 g with 20 DoF (16 active: 4 thumb + 3 per finger), ±22° four-finger abduction, 10 mm minimum grasp diameter, ±1 mm fingertip repeatability and 10 N per-fingertip force; hollow-cup motors with low-backlash reducers, all joints back-drivable and fingers individually replaceable; 24-60 V supply (58V@0.2A static, 58V@4A peak), USB 2.0, -20~60°C; palm-down load 3.5 kg / palm-sideways 4.5 kg on a 5 cm rigid object; Dex5-1P adds 94 tactile sensors (palm 2×5, finger-belly 5×2×3, fingertip 5×2×3, finger-base 4×2×3 arrays).
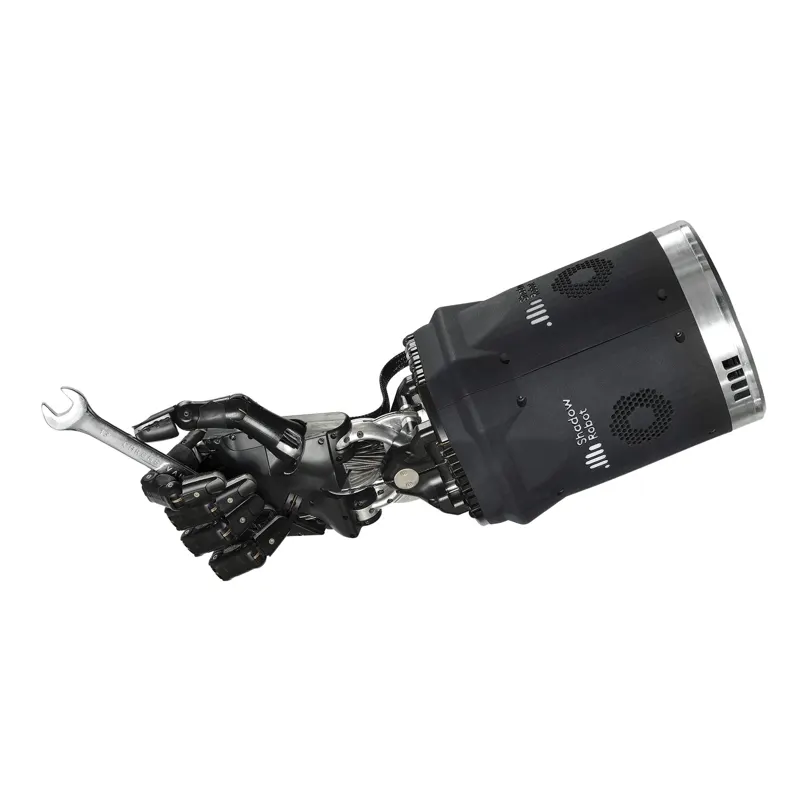
Three-finger electric hand co-developed by Shadow Robot and Google DeepMind for real-world machine learning, weighing 4.1 kg at 350 mm tall with 12 DoF and billed as the most robust dexterous hand on the market. High-bandwidth torque and position control loops deliver delicate fingertip dexterity; torque and inertial sensing throughout the hand plus optical tactile sensors with hundreds of taxels per finger and multi-taxel 3-DoF tactile on middle/proximal phalanges. Built for long-running RL: long mean time between failures, repeated-impact resistance, user-maintainable design with fail-safes and graceful shutdown, fully ROS integrated. DEX-EE Chiral variants (Left/Right/Bi-Manual Pair) offer human-like kinematics for teleoperation and bi-manual imitation learning.
Bionic dexterous hand from BrainCo weighing 383 g and standing only 160 mm tall, about the size of a smartphone, with 11 DoF (6 active joints), 0.1° control precision and up to 1 kHz communication. It carries ≥20 kg per hand with ≥50 N five-finger grip and ≥15 N pinch, runs on 12-64 V over RS485 / CAN FD / EtherCAT with current, stall, thermal and collision protection, ships Python/C SDKs for Linux/Windows/ROS and supports OTA. Offered in Base, Pro and Tactile editions; the Tactile edition adds pressure, friction, direction and proximity sensing with tactile adaptive control.
Five-finger hand for robot end-effectors and prosthetics.
Paxini tactile hand with multi-dimensional tactile sensing.
Inspire Robots RH56DFX series humanoid five-finger dexterous hand, offered in wrist-less (RH56DFX-2L/2R) and wrist-equipped (RH56DFXW-2L/2R) variants with 6 DoF (6+2 with wrist), 12 finger joints and an RS485 control interface. Human-hand sized at only 540 g / 650 g. Up to 1.5 kg single-finger active force, 15 N max thumb grip, 10 N max four-finger grip with 0.5 N grip-force resolution, and ±0.20 mm repeatability. Thumb lateral rotation >65°, thumb lateral speed 107°/s, thumb flexion 70°/s, four-finger flexion 260°/s; wrist models add ±27° lateral and ±22° pitch with 2 N·m torque (excluding hand weight). Runs on DC24V±10% with 0.09 A / 0.1 A quiescent and 2 A max current — a compact end-effector for humanoid robots.
Alt-Bionics low-cost bionic hand for prosthetic and assistive applications.
OyMotion EMG-controlled hand for prosthetics and robotics.