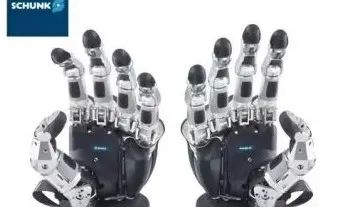
SCHUNK five-finger hand; industrial-grade reliability, widely used in research and automation.
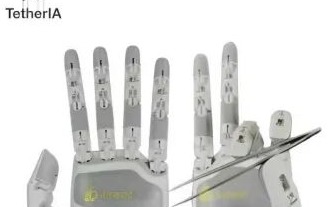
TetherIA five-finger dexterous hand for research and commercial applications.
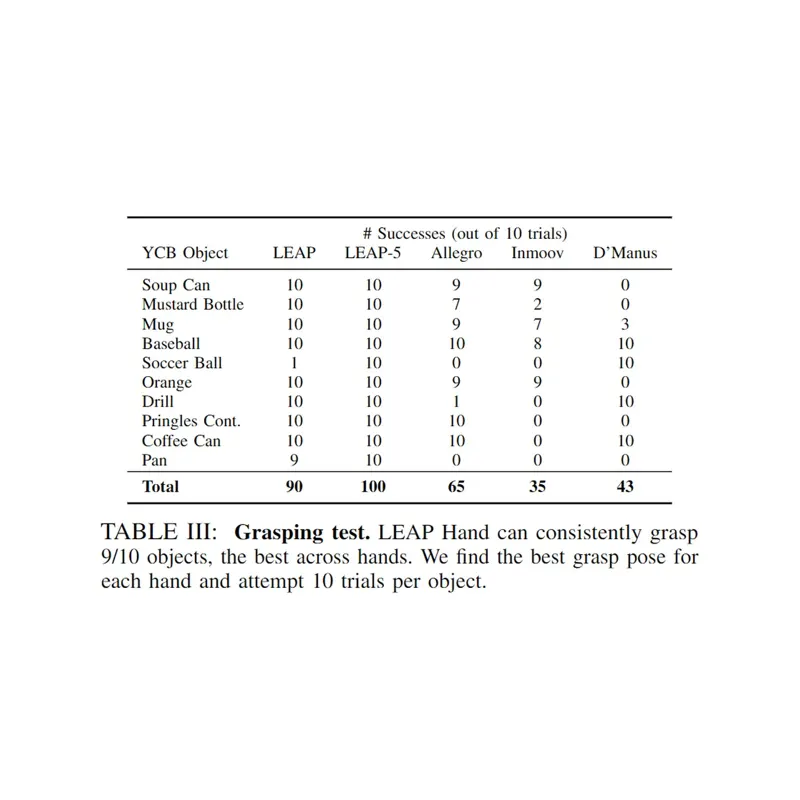
LEAP Hand is an open-source four-finger dexterous hand from Carnegie Mellon University (Kenneth Shaw, Ananye Agrawal, Deepak Pathak; RSS 2023): 16 DoF (4 per finger) at a total cost under $2,000, assemblable in under 3 hours using only common hand tools, and roughly 1/8 the cost of the Allegro Hand while achieving superior dexterity thanks to universal abduction-adduction kinematics. The project releases the URDF model, 3D CAD files, a tuned Isaac Gym / Isaac Lab simulation environment and Sim2Real training code, making it a popular low-cost platform for grasp and manipulation research, teleoperation and 3D-printable replication.
The Allegro Hand V4 from Wonik Robotics (Korea) is a four-finger dexterous hand for grasp and manipulation research and education: 3 fingers plus an opposable thumb with 16 independent torque-controlled joints (4 per digit), driven by DC motors with torque/current control and a 1:369 reduction ratio, delivering 0.70 N·m max joint torque and 0.11 s/60° joint speed. It weighs just 1.08 kg total (0.17 kg per finger, 0.19 kg thumb), features 0.002° potentiometer resolution, 333 Hz CAN communication, 5 kg payload capacity, and runs on 24 V / 100 W. With full APIs and tutorials for Windows / Linux / ROS / ROS 2 and 180+ research partners publishing with the platform, it is one of the most widely used research dexterous hands.