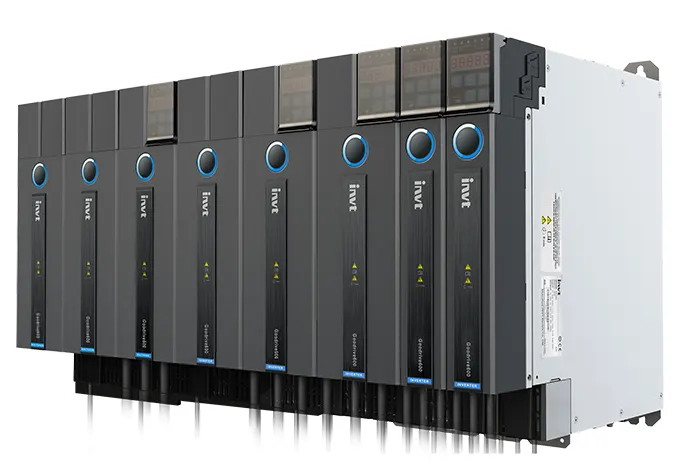
GD600 Series High-Performance Multi-Drive Inverter is a common DC bus multi-drive system, which adopts the book-type unit structure and integrated bus control. It features high power density, flexible communication networking, and strong extensibility, manifesting its incomparable advantages. Features: 1.Integrating the safe torque off (STO) function. 2.Compatible with the mainstream fieldbus of 1 MB to 100MB. 3.Integrating torque control, speed control, and position control. 4.Implementing the driving control over asynchronous. 5.induction motors and permanent-magnet synchronous motors. 6.Outstanding dynamic responding and control precision.
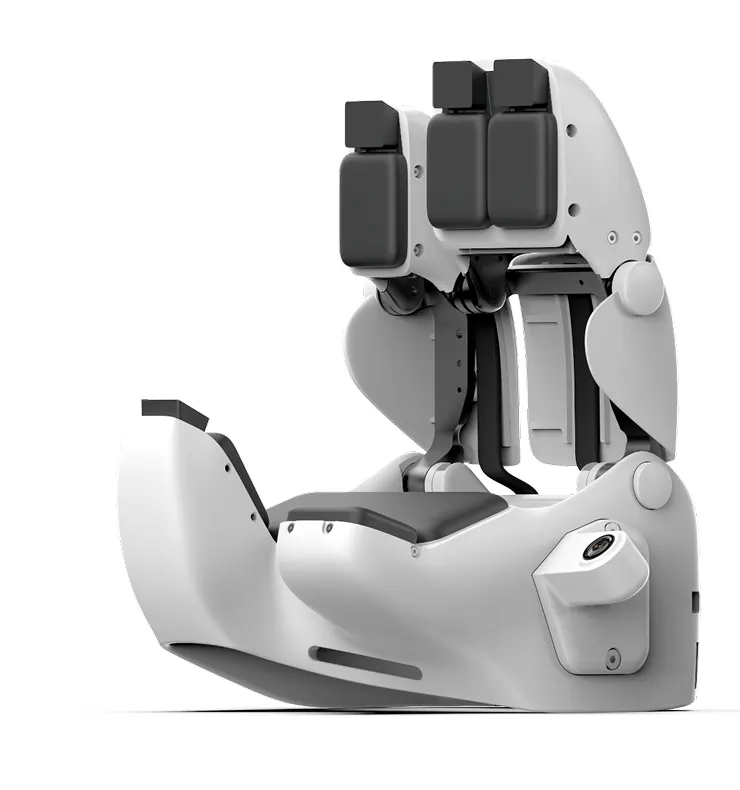
Three-finger data-capture glove with tactile, visual and proprioceptive sensing ## Overview PXCap III is PaXini's three-finger embodied-AI data-capture glove. It is physically isomorphic with the PXDex III execution end-effector, aligning tactile, visual and proprioceptive data for direct collection-to-deployment workflows. ## Highlights - 1:1 physical isomorphism with PXDex III - Full-area tactile sensing across fingertips, finger pads and palm - Proprietary high-precision anti-magnetic encoders - Dual palm cameras with 170-degree field of view - 650 g weight and four degrees of freedom - 0.1 N tactile-force accuracy - Encoder accuracy of ±0.15 degrees - Dual 1080p RGB cameras at 30 fps - Wrist-positioning accuracy up to 5 mm with VR headset and controller - USB communication and 12 V DC power ## Applications Embodied-AI data collection, teleoperation, imitation learning and cross-platform dexterous-manipulation training.
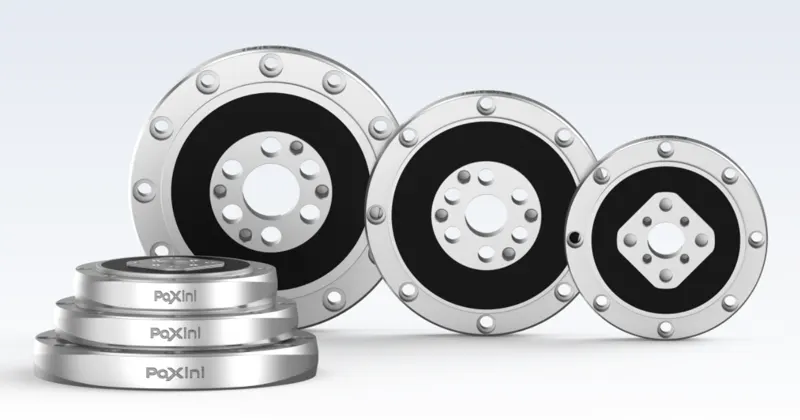
Intelligent Hall-effect joint torque sensor with proprietary 3-axis sensing ## Overview PX3Q is PaXini's Hall-effect joint torque sensor series for embodied-AI robots, collaborative arms and industrial equipment. It extends conventional single-axis torque sensing to proprietary three-axis torque measurement. ## Highlights - Proprietary 3-axis torque sensing - 0.1% FS resolution and repeatability - 0.5% FS overall accuracy - 1000 Hz sampling rate - Torque ranges of ±30, ±50 and ±100 N·m - 50, 60 and 70 mm diameter options - IP64 protection, customizable to IP67/IP68 - RS485, CAN FD, EtherCAT and USB communications - Digital output with integrated diagnostics ## Applications Humanoid-robot joints, collaborative robot arms, aerospace, automotive manufacturing, rail transit and energy equipment.
Six-degree-of-freedom modular hand with 175 N grasping force RY-H5 is a six-degree-of-freedom, 15-joint dexterous hand designed for high gripping force and reliable industrial operation. Its coreless brushless motors, ball-screw transmission and modular finger structure combine stiffness, precision and fast response.
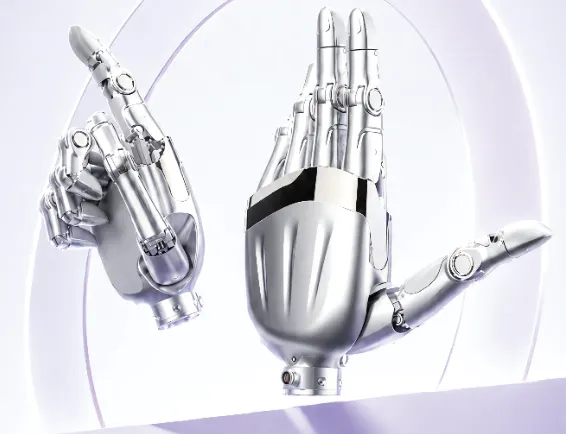
Sixteen-degree-of-freedom bionic hand with optional tactile sensing RY-H1 is a highly bionic dexterous hand with 16 degrees of freedom and 21 motion joints. Sixteen high-speed precision coreless brushless motors and a proprietary force-position control algorithm enable adaptive grasping and detailed human-like gestures; a tactile version is also available.
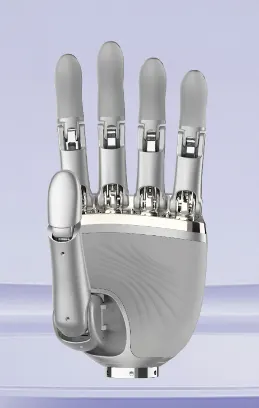
Compact six-degree-of-freedom hand with standard and high-speed configurations RY-H2 is a compact dexterous hand with six degrees of freedom and 11 motion joints. Six high-speed, high-power-density coreless brushless motors provide rapid response, while standard and high-speed configurations address heavy-duty grasping and fast manipulation needs.
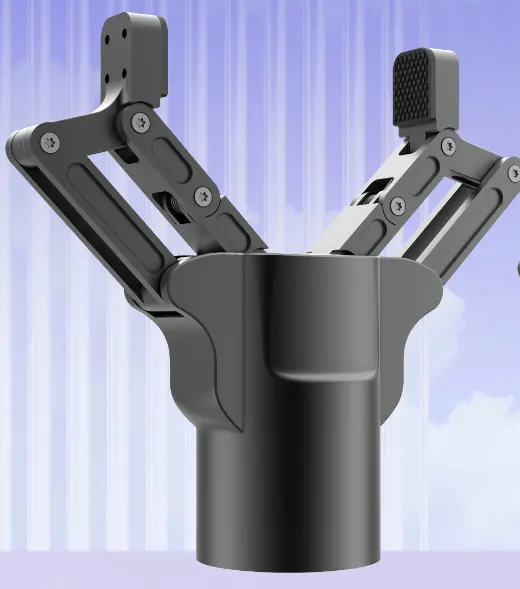
Long-stroke parallel gripper for stable high-load handling RY-G1 is a long-stroke force-controlled electric gripper family for stable handling of objects with different sizes and loads. Three configurations combine wide opening travel, precise repeatability and screw-driven transmission for industrial robot applications.
278 g compact hand for confined-space and small-robot manipulation RY-H6 is a compact and lightweight dexterous hand for small humanoid robots, confined spaces and light-duty mechanisms. A coreless brushless motor architecture combines compliant transmission, force sensing and precise force control in a 278 g package.
Compact MCEA series with high energy density and precise positioning The MCEA miniature linear-stage cylinder combines a compact 35 mm body with programmable position, speed and thrust for handling, arranging and transport tasks.
VLA Series Compact direct-drive linear coil actuators for precise, smooth motion and soft landing in semiconductor, optoelectronic and precision-assembly applications.
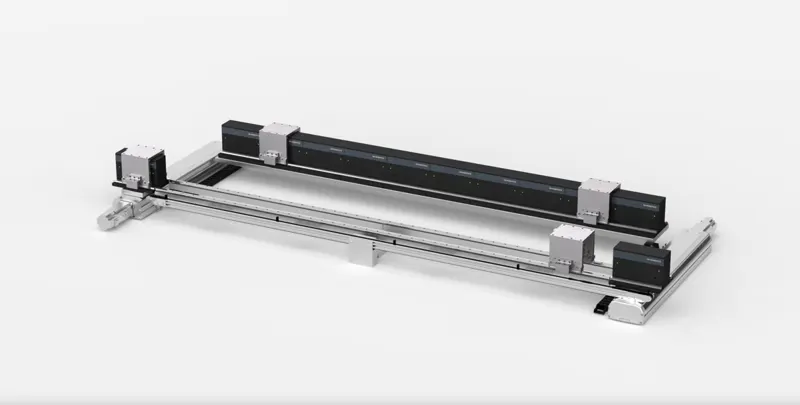
iFM Intelligent Flexible Motion System A modular high-speed, high-precision intelligent transport system offered in horizontal and vertical layouts, with belt or electromagnetic return options.
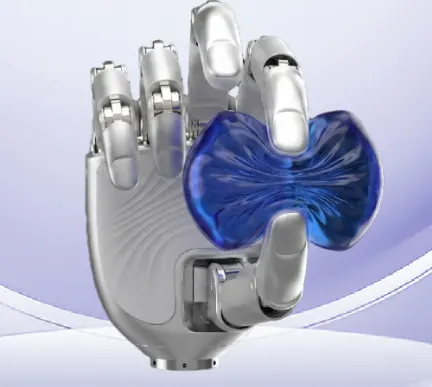
Touch the Future, Unleash Dexterity Without Limits An 11-DOF five-finger dexterous hand designed for reliable, high-frequency manipulation, with optional tactile sensing for adaptive gripping.