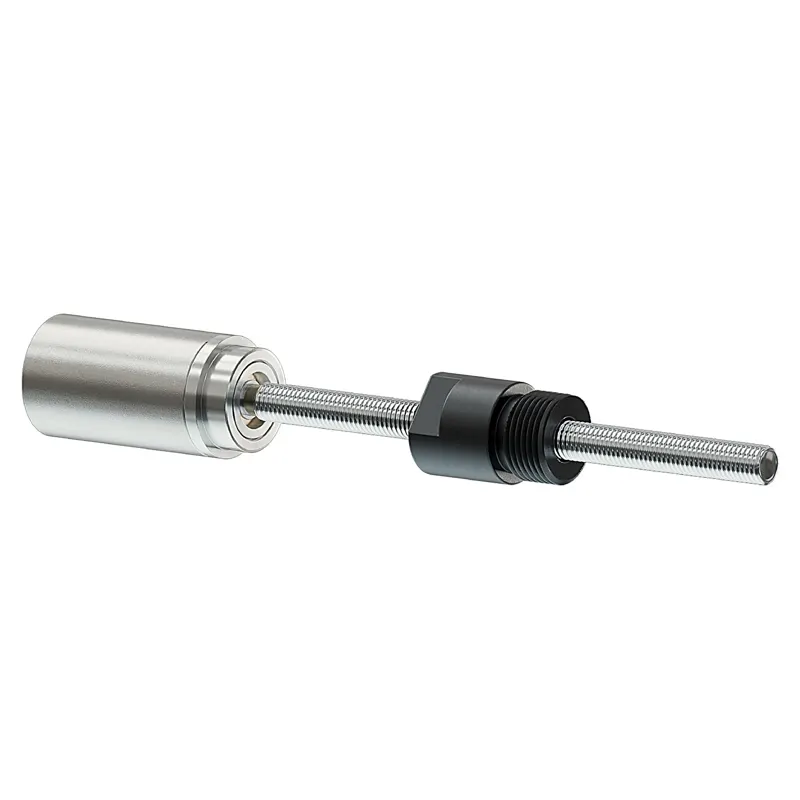
FAULHABER (Germany) linear actuators convert coreless DC / brushless rotary motion into linear travel via precision lead or recirculating ball screw nuts: 06L (6 mm dia, 3-25 N continuous axial force), 08L (8 mm, 4-40 N) and 10L (10 mm, 5-200 N; high-load HL version 100-200 N), with reduction ratios 4-1024; trapezoidal lead screw and ball screw nut options (ball version for higher speed/efficiency), custom stroke and length, paired with 0308-1028 DC/BL micro motors (up to 90,000 r/min) and planetary/spur gearheads (i 4-4096, zero-backlash versions), used in robotics, laboratory automation, medical and optical positioning.
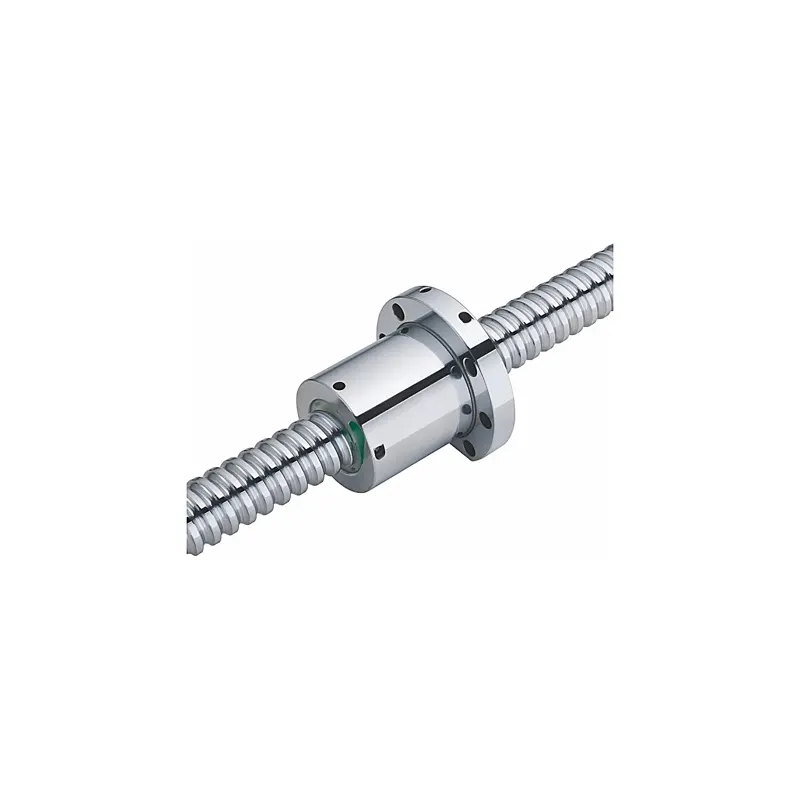
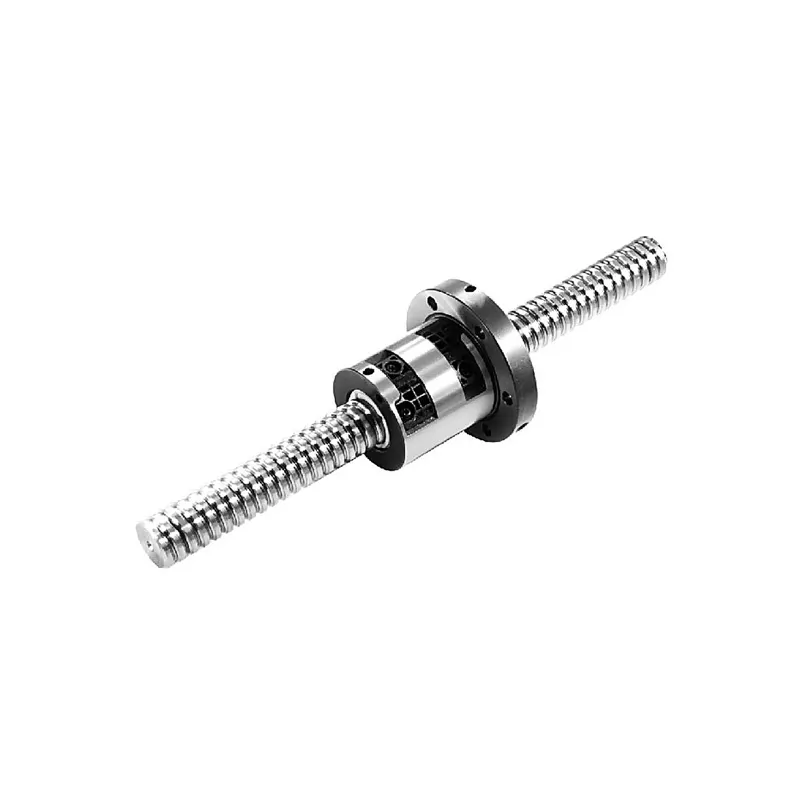
HIWIN Super S series are high-speed quiet ballscrews with Dm-N up to 220,000, 5-7 dB lower running noise and 18-32% less space/weight; the FSC standard type covers Ø14-25 shafts with 8-20 mm leads, e.g. 20-8K5 at Ca 2960 kgf / C0a 6505 kgf / axial stiffness K 58 kgf/μm and 25-15K5 at Ca 1980 kgf / C0a 5730 kgf, series-wide Ca 920-2960 kgf and stiffness 24-63 kgf/μm, targeting humanoid robot linear joints, semiconductor equipment and high-speed precision drives.
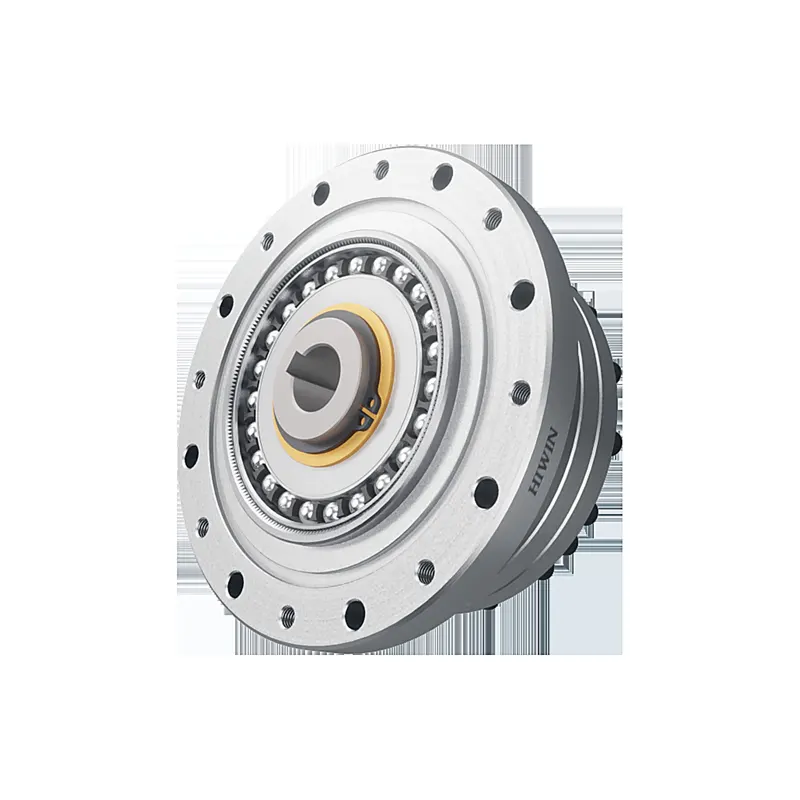
HIWIN (2049.TW) DATORKER DSC series are standard strain wave gear component sets in sizes 11-40 with 50-160 ratios, 3.5-294 N·m rated torque at 2000 r/min input, peak start/stop torque up to 647 N·m, instantaneous permissible torque up to 1180 N·m, max input speed 8500 r/min, angular transmission accuracy ≤1 arcmin (ratio ≥80), backlash down to 5 arcsec and rated life 7000 h (L10) / 35000 h (L50); the family adds lightweight (-40% weight, 36 mm hollow), heavy-load (+30% torque, 10000 h) and rotary-actuator (±6 arcsec repeatability) variants for humanoid robot joints and precision automation.
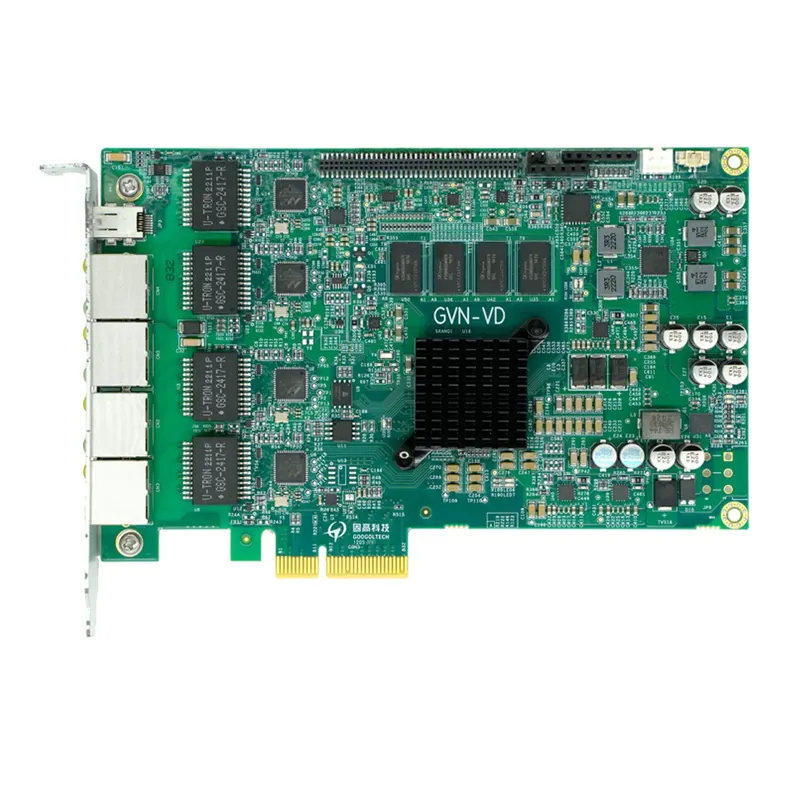
Googol Tech (SZ 301510) GVN series plug-in high-performance networked motion controller built on a multi-core processor, supporting high-speed gLink-II, general gLink-II and EtherCAT; high-speed gLink-II closes the loop on 8 axes at a 50 us cycle with built-in position/velocity loops plus feedforward and filtering algorithms, while general gLink-II/EtherCAT scale to 256 axes with position compare, PSO and laser galvo control and standard EtherCAT peripheral compatibility; targeting semiconductor, laser processing, PCB drilling/milling, robotics and CNC machines.
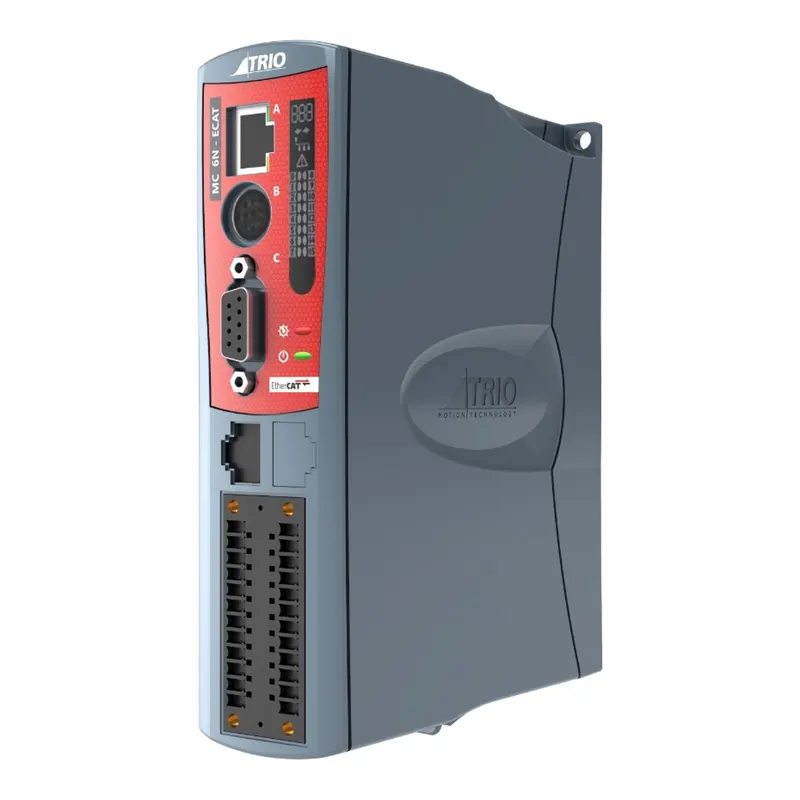
Estun (SZ 002747) MC6N series EtherCAT motion controller built on Trio technology, P960-P965 covering 2-64 axes with a 1 GHz dual-core Cortex-A7, 128 MB DDR3 plus 128 MB NOR Flash, TrioBASIC and IEC 61131-3 programming, Biss/EnDAT/SSI absolute encoder interfaces and 4 high-speed color-mark inputs; aimed at multi-axis humanoid joint coordination and high-precision line motion control.
Azure Lithium (TenPower) high-rate cylindrical Li-ion cell family spanning 27 models on the Phi-18/21/26 platforms, 1.5-7.0 Ah at 3.2-3.6 V nominal with up to 50 A continuous discharge across NMC/NCA/LFP chemistries, UN38.3 certified; serving power tools, garden tools, cleaning robots and light mobility, and matching the high-rate power demands of humanoid robots and quadruped robot dogs.
The SFV is TBI Motion's (Taiwan) external-circulation heavy-load ball screw series: smooth external ball recirculation and a patented high-load nut deliver high rigidity and high capacity, with an economical design suited to volume production and large diameter/lead applications. The range spans Ø12–Ø80 mm shafts and 4–25 mm leads across 82 models; representative SFV03208-4.8 rates Ca 3962 kgf dynamic / C0a 11547 kgf static, with axial stiffness 18–74 kgf/μm over the Ø12–Ø32 range.
The Y-Hand M1 builds on Prof. Lei Ren's pioneering bionic tension-compression body robot theory: it replaces rigid hinges with joints capable of 3D 6-DOF motion, uses magnetic-collection electric-driven artificial muscles replicating human skeletal-muscle biomechanics, and a multi-layer rigid-flexible coupled design. With 38 whole-hand DOF it delivers 330 N grip (28.7 kg whole-hand grasp) and 180 N per-finger output; 0.2 s whole-hand close time; 0.04 mm fingertip positioning accuracy; and 59 mm/N finger compliance for safe, compliant physical interaction combining strength, speed, precision, dexterity and compliance.
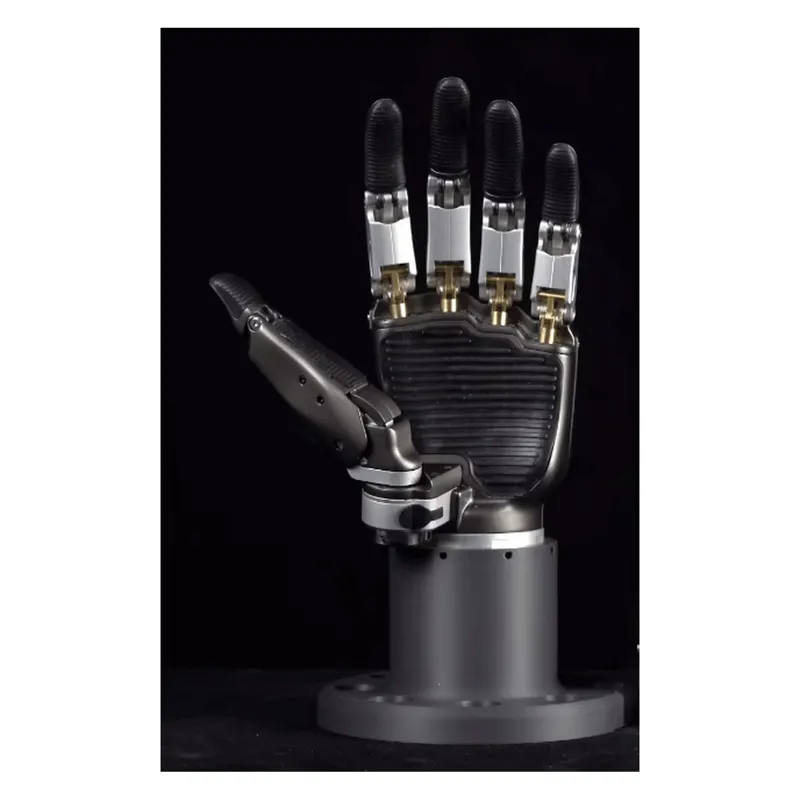
The X-Hand M1 is Yuequan Bionic's rigid bionic dexterous hand: 11 joints with human-like hand size and segment proportions, a bionic palmar arch and ring-shaped oblique-axis design driven by a high power-density motor matrix. Strong and fast: 100 N five-finger grip and 30 N fingertip force, 40 kg whole-hand lift capacity at only 630 g; 0.4 s five-finger close time with ±0.1 mm fingertip repeatability. Sensitive perception via 472 tactile sensing units. Ethernet interface with CAN/RS485 customization; pairs with the X-Bot and W-Bot humanoids.
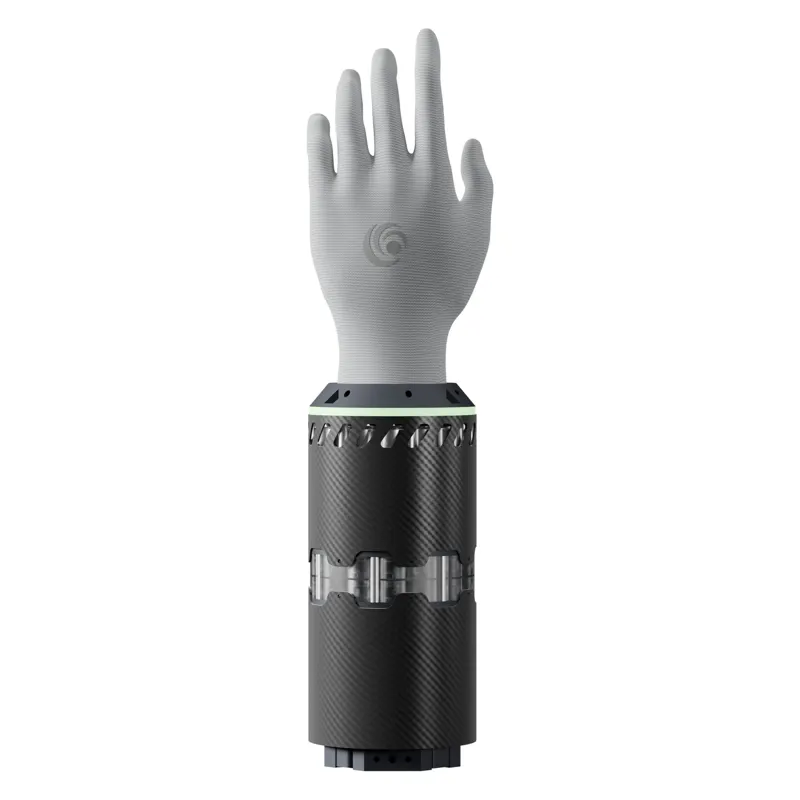
OmniHead is Lanxin Robotics' (Weimai'er) head module built for embodied intelligence: three groups of ten RGB-D array cameras placed at the front, left-rear and right-rear deliver a 360° x 90° panoramic field of view with 0.1-18 m depth ranging (10% reflectivity, indoor), 3 cm (1-sigma) accuracy and 20 Hz frame rate; the head pans +/-75 degrees and tilts +/-45 degrees. It deeply integrates DeepSeek / Qwen LLMs with a six-mic ring array for 5 m far-field pickup, 360-degree sound-source localization, voiceprint recognition and bilingual multi-turn dialogue, plus face recognition. A ROS2 SDK and open ecosystem interfaces adapt it to various humanoid platforms for commercial office, smart manufacturing, smart home and medical-care scenarios. The unit measures 210 x 480 x 220 mm and weighs 1200 g.
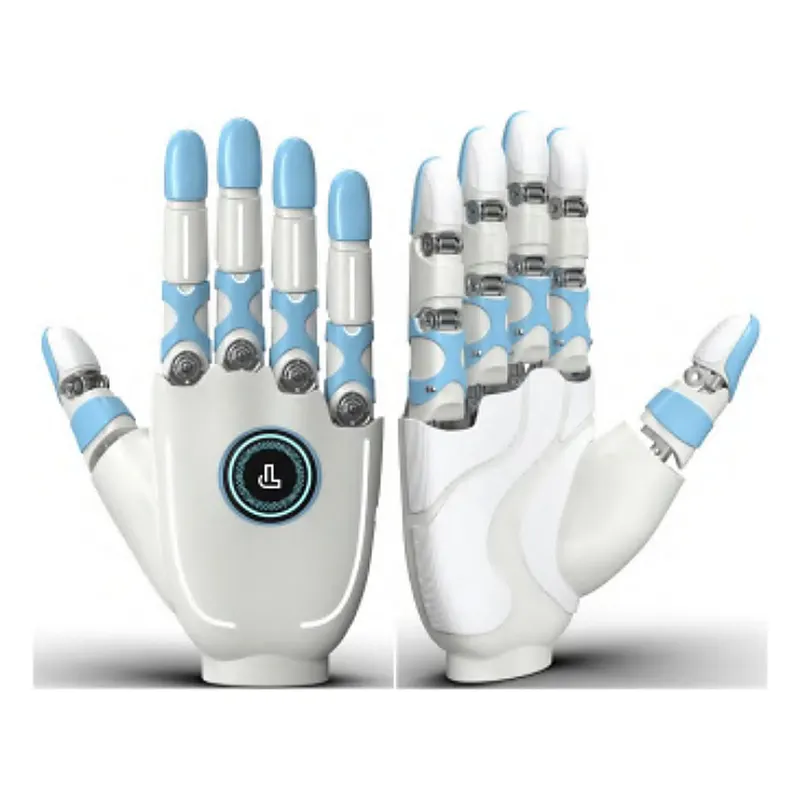
The Lumi-Dex-23 is the industrial-flagship dexterous hand from Zhejiang Shiyue Technology (Lumibot): 23 active DoF with a hybrid direct-drive + linkage actuation and integrated driver-controller, weighing only 850 g at 225 mm total length (98 mm four-finger palm width). The thumb yaws 90° to touch the little-fingertip; fingers bend MCP/PIP/DIP 90°/90°/70° with ±15° splay, thumb yaw speed up to 360°/s and bend 270°/s, four-finger bend 0.3 s/cycle. It delivers 20 N fingertip press, 40 N pinch and 80 N grip active force with a 25 kg passive load, stably grasping 10-50 mm cylindrical/spherical objects. Optional Lumi-Tac visuotactile fingertips (10 μm spatial resolution, 0.02 N force precision), DC12V power, RS485/CAN communication and replaceable four fingers target research, biopharma, 3C electronics, rail transit and automotive manipulation.
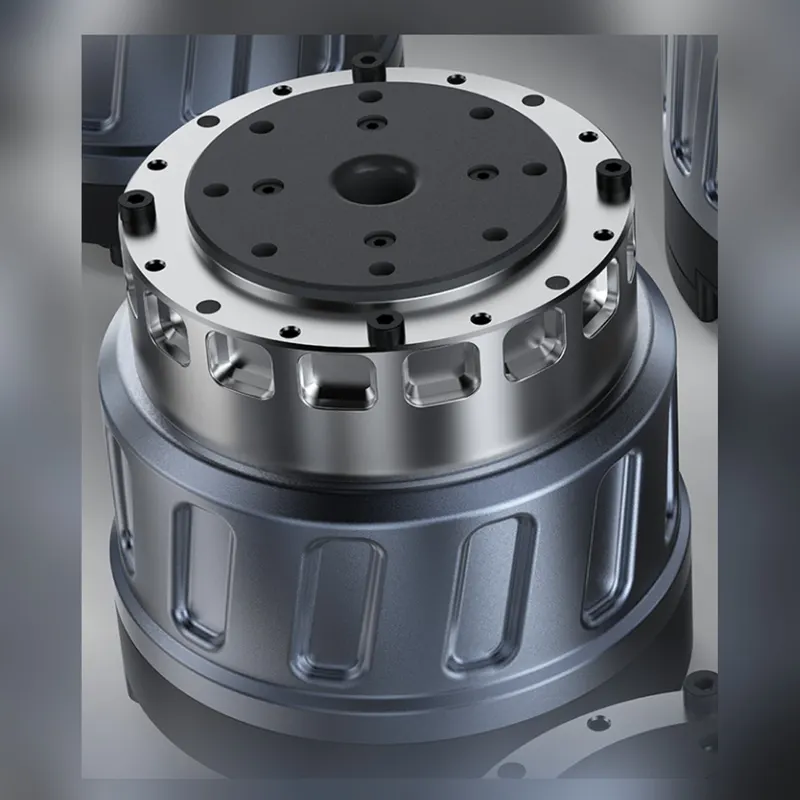
PHYBOT's new-generation PhyArc quasi-direct-drive integrated cycloidal joint modules come in six sizes (47/68/78/95/102/150) with in-house torque motors, cycloidal reduction and dual encoders in a hollow-shaft design; peak torque 12-590 N.m, peak torque density up to 244 N.m/kg, repeatability better than 1 arc-minute, and inertia+damping compensation surviving over 5x instantaneous overload impacts; shipped with SDK, interface board and dev kits for humanoid and other robotics scenarios.