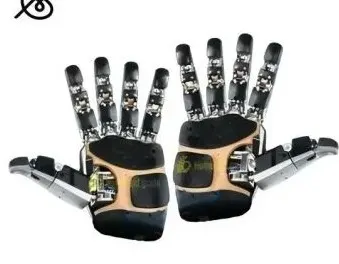
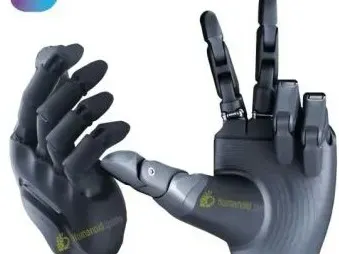
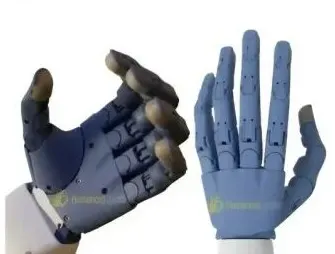
Sanctuary AI robotic hand for general manipulation tasks.
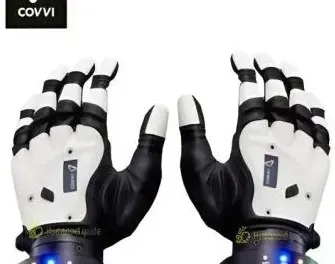
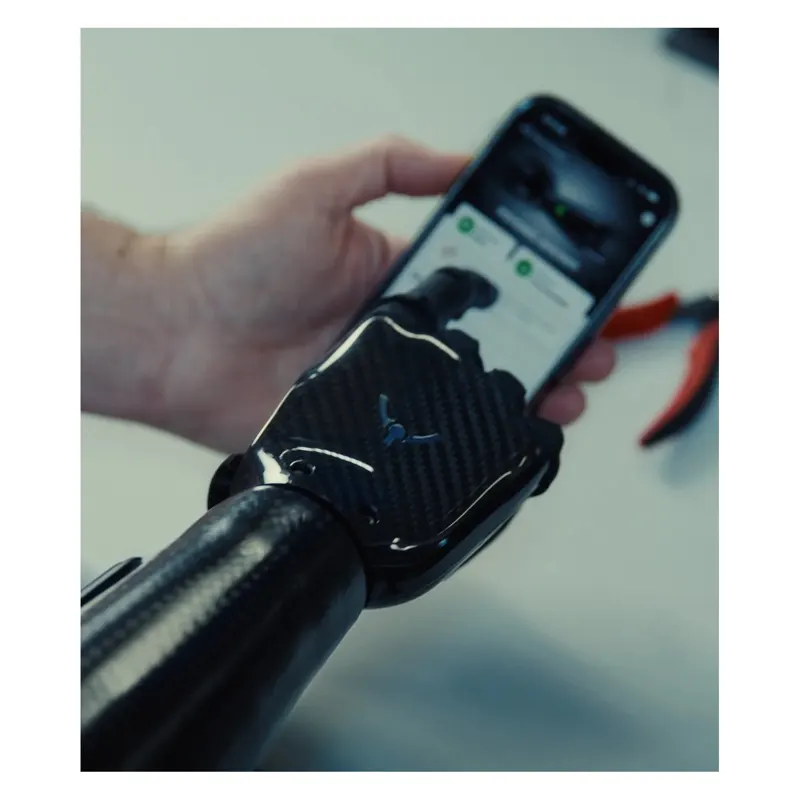
Covvi bionic robotic hand combining aesthetics and functionality.
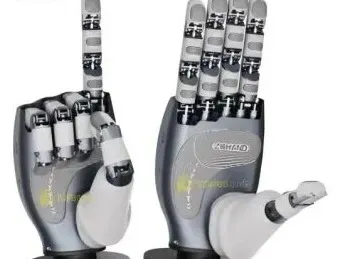
Cost-effective research-grade four-finger hand from Wonik Robotics with 16 independently torque-controlled joints (4 DoF per finger) and 1.08 kg total weight (0.17 kg fingers, 0.19 kg thumb) at 5 kg payload. DC-motor drive with 1:369 gear ratio, 0.70 N·m max joint torque and 0.11 s/60° max speed; potentiometer joint resolution of 0.002°, CAN communication at 333 Hz and 24 VDC/100 W power, widely used for grasp and manipulation research.
High-integration five-finger dexterous hand from Agibot with 12 active / 19 total DoF at ≤750 g; motor + screw-rod drive delivering 20 N max fingertip force and 0.02 mm finger reposition accuracy; fingertip 3-axis plus palm 1-axis force sensing with 150+ tactile points at 0.01 N resolution, and up to 35 kg palm-up load on a 5 cm rigid object.
Kyber Labs open-source low-cost hand for the developer community.
The Psyonic Ability Hand (MK9.5) is a 6-DoF bionic dexterous hand for prosthetics and robotics research: 1 DoF per finger plus 2 DoF in the thumb, driven by 6 brushless DC motors at just 440–470 g total weight (Large 186×85 mm / Small 180×85 mm). Strong grasping: 78 N power grip, 8 N pinch, 17 N key grip, 0.2 s finger close time, peak angular speed 462°/s for fingers and 1848°/s for the thumb, with axial load capacity up to 45.4 kg (thumb 27.2 kg). Rich tactile sensing: 30 force-sensing resistors (6 per digit) plus 6 encoders streamed in real time, 1 kHz closed-loop control in position/current/velocity/duty modes, and 32 grip patterns (19 pre-defined). Powered at 6–12 V (14 A peak, 74 mA quiescent) with an onboard 2200 mAh battery and ~1-hour 30 W / 12 V / 2.5 A fast charging; IP64 rated, touchscreen-compatible fingertips, and an electric + manually rotatable thumb. Open software ecosystem: Python/C++ APIs, ROS 2, NVIDIA Isaac Sim/Isaac Lab support and URDF models, with BLE/I2C/UART/RS485 interfaces.
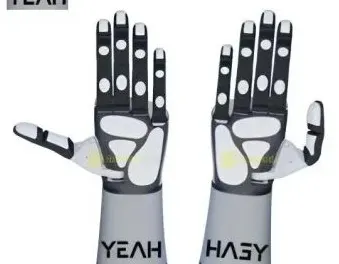
YEAH five-finger hand for research and education.
PI-Universe dexterous hand emphasizing force control and fine manipulation.
Shenzhen ZWHand multi-DOF hand for robot end-effector applications.
NYU open-source/research dexterous hand for academic institutions.
Tesollo five-finger hand emphasizing cost-effectiveness and precise grasping.
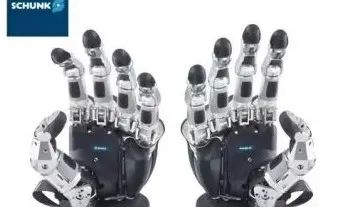
SCHUNK five-finger hand; industrial-grade reliability, widely used in research and automation.