Delta Intelligence unveils Delta-0, a humanoid foundation model trained on 10,000+ hours of human data — making beds, opening dishwashers, emptying trash with a brain-cerebellum force-position hybrid architecture
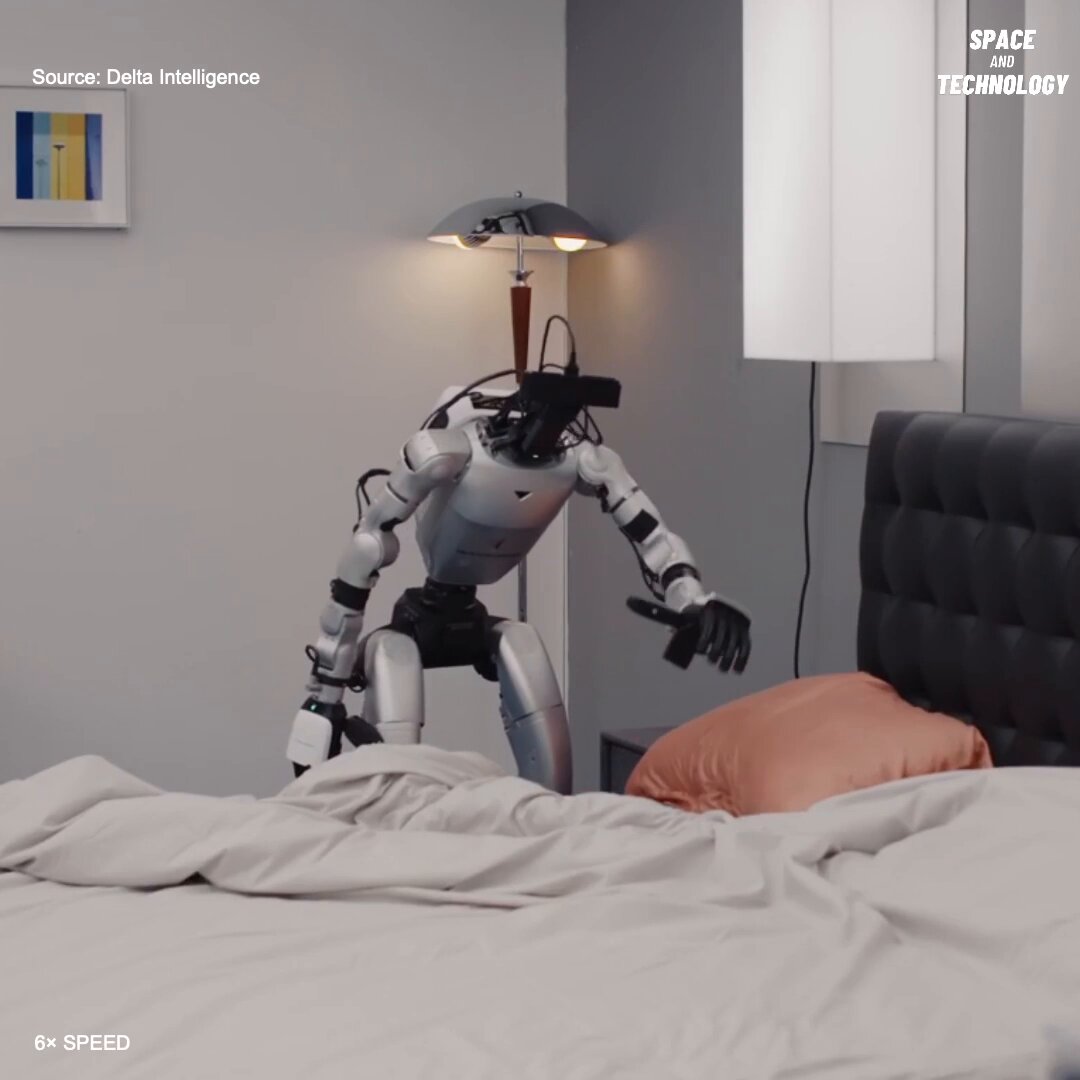
Delta Intelligence (Beijing, incubated by BIGAI, UCLA-PhD team led by Ma Xiaojian) released Delta-0, a humanoid foundation model that coordinates walking, balance, and manipulation — handling everyday tasks like making a bed, opening a dishwasher, picking up objects, and operating a trash can. Trained on 10,000+ hours of human data; the system combines a learned whole-body controller, simulation, human corrections, and real-world reinforcement learning. The company's unusual play is "robots without robots": alongside the model (brain = perception/task planning from real interaction data; cerebellum = simulation-RL whole-body balance; force-position hybrid layer = compliant contact), it sells the Delta D1 headset that captures first-person vision plus whole-body joint trajectories from human workers (within 2cm positioning), retargetable across Unitree, AgiBot, and Leju bodies — and rival OEMs AgiBot, Leju, and Galaxea have all invested. Six funding rounds in six months, a near-RMB 500M angel++ round, a proprietary 3D world engine processing point clouds and Gaussian splatting instead of guessing depth from 2D, and deployments in electric-grid inspection, auto-parts machine loading, and SMT bin sorting