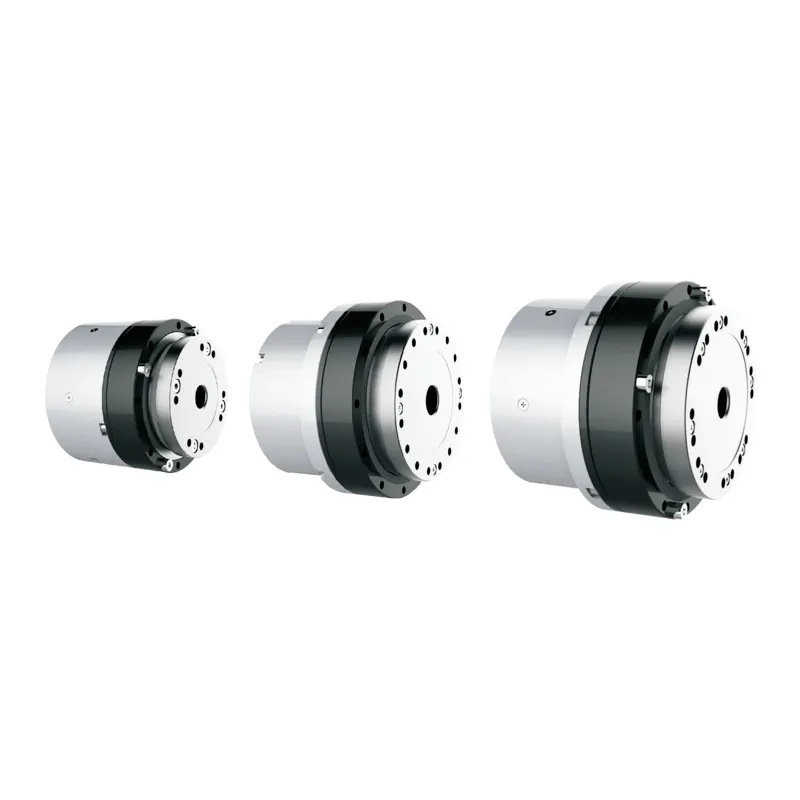
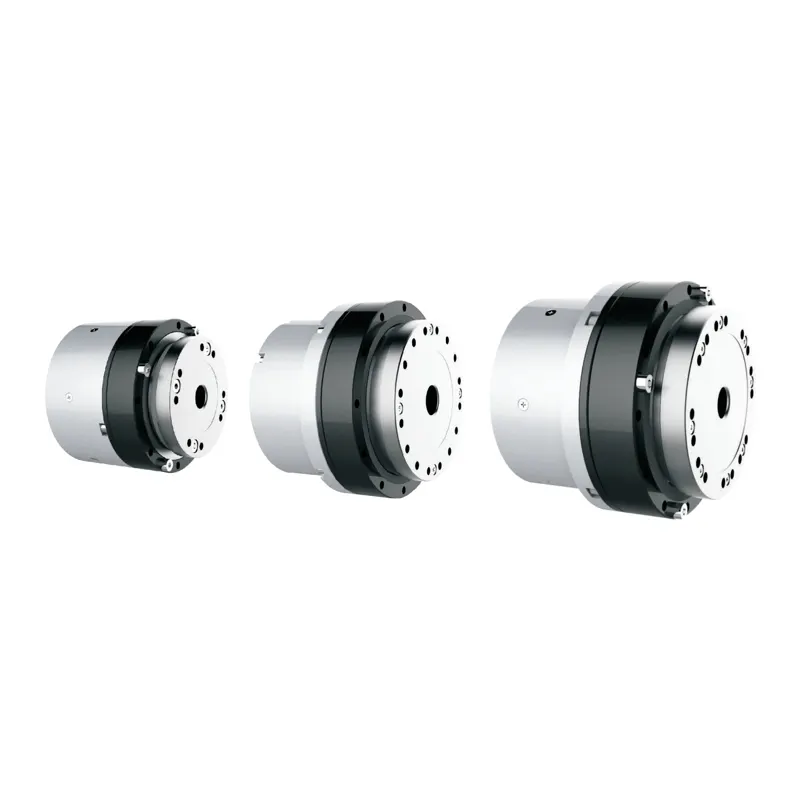
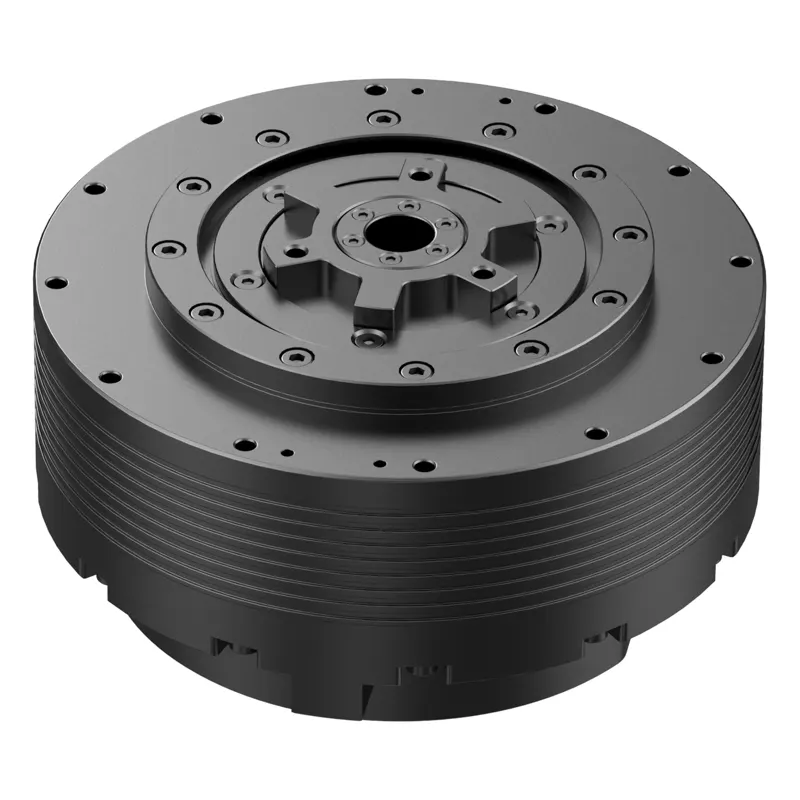
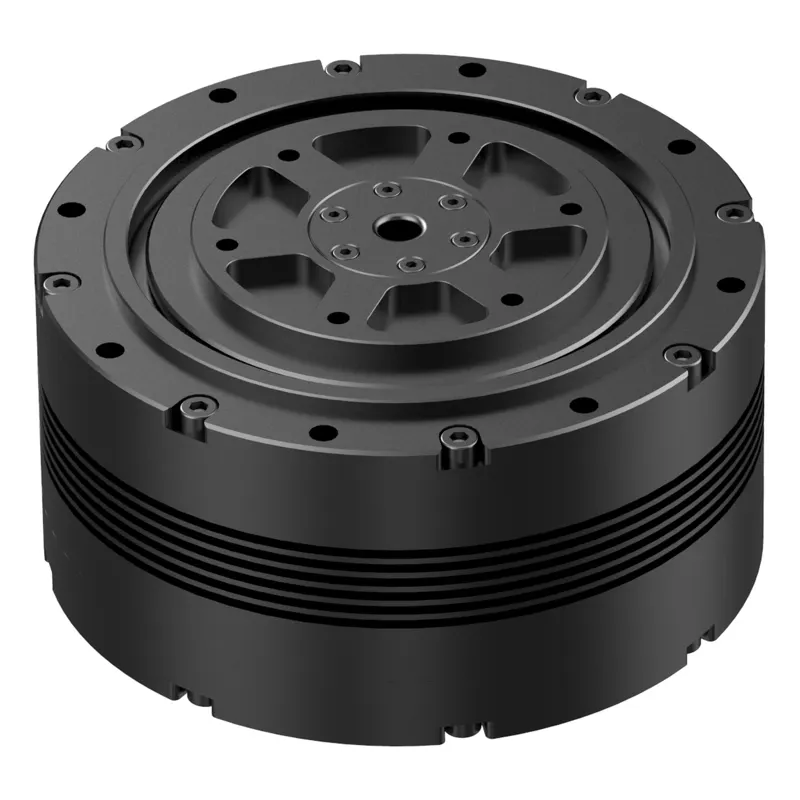
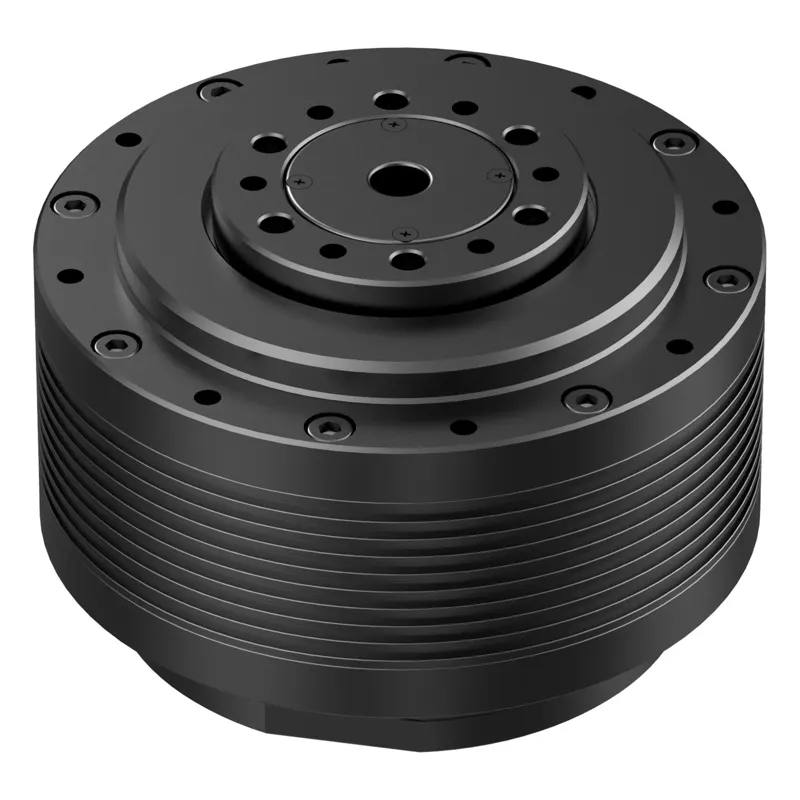
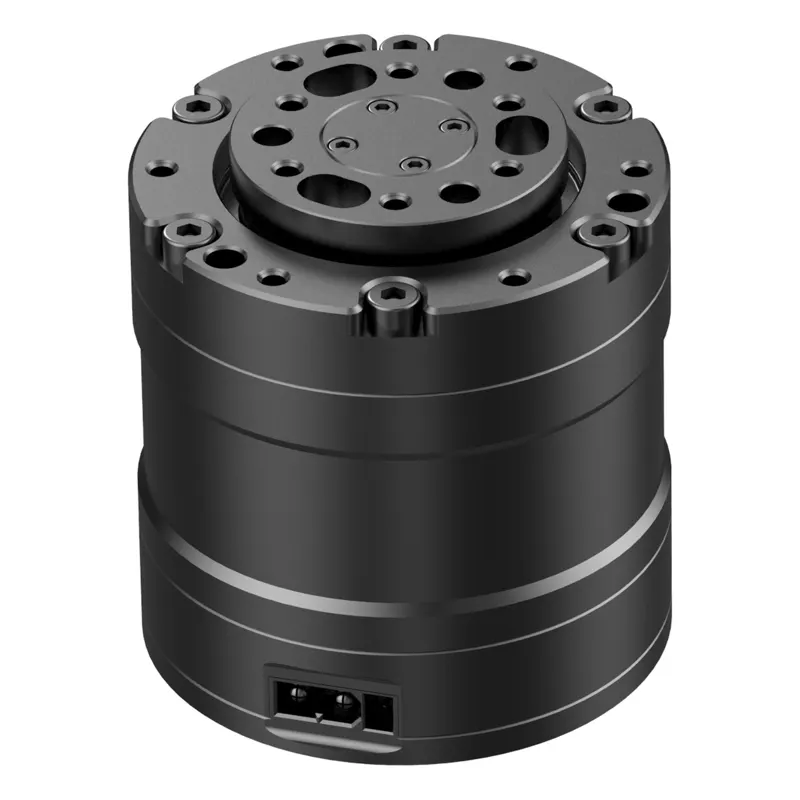
Jiangsu Kaiserdrive (subsidiary of Leaderdrive Harmonic Drive, STAR-688017) KGU robot joint module, model KGU-17C: 40 N·m rated / 78 N·m max torque, 30/50 rpm rated/max speed, 130 W rated power, 48VDC, ratio 1/101. Integrated harmonic reducer + frameless torque motor + built-in EtherCAT/CANopen servo driver + dual 20-bit single-turn absolute encoders (BiSS-C), 50 arcsec positioning / 10 arcsec repeatability, Φ10mm hollow shaft, Φ80×81mm envelope, only 1.12kg, optional power-off holding brake. For lightweight humanoid-arm joints (payload/weight ratio near 1:1); smallest joint under 350g.
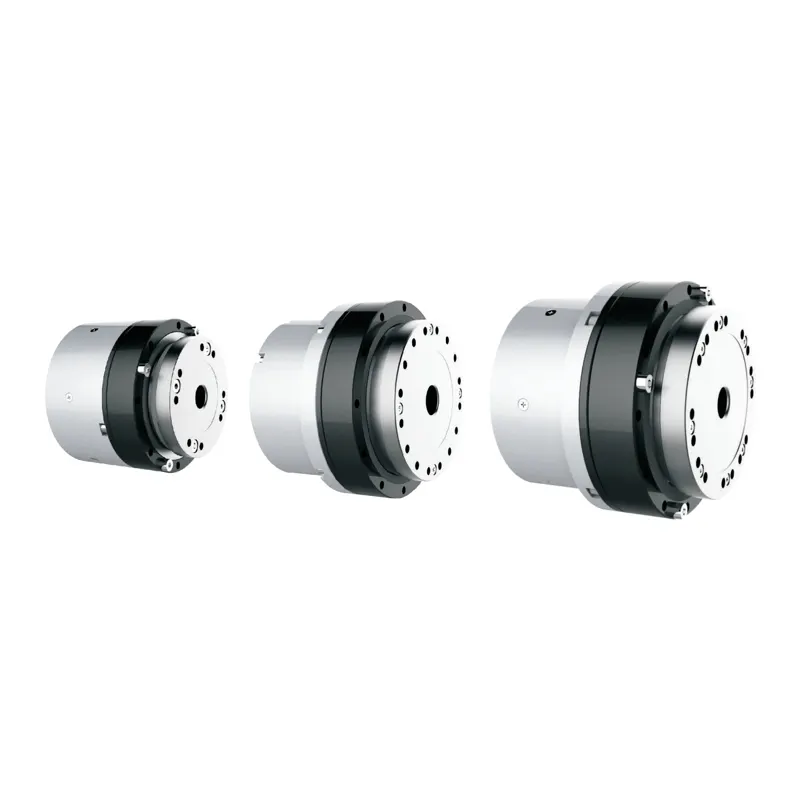
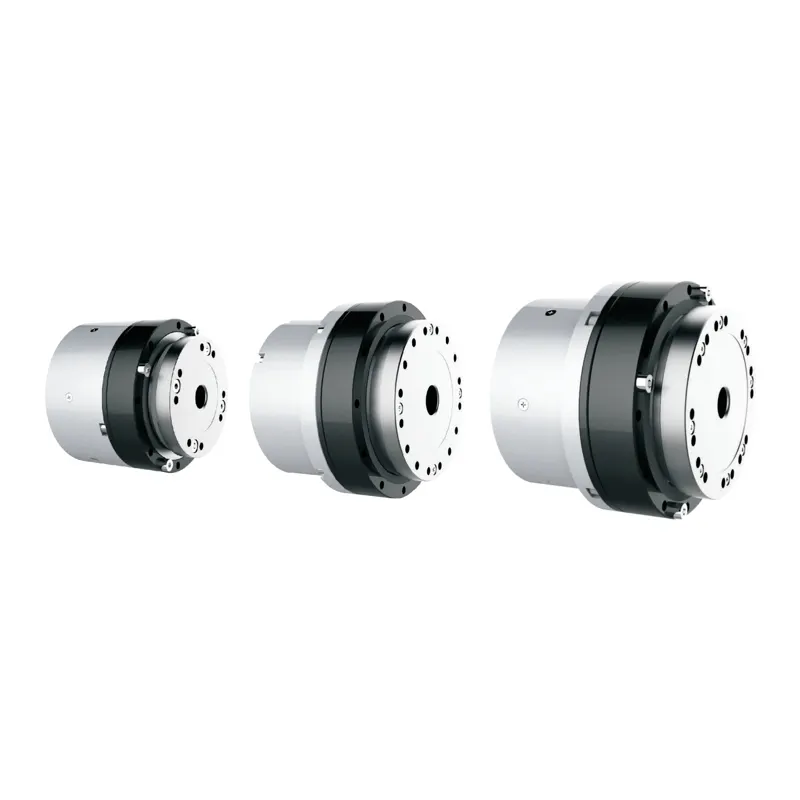
Jiangsu Kaiserdrive (subsidiary of Leaderdrive Harmonic Drive, STAR-688017) KGU robot joint module, model KGU-17B: 33 N·m rated / 61 N·m max torque, 38/62 rpm rated/max speed, 130 W rated power, 48VDC, ratio 1/81. Integrated harmonic reducer + frameless torque motor + built-in EtherCAT/CANopen servo driver + dual 20-bit single-turn absolute encoders (BiSS-C), 50 arcsec positioning / 10 arcsec repeatability, Φ10mm hollow shaft, Φ80×81mm envelope, only 1.12kg, optional power-off holding brake. For lightweight humanoid-arm joints (payload/weight ratio near 1:1); smallest joint under 350g.
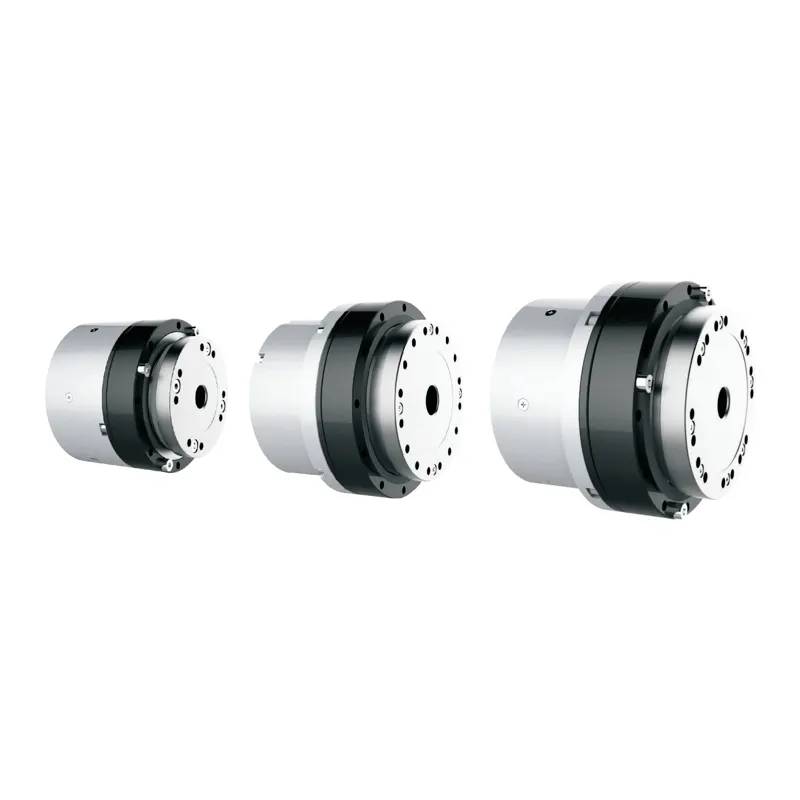
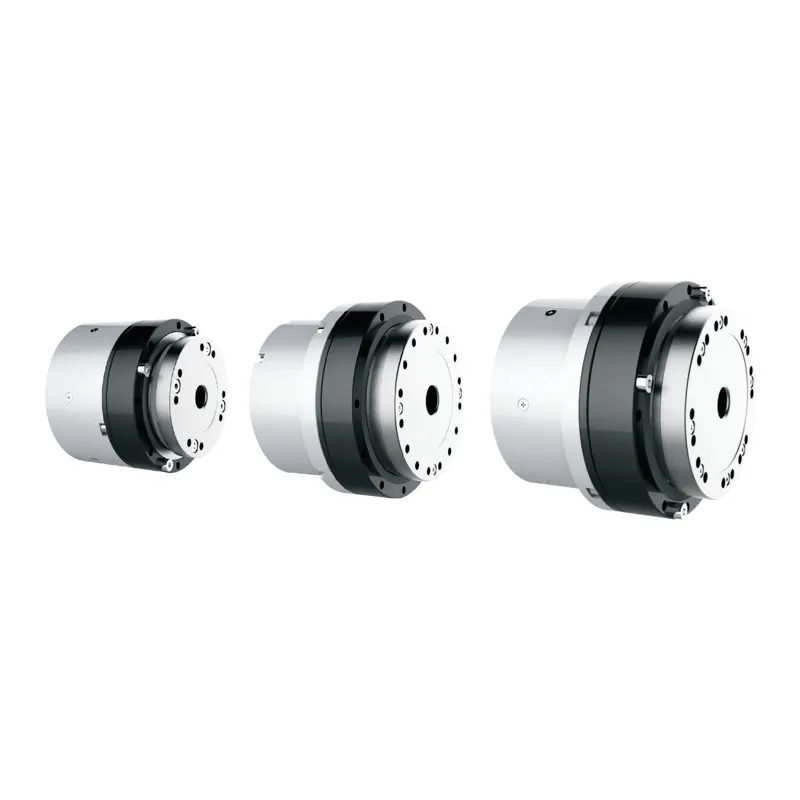
Jiangsu Kaiserdrive (subsidiary of Leaderdrive Harmonic Drive, STAR-688017) KGU robot joint module, model KGU-14C: 25 N·m rated / 50 N·m max torque, 32/50 rpm rated/max speed, 90 W rated power, 48VDC, ratio 1/101. Integrated harmonic reducer + frameless torque motor + built-in EtherCAT/CANopen servo driver + dual 20-bit single-turn absolute encoders (BiSS-C), 60 arcsec positioning / 10 arcsec repeatability, Φ10mm hollow shaft, Φ70×72mm envelope, only 0.83kg, optional power-off holding brake. For lightweight humanoid-arm joints (payload/weight ratio near 1:1); smallest joint under 350g.
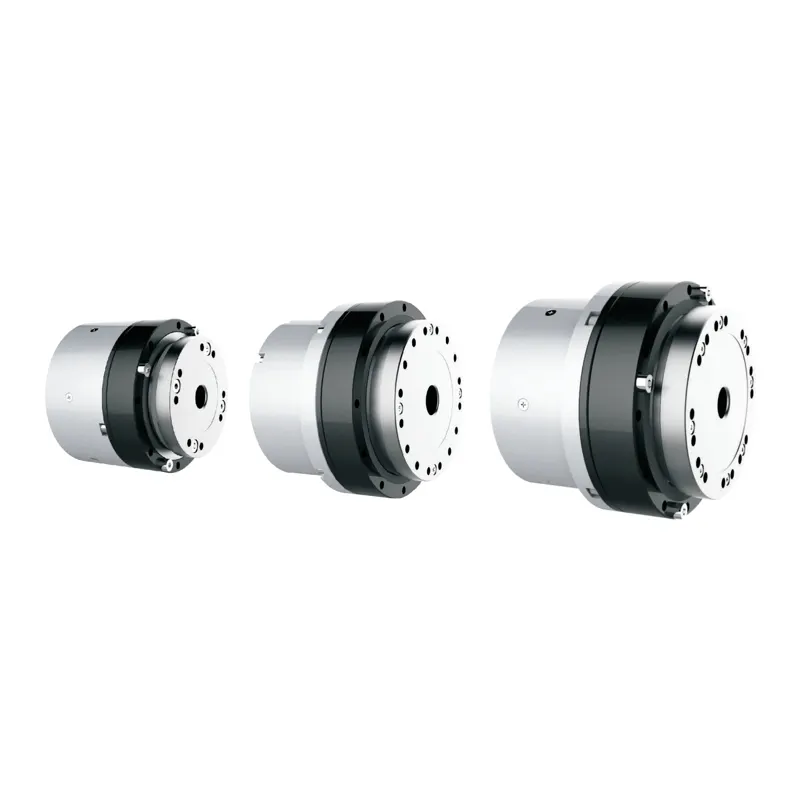
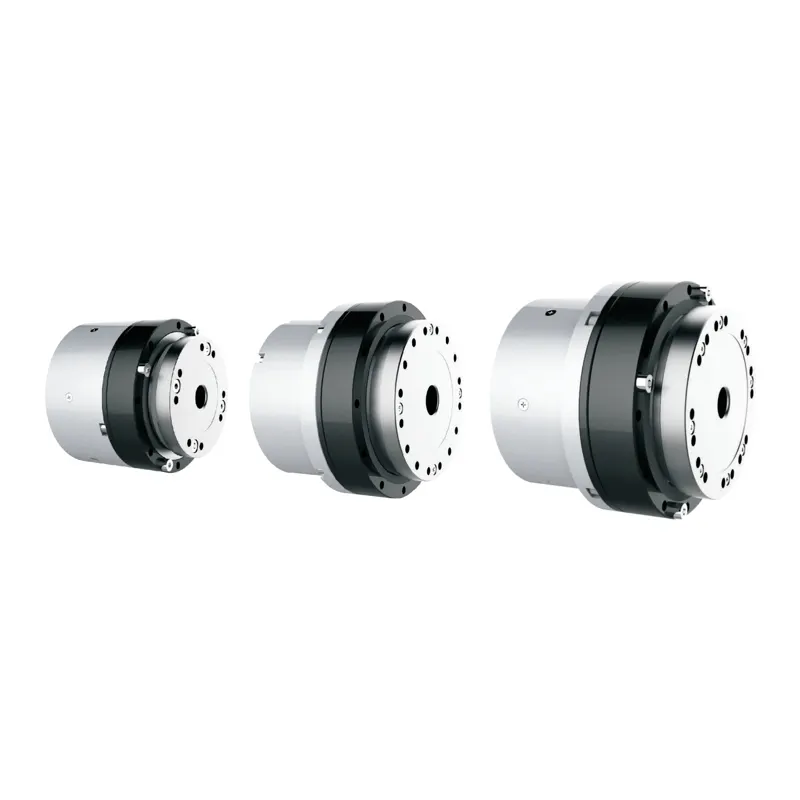
Jiangsu Kaiserdrive (subsidiary of Leaderdrive Harmonic Drive, STAR-688017) KGU robot joint module, model KGU-14B: 20 N·m rated / 40 N·m max torque, 40/62 rpm rated/max speed, 90 W rated power, 48VDC, ratio 1/81. Integrated harmonic reducer + frameless torque motor + built-in EtherCAT/CANopen servo driver + dual 20-bit single-turn absolute encoders (BiSS-C), 60 arcsec positioning / 10 arcsec repeatability, Φ10mm hollow shaft, Φ70×72mm envelope, only 0.83kg, optional power-off holding brake. For lightweight humanoid-arm joints (payload/weight ratio near 1:1); smallest joint under 350g.
Jiangsu Kaiserdrive (subsidiary of Leaderdrive Harmonic Drive, STAR-688017) KGU robot joint module, model KGU-11C: 16 N·m rated / 30 N·m max torque, 32/50 rpm rated/max speed, 60 W rated power, 48VDC, ratio 1/101. Integrated harmonic reducer + frameless torque motor + built-in EtherCAT/CANopen servo driver + dual 20-bit single-turn absolute encoders (BiSS-C), 69 arcsec positioning / 15 arcsec repeatability, Φ6.5mm hollow shaft, Φ62×68mm envelope, only 0.62kg, optional power-off holding brake. For lightweight humanoid-arm joints (payload/weight ratio near 1:1); smallest joint under 350g.
Jiangsu Kaiserdrive (subsidiary of Leaderdrive Harmonic Drive, STAR-688017) KGU robot joint module, model KGU-11B: 12 N·m rated / 23 N·m max torque, 40/62 rpm rated/max speed, 60 W rated power, 48VDC, ratio 1/81. Integrated harmonic reducer + frameless torque motor + built-in EtherCAT/CANopen servo driver + dual 20-bit single-turn absolute encoders (BiSS-C), 69 arcsec positioning / 15 arcsec repeatability, Φ6.5mm hollow shaft, Φ62×68mm envelope, only 0.62kg, optional power-off holding brake. For lightweight humanoid-arm joints (payload/weight ratio near 1:1); smallest joint under 350g.
Jiangsu Kaiserdrive (subsidiary of Leaderdrive Harmonic Drive, STAR-688017) KGU robot joint module, model KGU-08C: 7 N·m rated / 16 N·m max torque, 35/55 rpm rated/max speed, 30 W rated power, 48VDC, ratio 1/101. Integrated harmonic reducer + frameless torque motor + built-in EtherCAT/CANopen servo driver + dual 20-bit single-turn absolute encoders (BiSS-C), 69 arcsec positioning / 15 arcsec repeatability, Φ6.5mm hollow shaft, Φ52×56mm envelope, only 0.35kg, optional power-off holding brake. For lightweight humanoid-arm joints (payload/weight ratio near 1:1); smallest joint under 350g.
Jiangsu Kaiserdrive (subsidiary of Leaderdrive Harmonic Drive, STAR-688017) KGU robot joint module, model KGU-08B: 6 N·m rated / 12 N·m max torque, 43/68 rpm rated/max speed, 30 W rated power, 48VDC, ratio 1/81. Integrated harmonic reducer + frameless torque motor + built-in EtherCAT/CANopen servo driver + dual 20-bit single-turn absolute encoders (BiSS-C), 69 arcsec positioning / 15 arcsec repeatability, Φ6.5mm hollow shaft, Φ52×56mm envelope, only 0.35kg, optional power-off holding brake. For lightweight humanoid-arm joints (payload/weight ratio near 1:1); smallest joint under 350g.
HCFA Hu-GRS series planetary rotary joint actuator, flagship GRS150N: 40 N·m rated / 150 N·m peak torque, 125/138 rpm rated/peak speed, 880 W power, 48VDC. Integrated frameless torque motor + hollow flat planetary reducer + driver + dual absolute 17-bit encoders, 12.25:1 ratio, 15 arcmin backlash, Φ11.5mm hollow shaft, Φ124×66mm envelope, 1.66kg, CAN-FD. For high-torque hip and knee joints of humanoid robots.
HCFA Hu-GRS series planetary rotary joint actuator GRS090N: 25 N·m rated / 90 N·m peak torque, 144/160 rpm rated/peak speed, 565 W power, 48VDC. Integrated frameless torque motor + hollow flat planetary reducer + driver + dual absolute 17-bit encoders, 13.19:1 ratio, 15 arcmin backlash, Φ6mm hollow shaft, Φ105×53mm envelope, 0.93kg, CAN-FD. For hip, knee and elbow joints of humanoid robots.
HCFA Hu-GRS series planetary rotary joint actuator GRS06N: 20 N·m rated / 60 N·m peak torque, 126/160 rpm rated/peak speed, 366 W power, 48VDC. Integrated frameless torque motor + hollow flat planetary reducer + driver + dual absolute 17-bit encoders, 18.8:1 ratio, 10 arcmin backlash, Φ7mm hollow shaft, Φ88×59.5mm envelope, 0.604kg, CAN-FD. For fast elbow and upper-limb joints of humanoid robots.
HCFA Hu-GRS planetary rotary joint actuator, entry model GRS036N: 9 N·m rated / 37.6 N·m peak torque, 77/100 rpm rated/peak speed, 138 W power, 48VDC. Integrated frameless torque motor + hollow flat planetary reducer + driver + single absolute 17-bit encoder, 36:1 ratio, 12 arcmin backlash, Φ56×59.5mm envelope, 0.385kg, CAN-FD. Suited for upper-limb and wrist joints of humanoid robots.