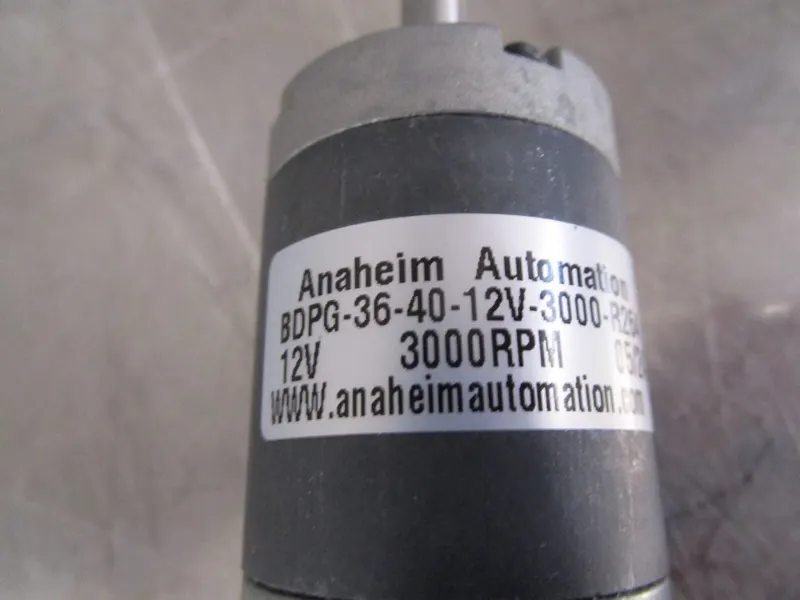
BDPG-36 DC brush planetary gearmotor, 12 V, rated 5 oz-in, peak 69 oz-in, ratio 5.2.
Third-generation YLHS strain wave gear, sizes 17-40, ratios 80-160, rated torque 20-350 N·m, 10000 h design life.
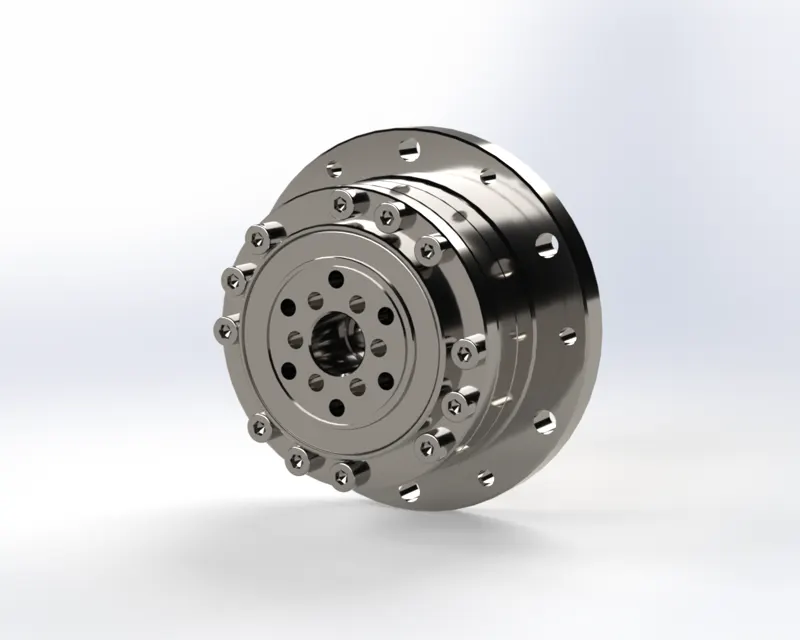
High-torque hat-type strain wave gear series, ratios 30-160, widely used in industrial and collaborative robot joints.
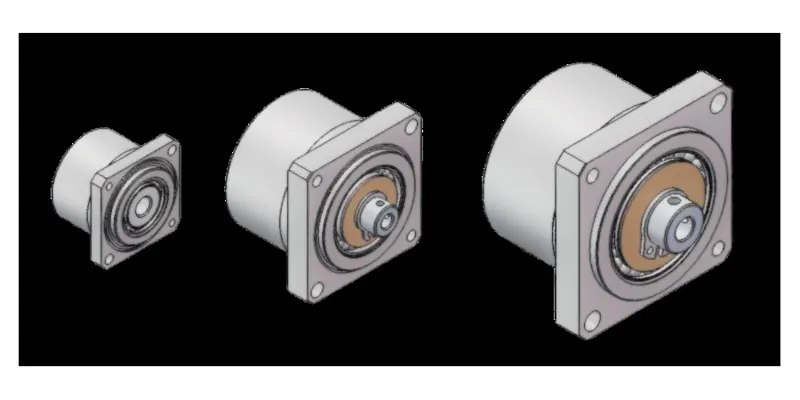
Miniature cup-shaped strain wave gears, sizes 3-11, rated torque 0.11-5 N·m, for dexterous hands and micro joints.
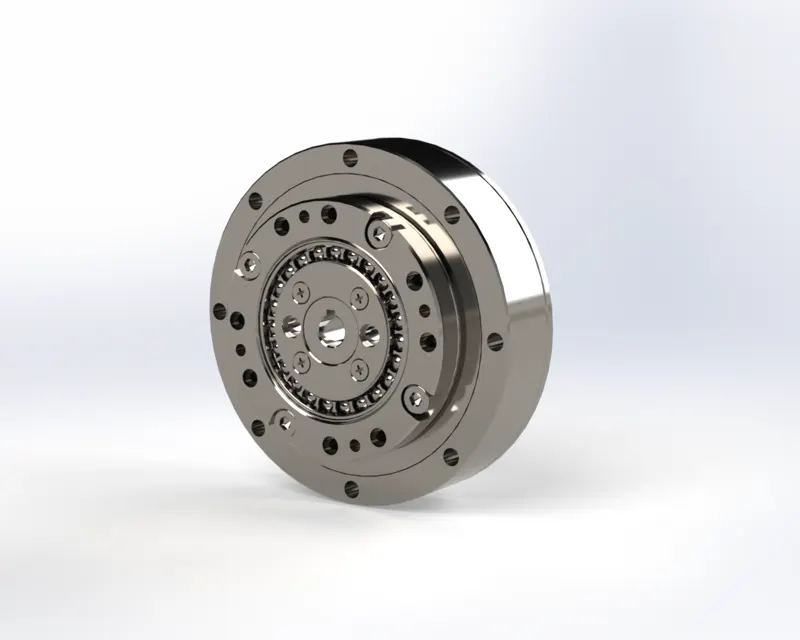
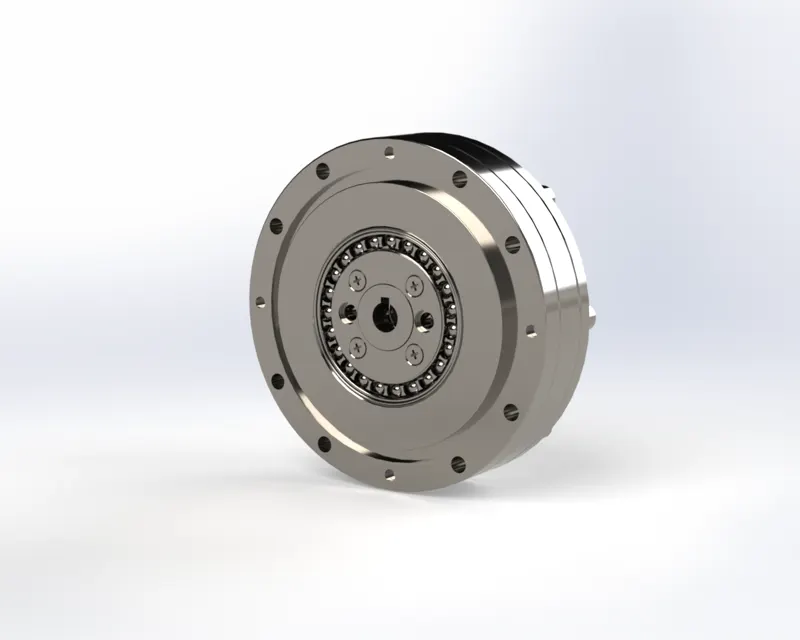
Ultra-flat cup-shaped strain wave gear series with ratios 50-160, rated torque 3.7-16 N·m and backlash within 10 arcsec for space-constrained robot joints.
Frameless direct-drive torque motors, 130-750 W, rated torque 0.459-4.479 N·m, peak 13.44 N·m, 16-pole, 48 VDC / 220 VAC bus.
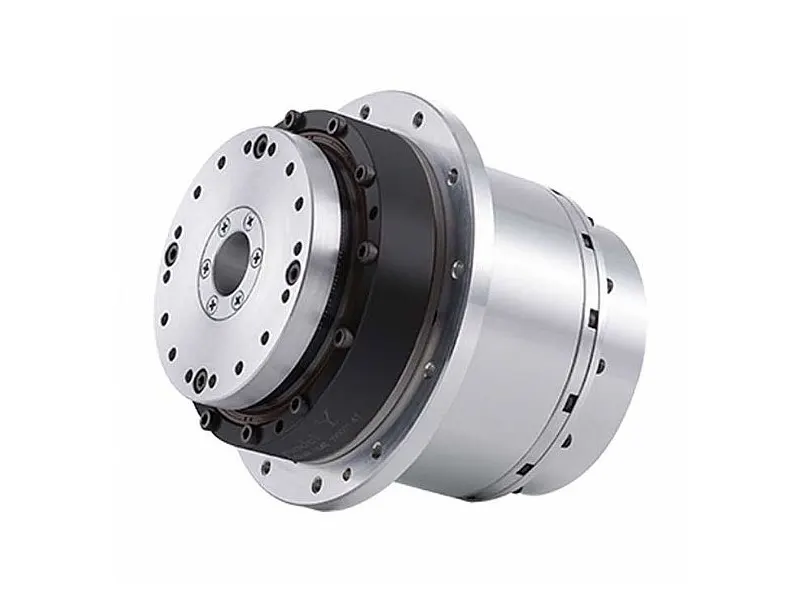
Integrated hollow-shaft rotary actuator with harmonic gear, servo motor and absolute encoder; sizes 14-40, peak torque 23-800 N·m, IP65.
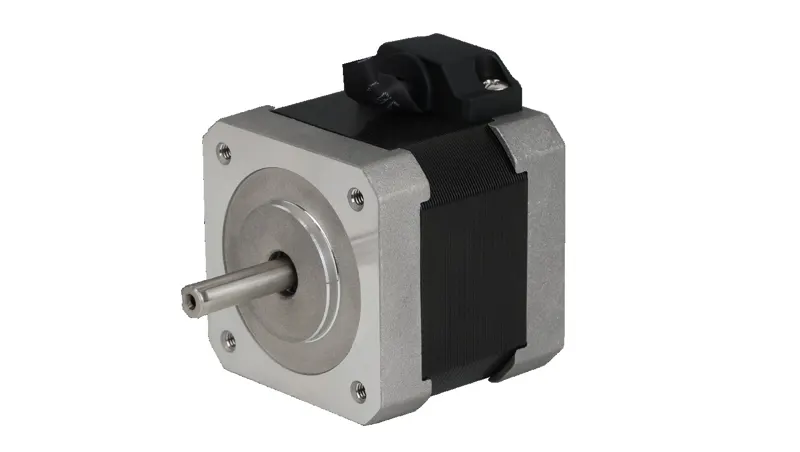
425CM high-end five-phase stepper motors in a 42 mm frame. 425CM03: 0.3 N·m holding torque, 1.8 A, 41 mm body, 0.3 kg; smoother low-vibration five-phase operation, IP40, RoHS; for medical devices, precision stages and light robot joints.
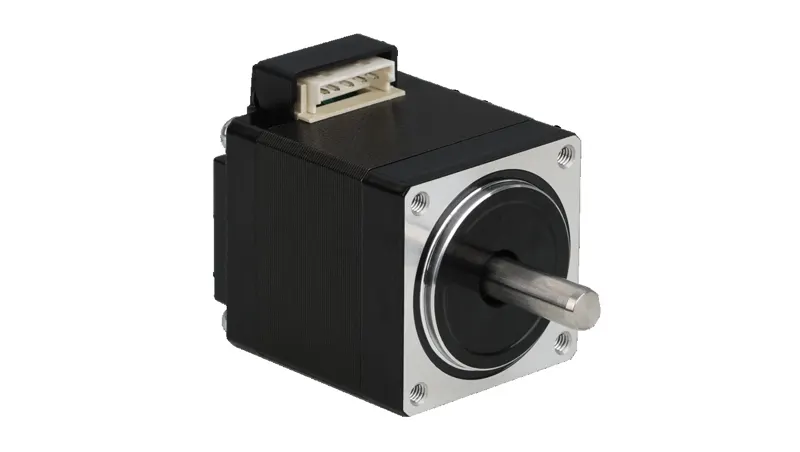
285CM high-end five-phase stepper motors in a miniature 28 mm frame. 285CM005: 0.05 N·m holding torque, 1.2 A, 32 mm body, 0.1 kg; five-phase design for lower vibration and finer resolution, IP40, RoHS.
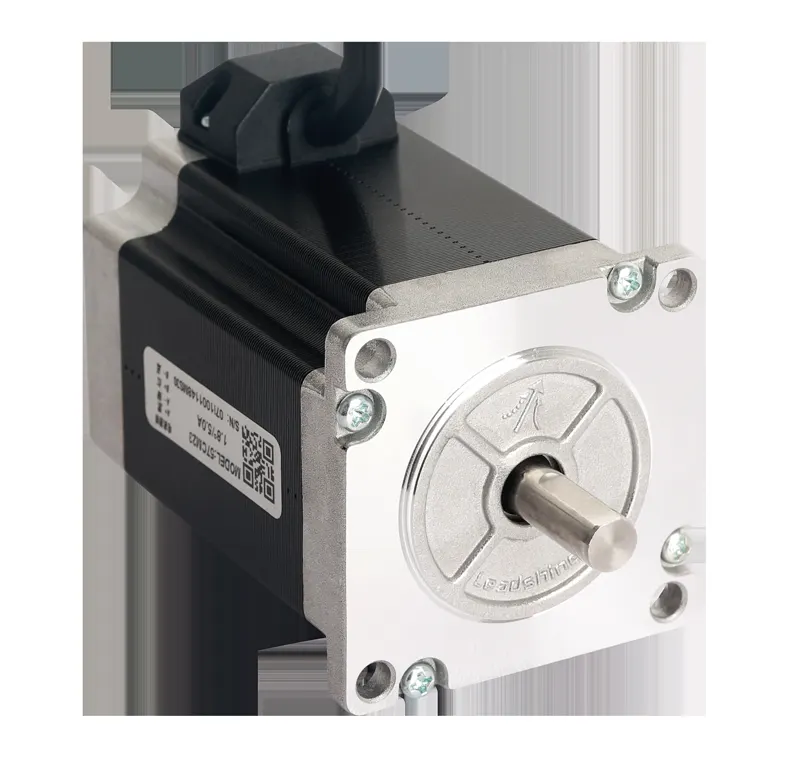
57CM standard two-phase stepper motors (NEMA 23 class). 57CM06: 0.6 N·m holding torque, 3 A rated, 41 mm body, 0.48 kg, IP40, CE/RoHS; for automation equipment and auxiliary robot axes.
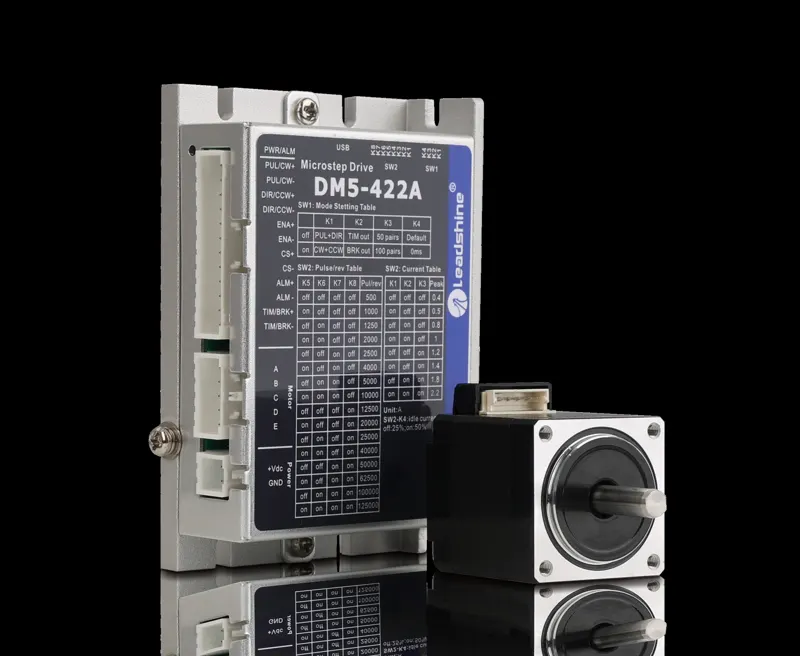
DM5 high-end five-phase stepper drives, 24-36 VDC. DM5-422A: 2.2 A peak, matches frame-28 motors, 1 MHz pulse input, TYPE-C debug with Motion Studio, 4 DI / 2 DO, pulse/direction/enable and microstep configuration.
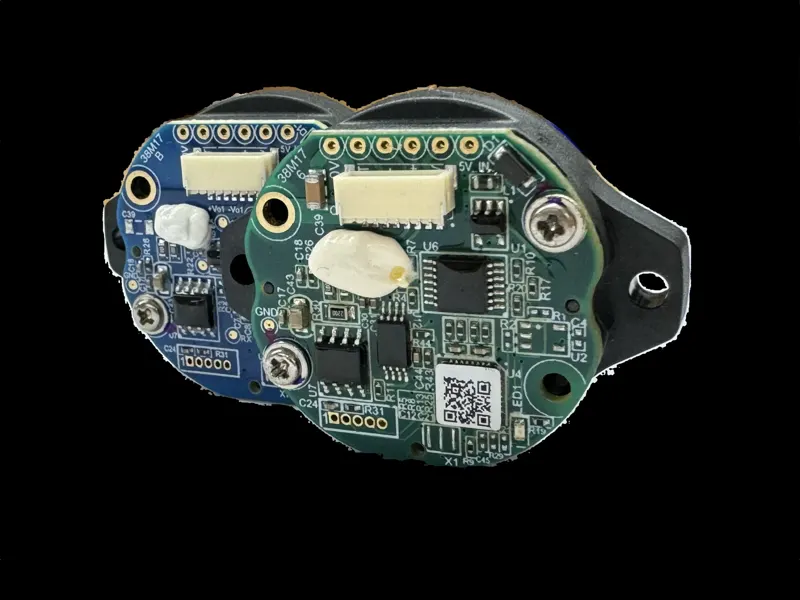
M17M standard 17-bit split magnetic-electric absolute encoders: 17-bit single-turn, 16-bit multi-turn, 5 V, RS485 at 2.5 Mbps. Strong vibration/shock/contamination resistance for reliable servo feedback in automation, robotics and logistics.