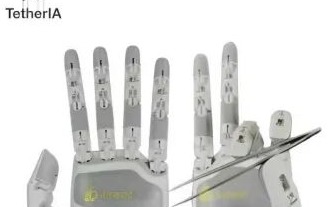
TetherIA five-finger dexterous hand for research and commercial applications.
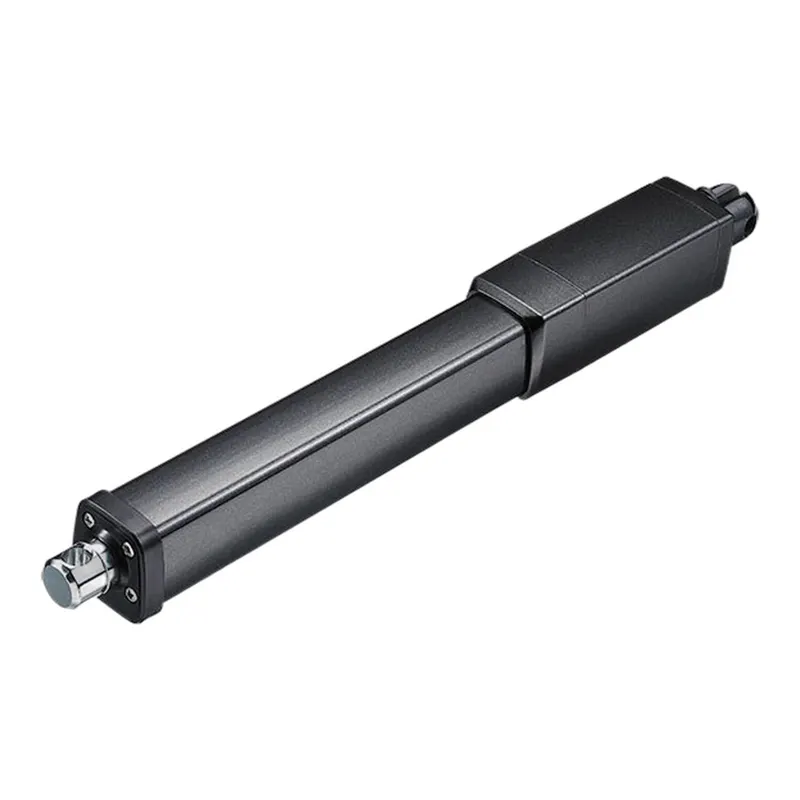
The JP3 is TiMOTION’s inline linear actuator for industrial and agricultural equipment: up to 2,000 N force, 20-1000 mm stroke, 3.5 mm/s at max load and 23.5 mm/s no-load speed, 12/24 V DC (PTC option), IP69K (static) ingress protection, UL73 certified, -5 to +65°C operation, with optional dual NPN Hall sensors for position feedback and synchronization.
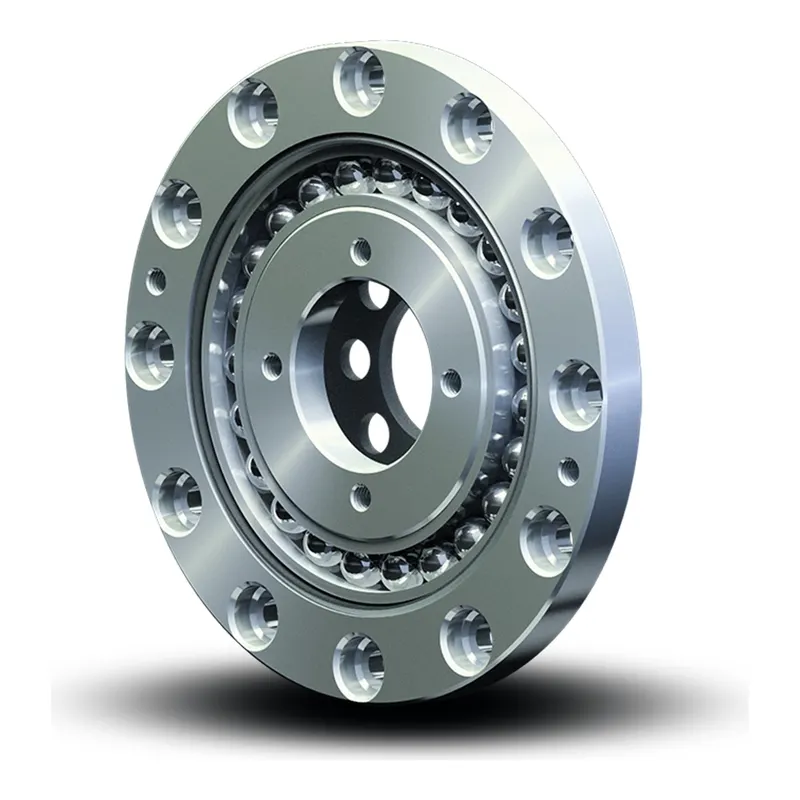
The CSD-2A is Harmonic Drive’s ultra-compact gear component set: shortest design, low weight and a large hollow shaft for cables and shafts, ideal for tight installation spaces. Official data: ratios 50/80/100/120/160 with repeatable peak torques 12-823 Nm, hollow shaft Ø11-50 mm, sizes 14-50; reduced moment of inertia for high dynamics, ideal with integrated output bearing arrangement.
Integrated motor+reducer+encoder smart joint, plug-and-play.
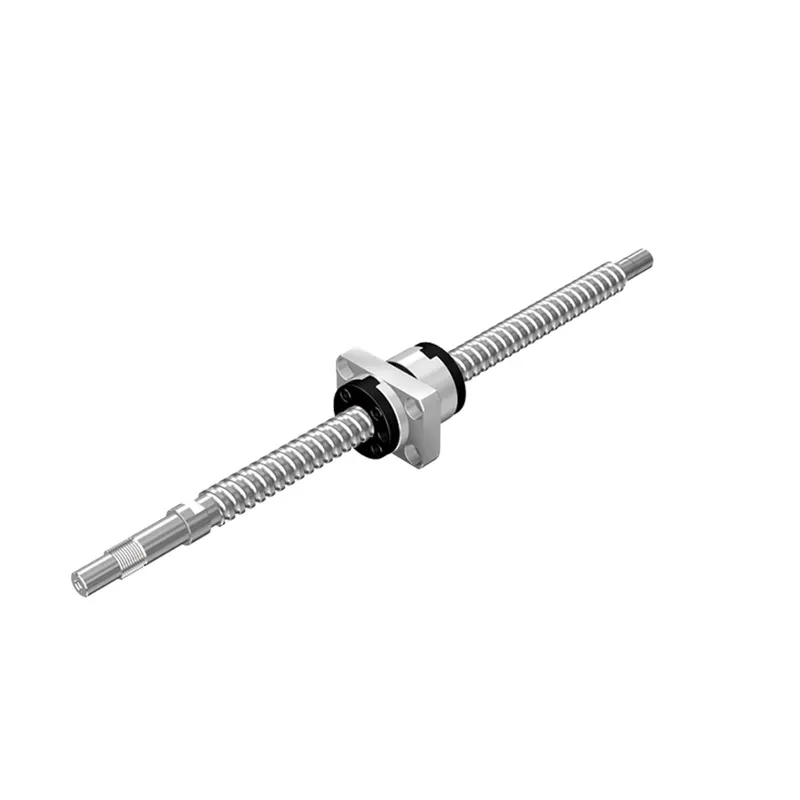
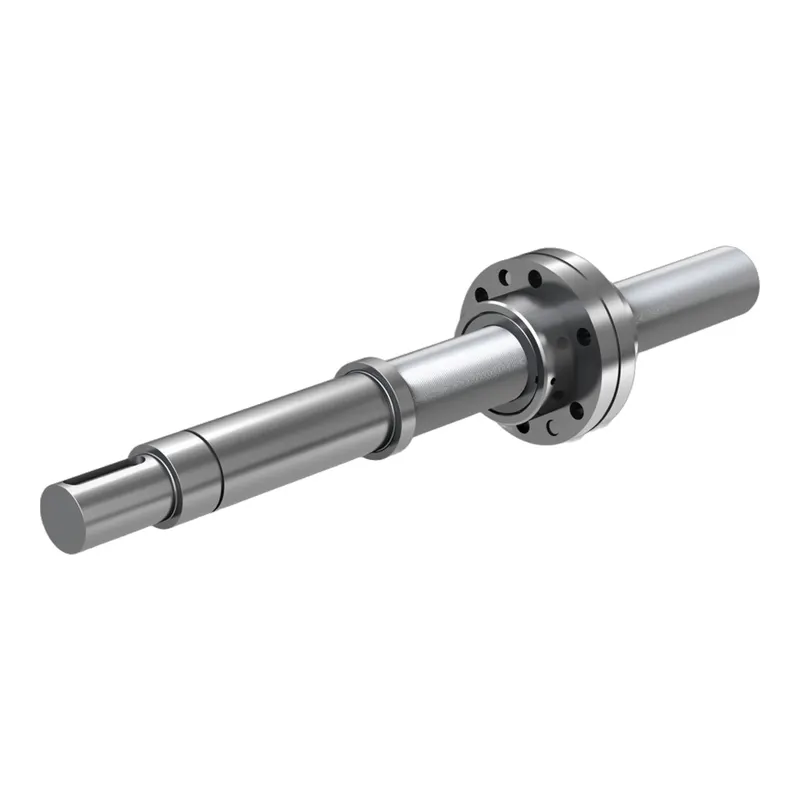
THK ball screws roll balls between shaft and nut for high efficiency: driving torque under one third of sliding screws, zero backlash, high rigidity, micro-feed and high-speed feed. The finished-shaft-end precision BNK04-BNK16 series covers screw shaft diameters 4-16 mm with leads 1-20 mm for precision positioning, alongside caged-ball, full-ball, rolled and rotary ball screw lines.
Ewellix (now Schaeffler Linear Motion) planetary roller screws use a non-recirculating planetary design for ultimate drive performance: official technical data — nominal diameter 8-240 mm, lead 2-50 mm, basic dynamic load capacity up to 3,994 kN, static up to 23,387 kN, n×d0 up to 160,000, acceleration up to 12,000 rad/s², linear speed up to 1.8 m/s; nut types SRC/BRC, SRF/BRF, SRP/BRP, preloaded split PRU/PRK and high-performance HRC/HRF/HRP.
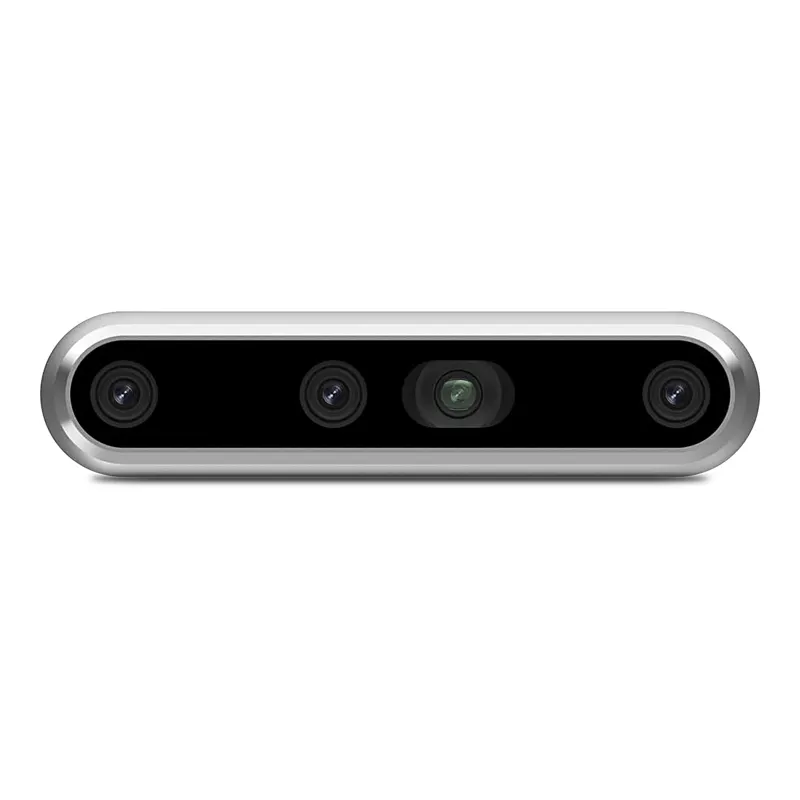
Global-shutter stereo depth camera for outdoor and dynamic scenes: 95 mm long baseline, 0.4-6 m recommended range (20 m max), depth up to 1280x720@90fps, pixel-synchronized global-shutter RGB, built-in 6-axis IMU and USB-C 3.1 Gen 1 in a 124x29x26 mm / 116 g body, widely used on AMRs, drones and outdoor robots.
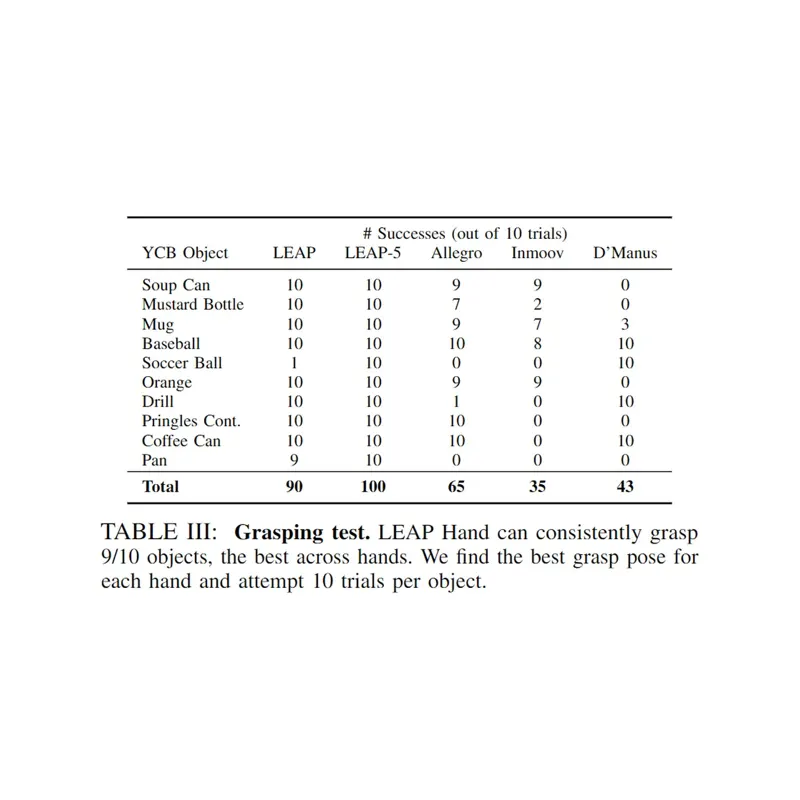
LEAP Hand is an open-source four-finger dexterous hand from Carnegie Mellon University (Kenneth Shaw, Ananye Agrawal, Deepak Pathak; RSS 2023): 16 DoF (4 per finger) at a total cost under $2,000, assemblable in under 3 hours using only common hand tools, and roughly 1/8 the cost of the Allegro Hand while achieving superior dexterity thanks to universal abduction-adduction kinematics. The project releases the URDF model, 3D CAD files, a tuned Isaac Gym / Isaac Lab simulation environment and Sim2Real training code, making it a popular low-cost platform for grasp and manipulation research, teleoperation and 3D-printable replication.
The Allegro Hand V4 from Wonik Robotics (Korea) is a four-finger dexterous hand for grasp and manipulation research and education: 3 fingers plus an opposable thumb with 16 independent torque-controlled joints (4 per digit), driven by DC motors with torque/current control and a 1:369 reduction ratio, delivering 0.70 N·m max joint torque and 0.11 s/60° joint speed. It weighs just 1.08 kg total (0.17 kg per finger, 0.19 kg thumb), features 0.002° potentiometer resolution, 333 Hz CAN communication, 5 kg payload capacity, and runs on 24 V / 100 W. With full APIs and tutorials for Windows / Linux / ROS / ROS 2 and 180+ research partners publishing with the platform, it is one of the most widely used research dexterous hands.