Skip to content
← Back to Components

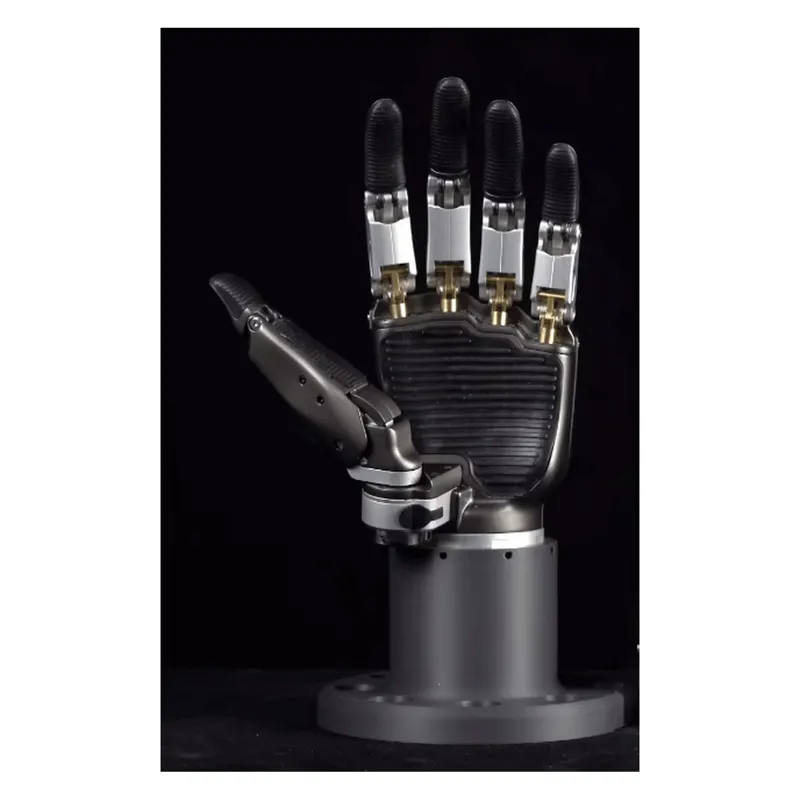
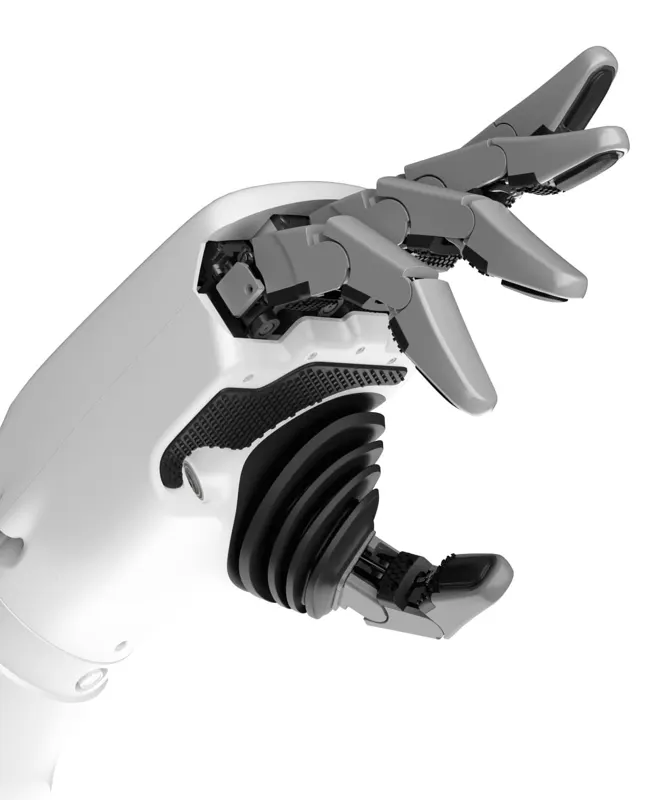
AGIBOT OmniHand Pro 2025 Dexterous Hand

Vendor: AgiBot Robotics

Product: OmniHand Pro 2025
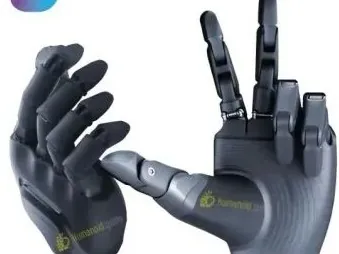
AGIBOT OmniHand Pro 2025 Dexterous Hand

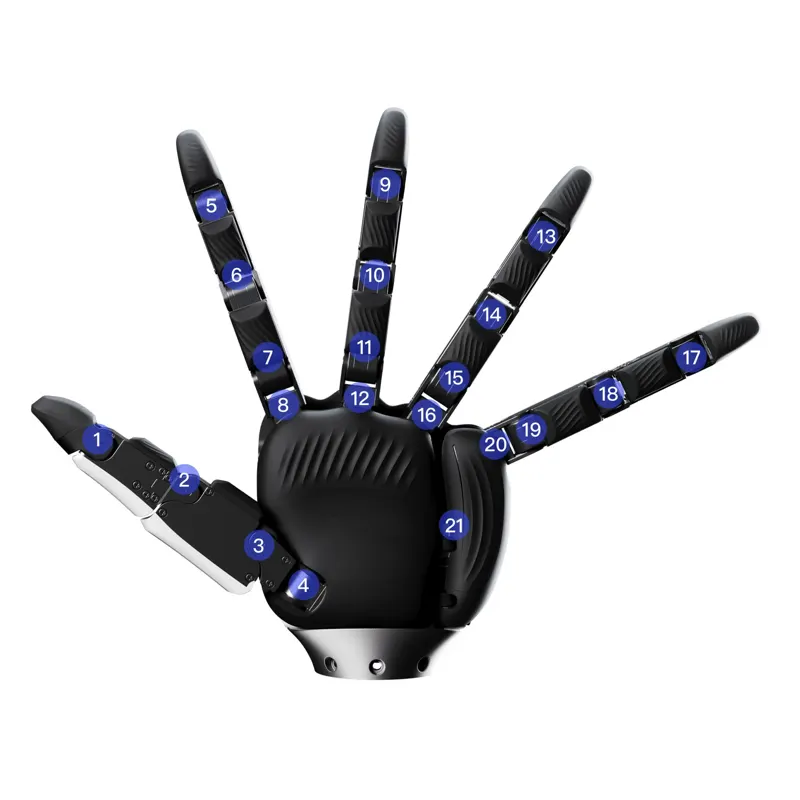
High-integration five-finger dexterous hand from Agibot with 12 active / 19 total DoF at ≤750 g; motor + screw-rod drive delivering 20 N max fingertip force and 0.02 mm finger reposition accuracy; fingertip 3-axis plus palm 1-axis force sensing with 150+ tactile points at 0.01 N resolution, and up to 35 kg palm-up load on a 5 cm rigid object.

Size207×98×56 mm
Weight≤750g
Tactile+ 150+ 0.01 N
Voltage12~24V
Total DoF19
Active DoF12
Closing Time0.8 s
CommunicationCANFD
Load Capacity35 kg / 5 kg (5cm )
Repeatability0.02 mm
Operating Temp-20~50℃
Min Grasp Diameter2 mm
Max Fingertip Force20 N

Related Components

AGIBOT OmniHand 2025 Dexterous Hand

AGIBOT OmniHand 2025 Dexterous Hand

Lightweight five-finger dexterous hand from Agibot at ≤500 g with 10 active / 16 total DoF, 0.5 mm repeatability, 5 N typical fingertip force and 1 kg typical / 2 kg max palm-up load on a 5 cm rigid object; CANFD/RS485 interfaces, with 400+ tactile points on the tactile variant.

Dexterous HandAgiBot RoboticsAGIBOT OmniHand 2025Tactile Sensing
Yuequan Bionic X-Hand M1 Bionic Dexterous Hand

Yuequan Bionic X-Hand M1 Bionic Dexterous Hand

The X-Hand M1 is Yuequan Bionic's rigid bionic dexterous hand: 11 joints with human-like hand size and segment proportions, a bionic palmar arch and ring-shaped oblique-axis design driven by a high power-density motor matrix. Strong and fast: 100 N five-finger grip and 30 N fingertip force, 40 kg whole-hand lift capacity at only 630 g; 0.4 s five-finger close time with ±0.1 mm fingertip repeatability. Sensitive perception via 472 tactile sensing units. Ethernet interface with CAN/RS485 customization; pairs with the X-Bot and W-Bot humanoids.

Dexterous HandMoon Spring Bio-mimicryX-Hand M1Tactile Sensing
X Square ArtiXon Hand Humanoid Five-Finger Dexterous Hand

X Square ArtiXon Hand Humanoid Five-Finger Dexterous Hand

20-DoF / 15-actuator humanoid five-finger hand with 0.1-20 N (+/-0.1 N) fingertip force sensing, tendon drive, <1 s open-close, 3-5 kg payload, <1 kg weight, 1M-cycle life and ROS1/ROS2 SDK.

Dexterous HandTactile SensingTendon RopeX Square
RobotEra XHAND 1 PRO Dexterous Hand

RobotEra XHAND 1 PRO Dexterous Hand

Flagship hand at 0.884 kg with 21 fully direct-driven and back-drivable active DoF, 160 mm maximum grasp diameter and 135° five-finger spread. 18 three-axis tactile sensors (5 fingertip, 10 finger-belly, 3 palm) cover 0.1-25 N at 0.01 N resolution with 10 mm proximity sensing; joint backlash under ±0.25 mm, ±0.1 mm repeatability, over 200k loaded cycles, above 5 Hz open-close and MIT, feedforward force, position and drag-teaching control modes.

Dexterous HandRobotEraXHAND 1 PROFull Direct DriveTactile Sensing

As an Amazon Associate, we earn from qualifying purchases.