Skip to content
←Back to Papers

PAPER DEEP DIVE

Figure AIHelixHumanoid

Helix: Large-Scale Neural Networks for Whole-Body Humanoid Control

Helix is an end-to-end neural framework for humanoid whole-body perception and manipulation, achieving high generalization through large-scale sim data and real-world fine-tuning.

Helix is an end-to-end neural framework for humanoid whole-body perception and manipulation, achieving high generalization through large-scale sim data and real-world fine-tuning.

Related Papers

BRACE: Adapting Whole-Body References for Force and Terrain Aware Humanoid Motion Tracking

BRACE: Adapting Whole-Body References for Force and Terrain Aware Humanoid Motion Tracking

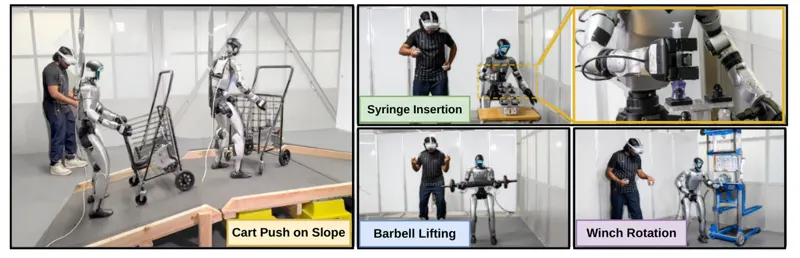
Whole-body tracking has become the interface through which operators drive humanoid robots, yet the references it consumes are recorded on level ground and carrying nothing, so the tracker knows neither the forces the robot must exchange with objects nor the terrain it stands on. Existing controllers address one side of the gap: force-capable policies command an end-effector force but prescribe no whole-body pose, while terrain-adaptive trackers treat loads as disturbances to reject rather than wrenches to command. BRACE folds both into the reference the tracker follows: terrain conformance lifts footholds and root onto the local surface, and a wrench transformation resolves the hand displacement that produces a commanded force together with the center-of-mass and center-of-pressure shifts it induces, bounded by teacher-specific arm-effort limits. Separate exertion and compensation teachers are distilled by DAgger into one flow-matching student that runs on proprioception alone, without a height map or measured wrench, so a teleoperator can supply a flat-ground trajectory while the robot resolves slope and load onboard. On the Unitree G1, in simulation and on hardware, BRACE cuts global tracking error by 40% on average and improves success rate by 18.25 points.

Sudarshan Harithas, Chen Yu, Juan Borbon · 41 views · Oct 5, 2026
HumanoidWhole-Body ControlForce controlOct 5, 2026
Systematically Exploring the Capabilities of GPT-6 Astra as Embodied Policies

Systematically Exploring the Capabilities of GPT-6 Astra as Embodied Policies

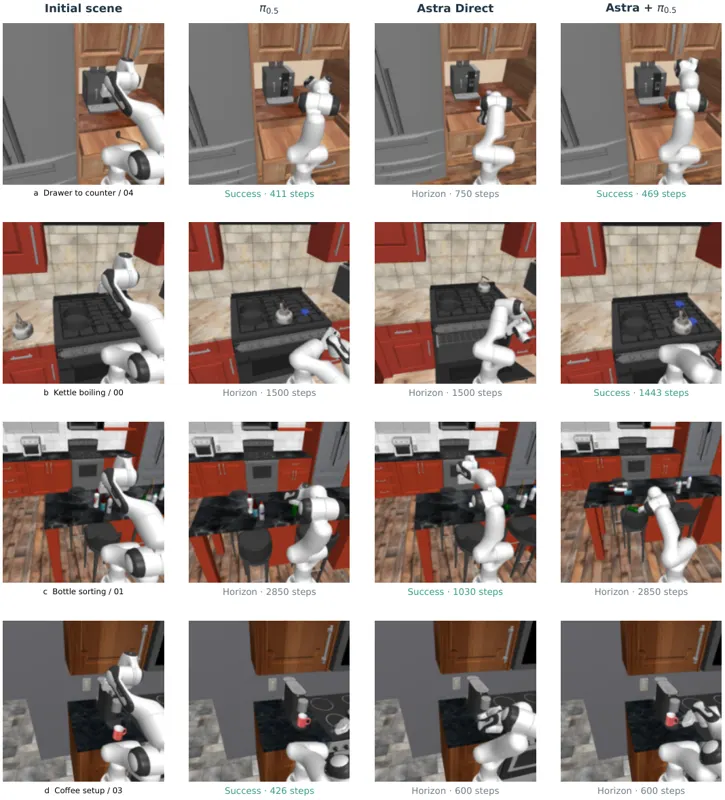
Evaluates GPT-6 Astra as an embodied policy across six domains: hybrid control reaches 48% on RoboDojo and 92% on RxR navigation, while direct in-hand control and dense locomotion references stay unreliable; token use and inference latency constrain practical control.

Galbot Team, Chen, Xuchuan, Cheng, Xiaoqian · 61 views · Sep 29, 2026
Embodied AIRobot ManipulationDexterous ManipulationSep 29, 2026
ASENA: Self-evolving Agents for Embodied Navigation

ASENA: Self-evolving Agents for Embodied Navigation

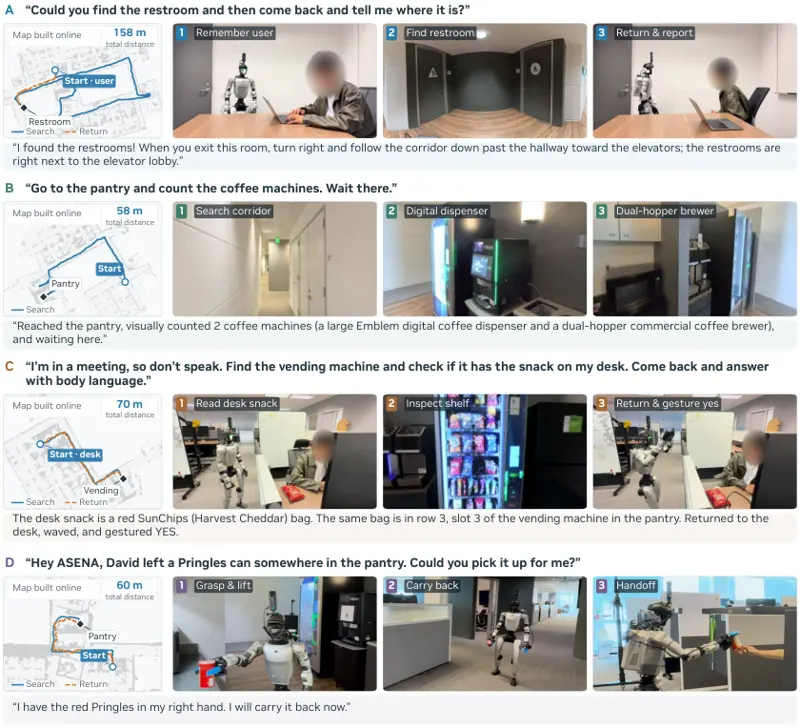
We present ASENA, an embodied agent system that enables general-purpose coding agents to program humanoid navigation, manipulation, and interaction. Through a unified robot harness, agents read sensor data, write and execute programs, inspect recorded outcomes, repair failures, and reuse notes and executable skills while keeping their model weights fixed. We also introduce ASENA-VLN, a 4B monocular navigation policy that serves as an optional tool within this programmable system. ASENA-VLN predicts body-frame trajectories for both extended routes and short-horizon behaviors. Its shared vision-language decoder is trained on route instructions, visual question answering, and a newly curated dataset of geometry-derived atomic navigation tasks. As a standalone policy, ASENA-VLN achieves state-of-the-art success rates of 68.7% on R2R and 70.2% on RxR. When integrated with a coding agent, learned navigation improves ASENA's success rate by 11 percentage points on both agentic benchmarks and reduces execution time. Persistent workspace evolution uses simulator feedback to improve success over ten passes through recurring 100-task subsets. Success increases from 72% to 98% on R2R and from 65% to 89% on RxR. On embodied question answering, ASENA achieves state-of-the-art accuracy with fewer interaction steps. On a Unitree G1, we demonstrate search, visual inspection, spatial reasoning, synthesized gestures, and mobile manipulation combining object pickup, carrying, and handoff without a pre-built map. These demonstrations illustrate how online programming extends robot behavior beyond route following and predefined skills.

An-Chieh Cheng, Isabella Liu, Edmund Bu · 65 views · Sep 30, 2026
Vision-language navigationEmbodied AIHumanoid robotsSep 30, 2026
PanTact: Teaching Whole-Body Dexterity with a Wearable Contact Interface

PanTact: Teaching Whole-Body Dexterity with a Wearable Contact Interface

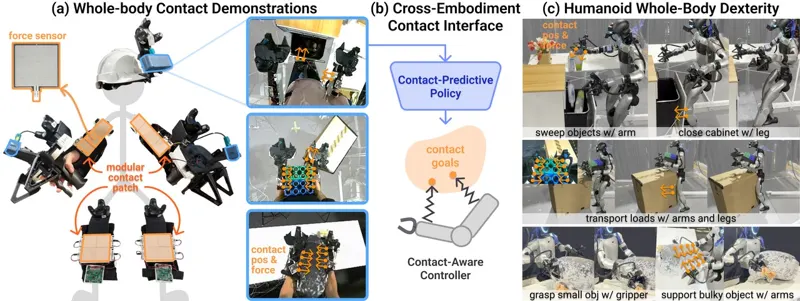
PanTact treats contact, not joint trajectories, as the transfer currency from people to humanoids. Wearable patches are assembled magnetically from 44x44 mm FSR modules; a custom 50x50 mm PCB streams 16 channels at 1 kHz over a CRC-checked RS-485 daisy chain, one Vive tracker per patch maps sensor centers into the world frame, and contact states are binarized against a per-channel adaptive baseline with threshold max(0.35 beta, r_min). The policy observes body-masked 3D egocentric point clouds, both wrist images and proprioception, and at 10 Hz predicts an action chunk of H=16 steps containing a look-at point, EEF poses with gripper widths, and per-sensor contact goals (binary state plus 3D position). A soft-minimum proximity d(p,q) with T = 0.02 m hands each active contact to whichever robot surface is currently nearest, and active goals are offset by delta along the pressing direction to form virtual goals that generate pressing force, so the G1 holds objects without any tactile sensor on its body. Three control formulations trade off differently: training-free upper-body IK, WBIK whose dense reference is executed by SONIC, and a sparse contact tracker trained with PPO over 4096 simulation environments for 30k iterations (50 Hz, 29 joints, S=8 upper-body / S=16 whole-body contact slots). On a 29-DoF Unitree G1: Grasp-and-Embrace reaches 85% with upper-body IK and 80% with the sparse tracker against 0% for Humanoid UMI; Sweep-and-Stow reaches 90.63% end to end while Humanoid UMI++ scores 18.75% on each stage and 0% end to end; Carry-and-Push is 90% versus 40%. In simulation replay, adding contact goals lowers contact distance for all three controllers at almost no cost in EEF accuracy.

Xu, Xiaomeng, Zhang, Han, Ruan, Zhian · 136 views · Oct 8, 2026
Whole-Body ManipulationTactile SensingContact-Rich ManipulationOct 8, 2026

As an Amazon Associate, we earn from qualifying purchases.