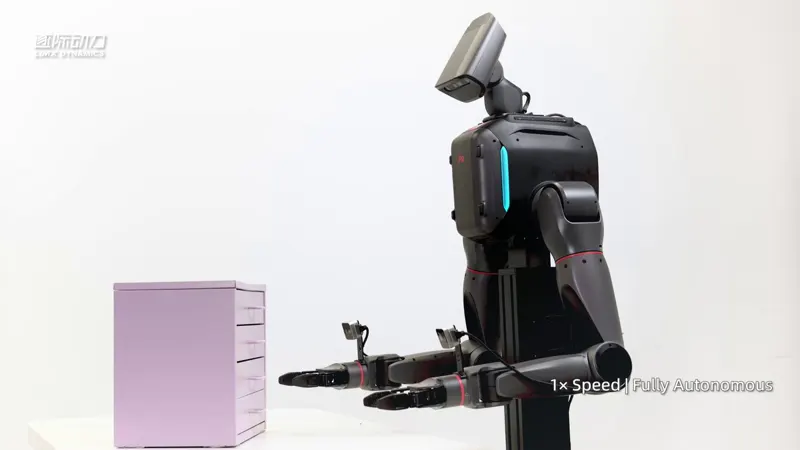
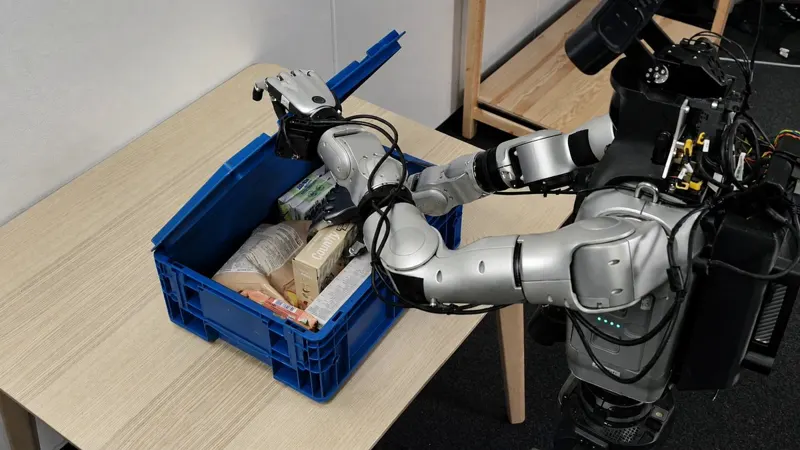
LimX Dynamics TRON 2 runs a temporally constrained VLA sequence: identify the drawer, pull it open, locate the toy, then retrieve it precisely. One wrong step fails the task.
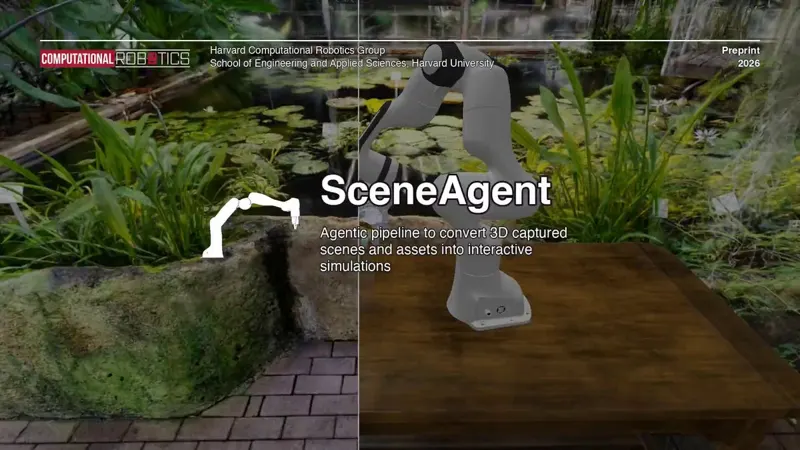
Harvard SceneAgent turns image, video, LiDAR or 3DGS captures into interactive sim scenes: per-Gaussian semantics, baked predictive physics, part decomposition, articulation and digital sisters, exported as USDZ for Isaac Lab, MuJoCo and Unreal.
XPENG released XPACE, a unified embodied world model for IRON: one shared video backbone learns both the action and the post-action visual future, trained on 5,000 hours of embodied video spanning human egocentric, human video-action, bridge and teleoperation data. Its world simulator perturbs expert trajectories, simulates deviation and recovery, filters the generated examples and feeds recoveries back into policy training.
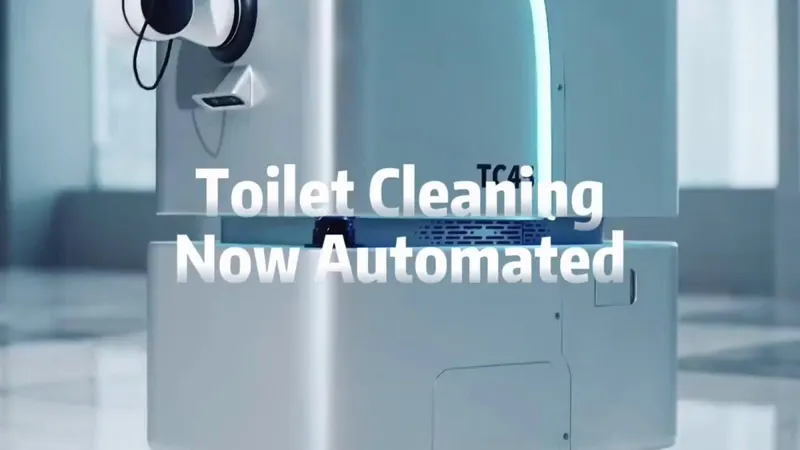
RealMan demonstrated an autonomous restroom-cleaning robot that plans paths, switches cleaning end-effectors, and completes multi-step workflows.
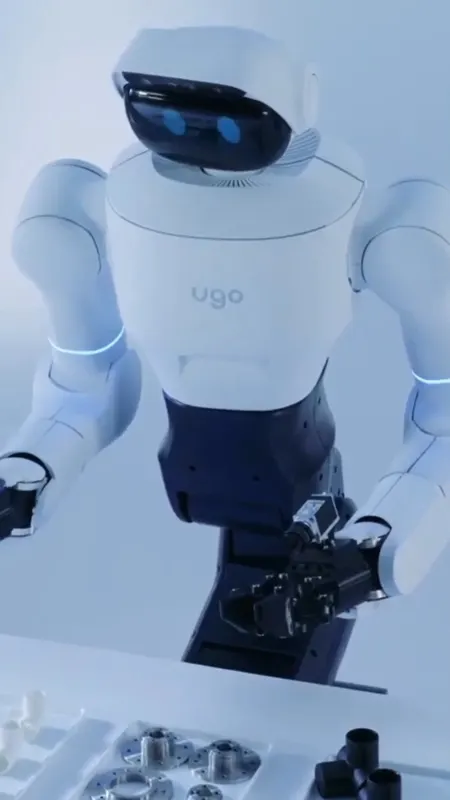
ugo Nova is a 22-DoF wheeled semi-humanoid with a 10 kg dual-arm payload, Jetson Thor onboard, and 100 Hz teleoperation that records synchronized video, joint, torque, and command data.
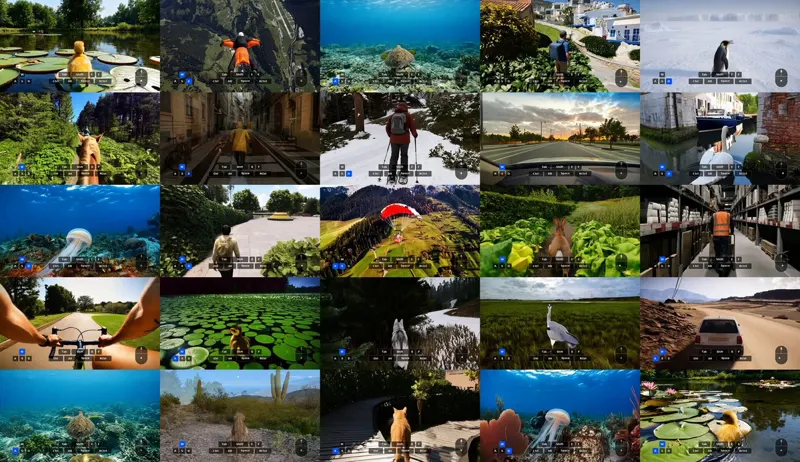
Odyssey-3 renders interactive generated worlds driven in real time by keyboard and mouse: a rabbit in a meadow, first-person cycling, a warehouse picker among shelves. If a world model can simulate infinite, intelligent worlds, it becomes the place where agents themselves are trained.
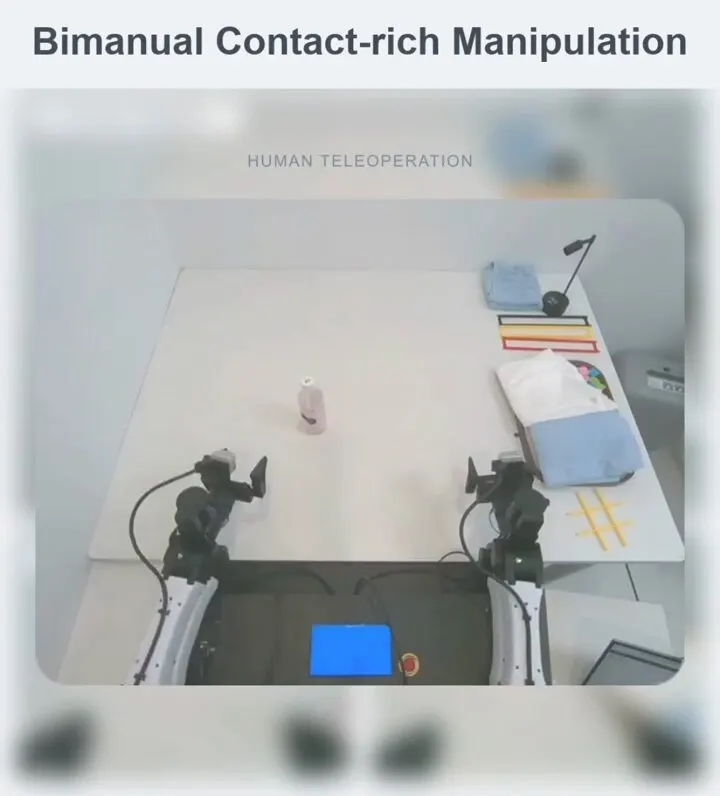
GPT-Policy releases code and new results: a fixed GPT-6 VLM, wrapped in a context compiler and a constrained Cartesian controller, drives dual arms in closed loop. Human video, goal images or a single demonstration let it perform occlusion-aware picking, bimanual contact-rich manipulation and gesture imitation zero-shot, with no gradient updates.
Odyssey-3 is an autoregressive diffusion-transformer foundation world model that controls robot arms, humanoids, cars, and drones with task-specific experiential data.
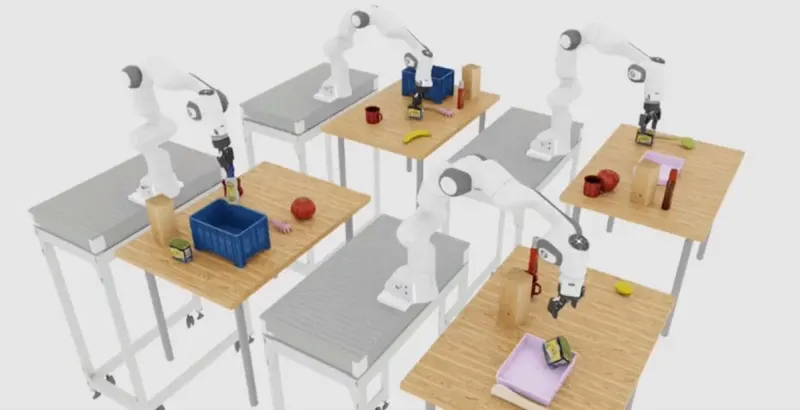
A policy that succeeds in a demo can still fail as tasks, environments, and conditions change. Open-source Isaac Lab-Arena 0.3 adds an experimental agentic workflow that generates simulation environments from natural language, evaluates policies across thousands of parallel GPU environments, and pinpoints where and why failures occur.
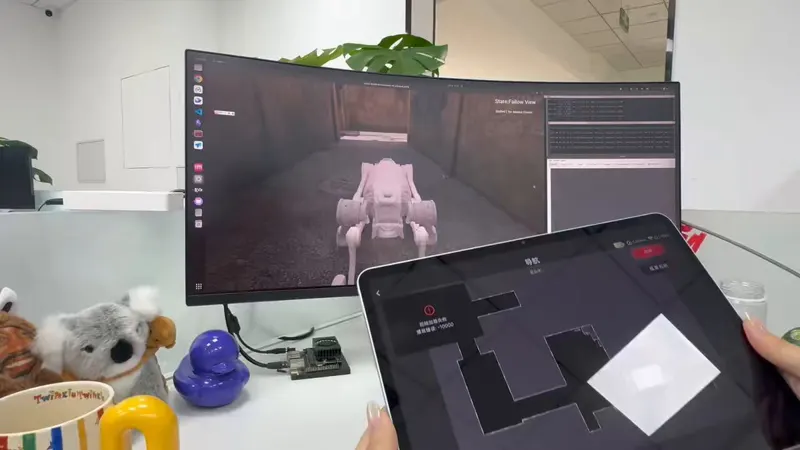
MATRiX combines UE5 and MuJoCo in a processor-in-the-loop robot simulation, streaming dual Airy LiDAR and front/rear RGB sensor data to Jetson NX and RK3588 hardware.
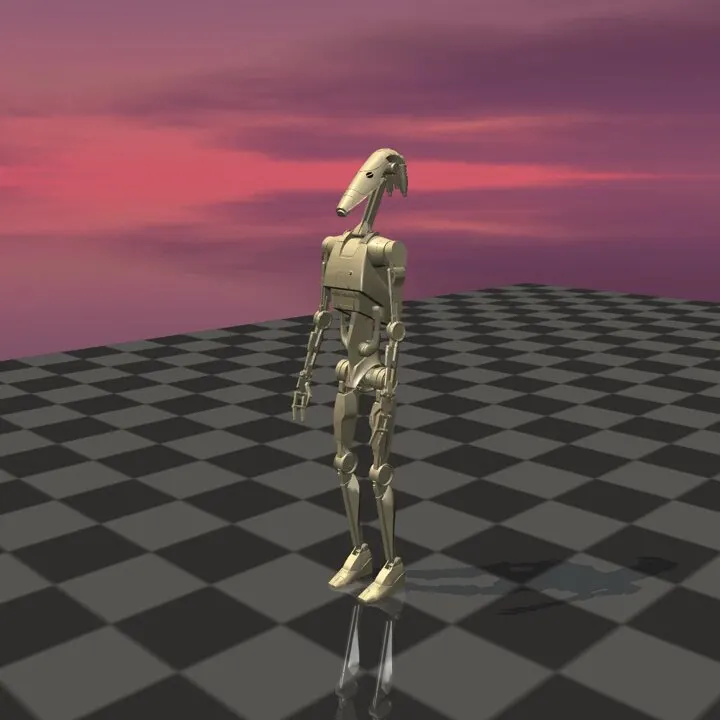
Using mjbatch to run parallel MuJoCo rollouts, the author trained a bipedal humanoid locomotion policy in just 15 minutes on a MacBook Air M2; the clip shows the simulated robot following velocity commands.
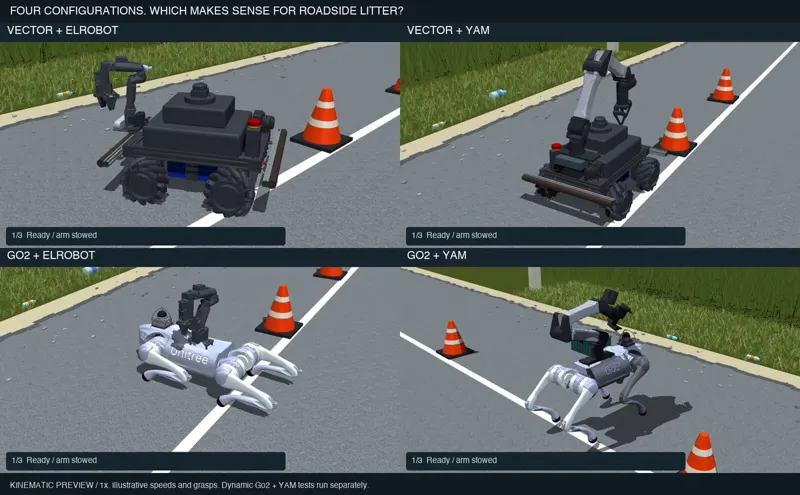
A scripted simulation compares Vector, a mecanum rover, and Unitree Go2 with YAM or ElRobot arms on the same roadside-litter task: collect three bottles and return them to a crate.
As an Amazon Associate, we earn from qualifying purchases.