Long-WAM: Scaling World-Action Model Context to 19.2s in Real Time
Loading video
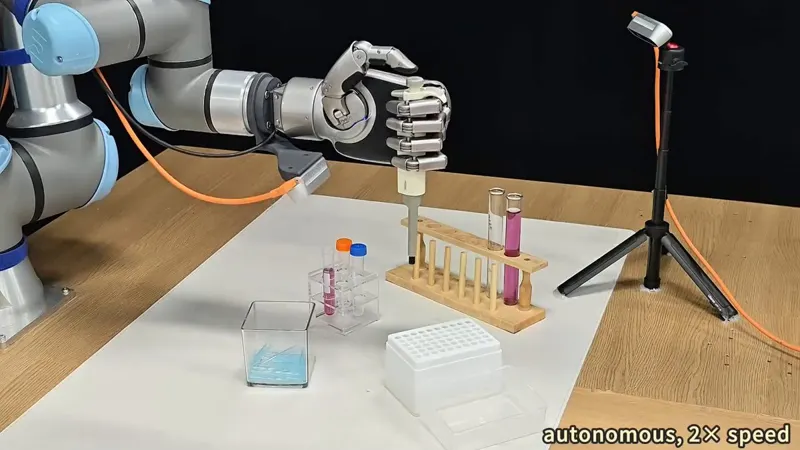
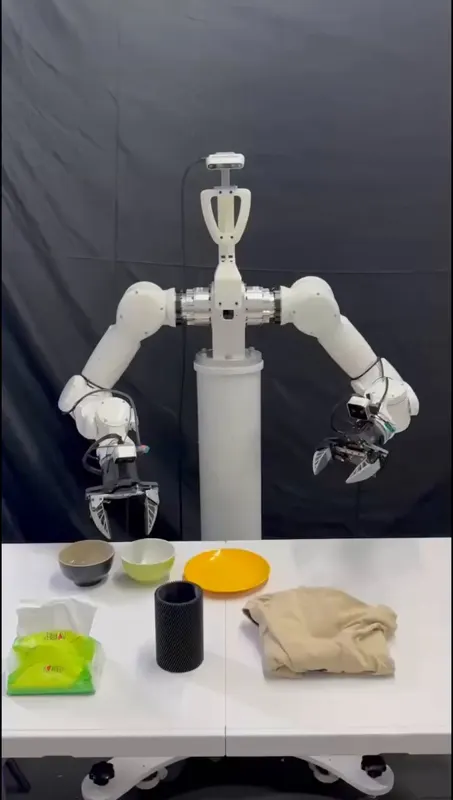
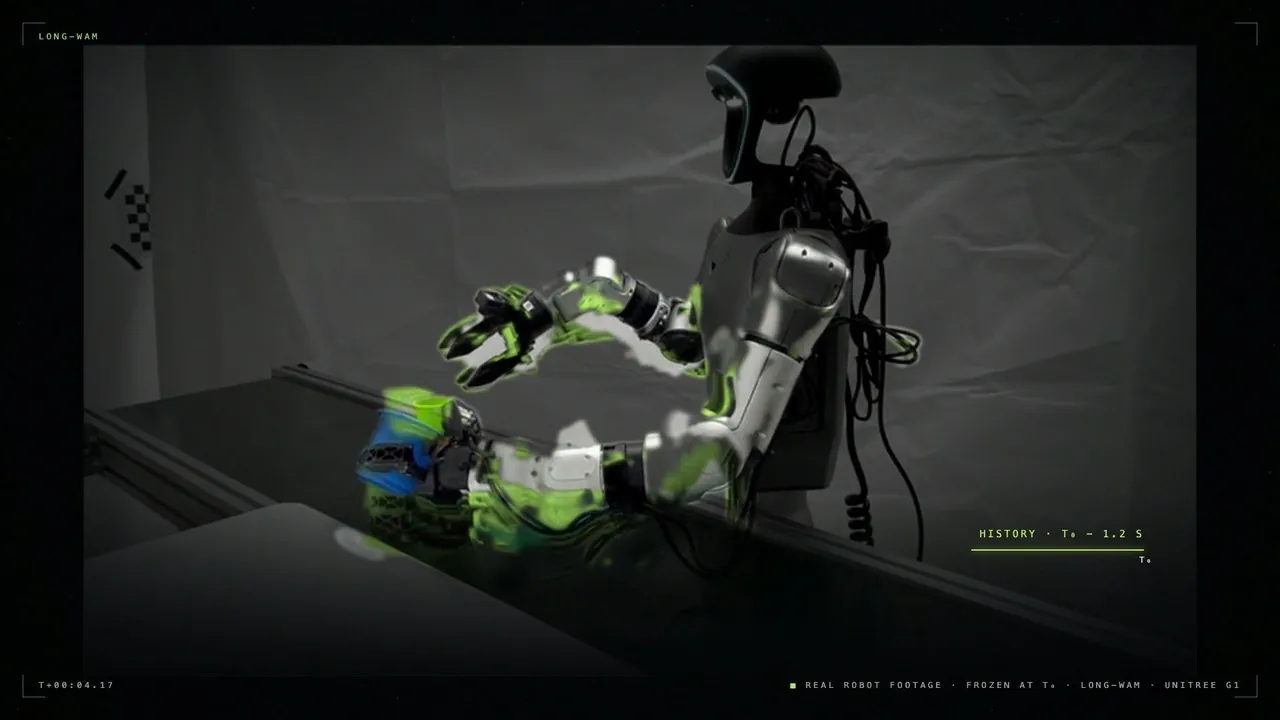
Loading videoLong-WAM is a model-system framework for scaling the visual context of causal world-action models under real-time control constraints. Autoregressive video pretraining turns longer history into better control: extending context from 2.4s to 19.2s lifts RoboCasa GR-1 success from 66.3% to 78.7%, alongside 99.5% on LIBERO-Long, 94.4% on RoboTwin 2.0 and 95% dynamic cup stacking on a Unitree G1. Streaming observation encoding and asynchronous execution keep inference at 107.4ms per action chunk on an RTX 5090, with deployment on DGX Spark and Jetson AGX Thor. From NVIDIA, MIT, HKU and UCSD.
Category: research
Author: @AaronWeiHuang
Date: 2026-10-08T00:00:00
Duration: 158.0s
Reference: https://nvlabs.github.io/LongLive/Long-WAM/