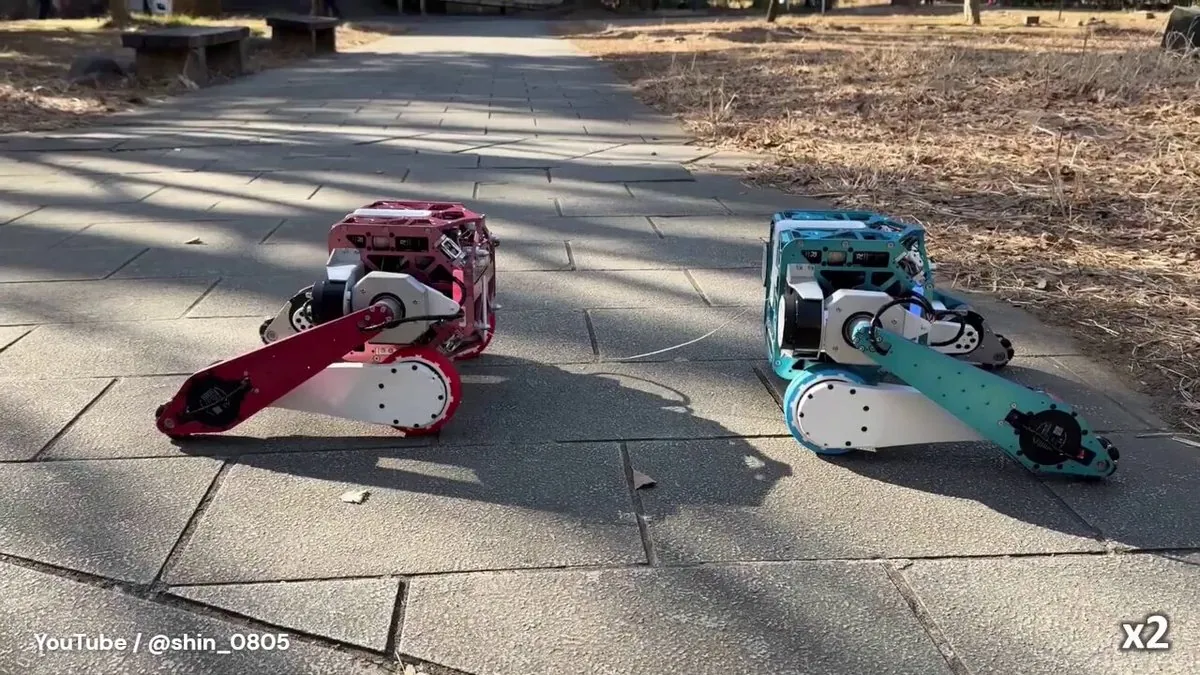
TwinX: One Wire, Two Robot Bodies
Loading video
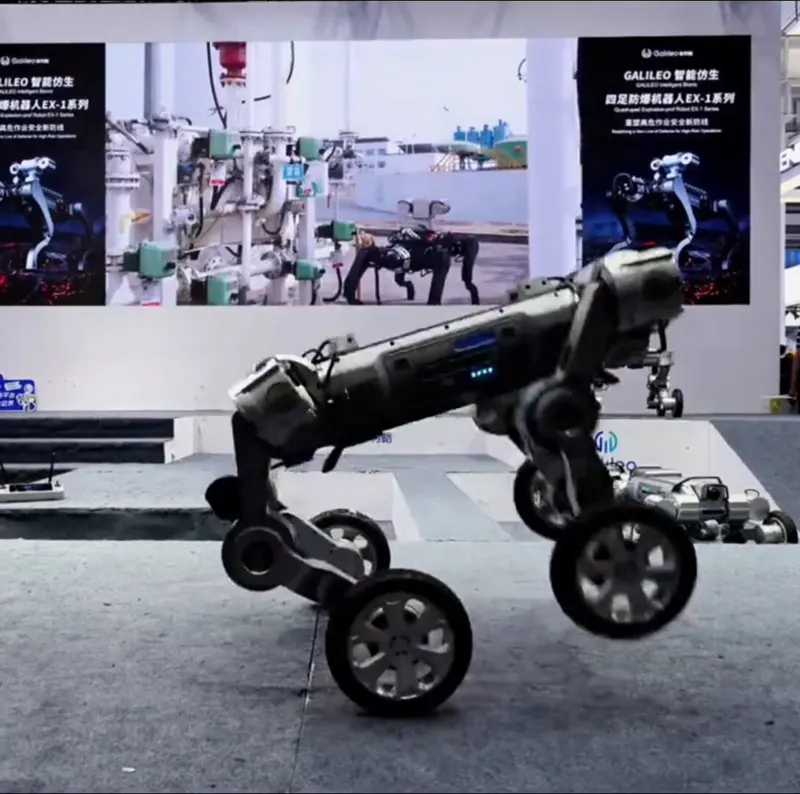
Loading videoTwo wheeled-legged robots use one interbody wire to switch between quadruped, swerve-drive, and dual-arm modes, then cooperate after separation to enclose debris, hook objects, and transmit force.
TwinXReconfigurable RobotWheeled-Legged RobotWired ActuationModular RobotPhysical AITeleoperationRobot DesignWheel-legged robots
Category: quadruped
Author: @ZappyZappy7
Date: 2026-10-16T00:00:00
Duration: 67.3s
Reference: https://shin0805.github.io/twinx-bridging/