Q2: an RL-first quadruped redesign with four identical legs and direct-drive knees
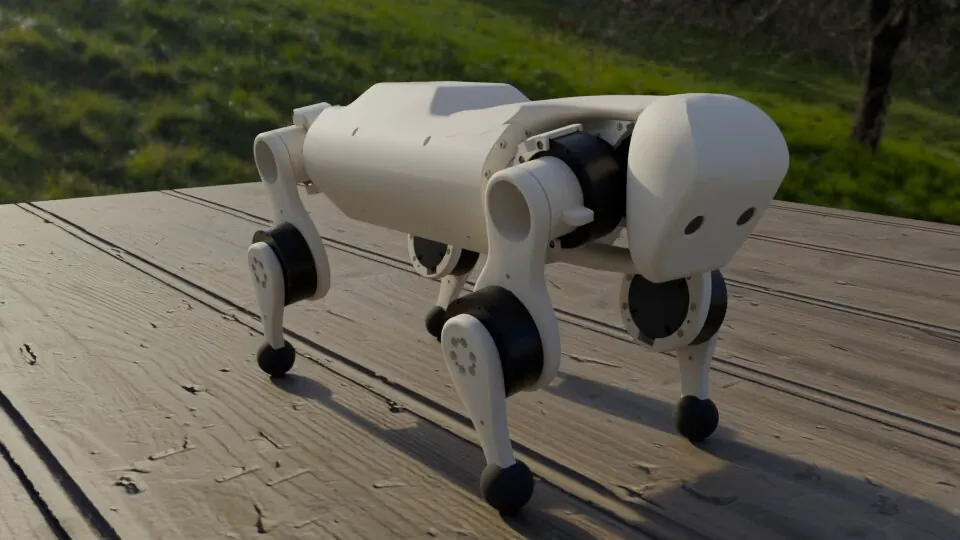
The author presents Q2, a redesign of their Q1 quadruped, and describes it as a major simplification and an AI-first design: the layout was first checked to reach fast RL convergence in simulation, and only then moved into CAD. The eight listed points are four identical legs with no left or right parts, direct-drive knees with no linkage or belts, no reduction gear after the motor output, knees that rotate 360 degrees so there is no predefined knee posture, a low standing load that needs almost no knee torque, shorter links for lower leg inertia and joint torques, the battery placed at the geometric center for a better center of gravity, and a single spec file that drives both the simulation model and the CAD. The author calls this parametric CAD taken to the extreme, where the CAD software is only used to review the design rather than to build it, and says weight, cost, manufacturing time and assembly effort would all drop significantly while the battery design, PCB and compute stay the same.