ROS Tutorial 15 Deep Read: robot_localization — from wheel odometry & IMU to robot state estimation
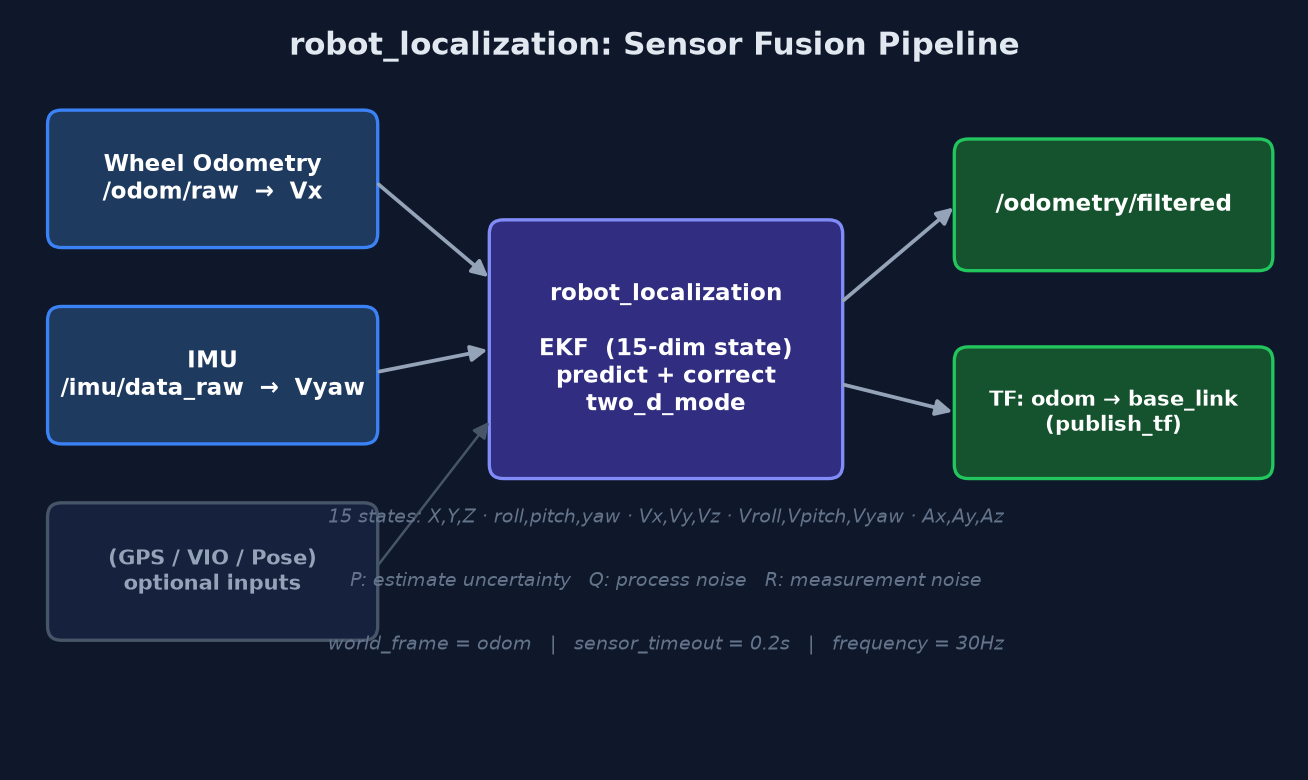
A deep read of chapter 15 of wdfk-prog's ROS tutorial series: why you need robot_localization even when the driver already publishes /odom. Covers EKF vs UKF predict-correct over 15 states (31 sigma points), the real roles of P/Q/R covariances, the data-provenance thinking behind 15-bit _config switches, the semantic gap between differential (velocity) and relative (pose), TF ownership refactoring (/odom→/odom/raw, EKF takes over odom→base_link), world_frame and sensor_timeout time semantics, and the contract-first mindset: every observation must answer who measured it, in which frame, at which time, and how trustworthy it is.
BLOG
ROSrobot_localizationEKFUKFTF