Skip to content
← Tags

#Behavioral foundation models (4)

P-BFM: Perceptive Behavioral Foundation Models for Humanoid Control via Unsupervised Reinforcement Learning

P-BFM: Perceptive Behavioral Foundation Models for Humanoid Control via Unsupervised Reinforcement Learning

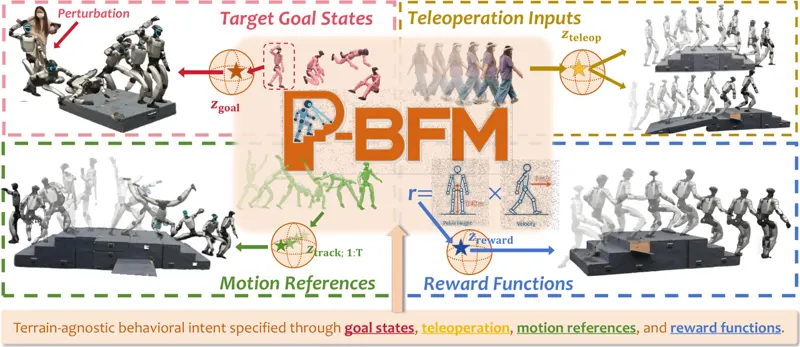
Behavioral foundation models (BFMs) provide humanoids with reusable repertoires of whole-body behaviors; in real-world humanoid control, the same behavioral intent may require fundamentally different motions under different terrain constraints. Covering such variation with terrain-matched demonstrations requires enumerating a combinatorial space of behaviors and terrain geometries. We introduce P-BFM, a perceptive behavioral foundation model that factorizes humanoid control into terrain-invariant intent and terrain-conditioned realization. A forward-backward representation maps motion references, target states, and reward functions into a shared intent space without terrain information, while a perceptive policy learns how to realize each intent under the surrounding terrain geometry. We further identify a complementary limitation of purely latent control: behavioral latents can preserve local motion patterns while losing precise global progress. We therefore introduce Explicit Root Instructions (ERI), which separates global transport (e.g., heading and planar velocity) from behavioral intent, while leaving local whole-body adaptation to the perceptive policy. This decomposition leads to a characteristic capability absent from conventional BFMs: one fixed intent induces different, terrain-appropriate behaviors, including changes in step height, stride, posture, foothold placement, and contacts, without terrain-specific demonstrations. Across challenging terrains, P-BFM improves motion fidelity, root-control precision, and perturbation recovery over strong baselines. A single frozen policy further supports motion tracking, goal reaching, reward inference, teleoperation, and terrain-aware recovery, and transfers zero-shot to a Unitree G1 using onboard depth sensing.
Xue Wang, Yitang Li, Yiming Zhang · 412 views · Oct 11, 2026
HumanoidUnsupervised Reinforcement Learning
Oct 11, 2026
Scaling Behavior Foundation Model for Humanoid Robots

Scaling Behavior Foundation Model for Humanoid Robots

Humanoid control requires natural whole-body coordination, precise real-time responses to control signals, and robust generalization across diverse environmental contexts, making it a cornerstone for generalist embodied agents. Behavior Foundation Models (BFMs) have recently emerged as a promising solution to address these challenges by leveraging large-scale behavioral data to achieve superior expressiveness, versatility and generalization. However, despite growing interest in scaling BFMs to further improve their capabilities, it remains unclear how key factors, including the learning paradigm, behavioral data and model architecture should be coordinated to enable effective scaling. In this work, we revisit the scaling recipe for BFMs and demonstrate that substantial performance gains can be achieved through the coordination of three core components: 1) the learning paradigm of motion tracking that reformulates diverse humanoid control problems as the reproduction of integrated whole-body behaviors in the global frame; 2) the strategic synergy between on-policy rollout quantity and reference motion diversity; and 3) the expressive and scalable model architecture termed Humanoid Transformer that facilitates the natural emergence of structured behavioral representations. Through extensive experiments in both simulation and real-world deployment, we demonstrate that our approach yields significant improvements in control fidelity and task generalization, reducing Mean Per-Keypoint Position Error (MPKPE) on the test set by over 10% in local mode and 82% in global mode compared with existing humanoid controllers. These results establish BFM as a principled and effective foundation for scalable and general-purpose humanoid control.

Weishuai Zeng, Kangning Yin, Xiaojie Niu · 441 views · Jul 16, 2026
HumanoidBFM
Jul 16, 2026

As an Amazon Associate, we earn from qualifying purchases.