Skip to content
← Tags

#Boston Dynamics Spot (9)

Learning Multi-Phase Robot Loco-Manipulation via Phase-Conditioned Policy Optimization

Learning Multi-Phase Robot Loco-Manipulation via Phase-Conditioned Policy Optimization

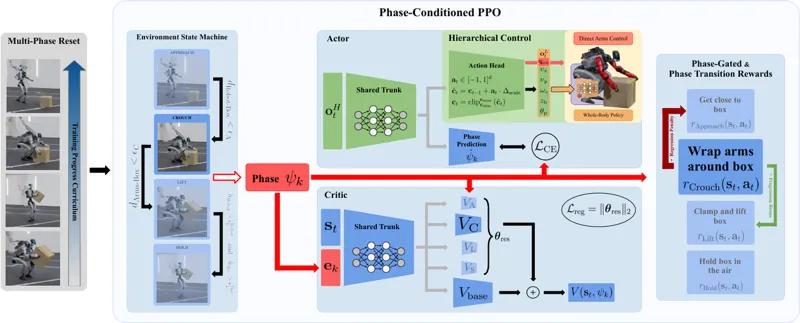
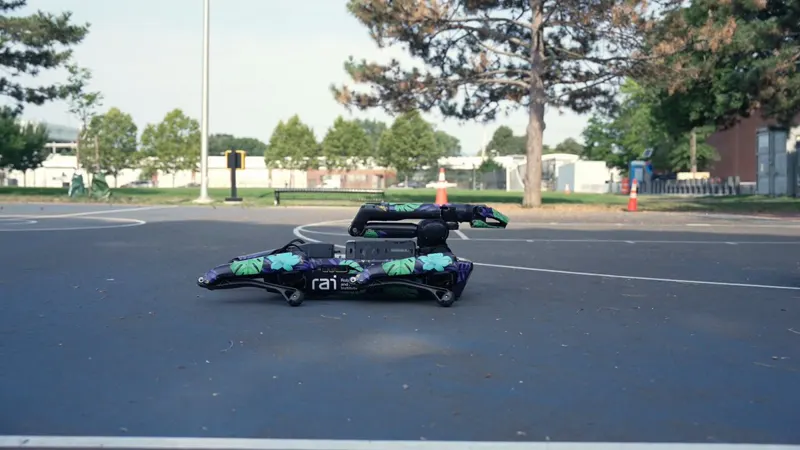
Complex whole-body loco-manipulation requires executing diverse maneuvers, such as crouching, grasping, and locomotion, within a single long-horizon task. While performing simple pick-and-place behaviors is well-established, scaling to complex, long-horizon tasks remains difficult. Currently, this challenge is addressed by relying on human motion data and correspondingly humanoid platforms, which limits platform independence and introduces substantial data processing overhead. Instead, we extend proximal policy optimization (PPO) to train a single policy for multi-phase tasks across diverse robotic hardware, leveraging prior task structure to shape behavior. Our method adapts PPO using a phase-conditioned critic, phase-gated reward functions, and a multi-phase reset curriculum to guide exploration. To support varied hardware, we employ a decoupled hierarchical control architecture that separates lower-level balancing dynamics from high-level phase execution. We demonstrate multi-stage loco-manipulation skills on hardware on both the Unitree G1 and a Boston Dynamics Spot equipped with a manipulator arm, and validate our design choices through ablations. Our approach enables the acquisition of complex loco-manipulation behaviors purely through environment interaction while directly incorporating high-level task structure into policy learning.
Simone Manni, Annika Wollschläger, Dario Bellicoso · 96 views · Oct 26, 2026
Whole-Body Loco-ManipulationPhase-Conditioned PPO
Oct 26, 2026
ZEST: Zero-shot Embodied Skill Transfer for Athletic Robot Control

ZEST: Zero-shot Embodied Skill Transfer for Athletic Robot Control

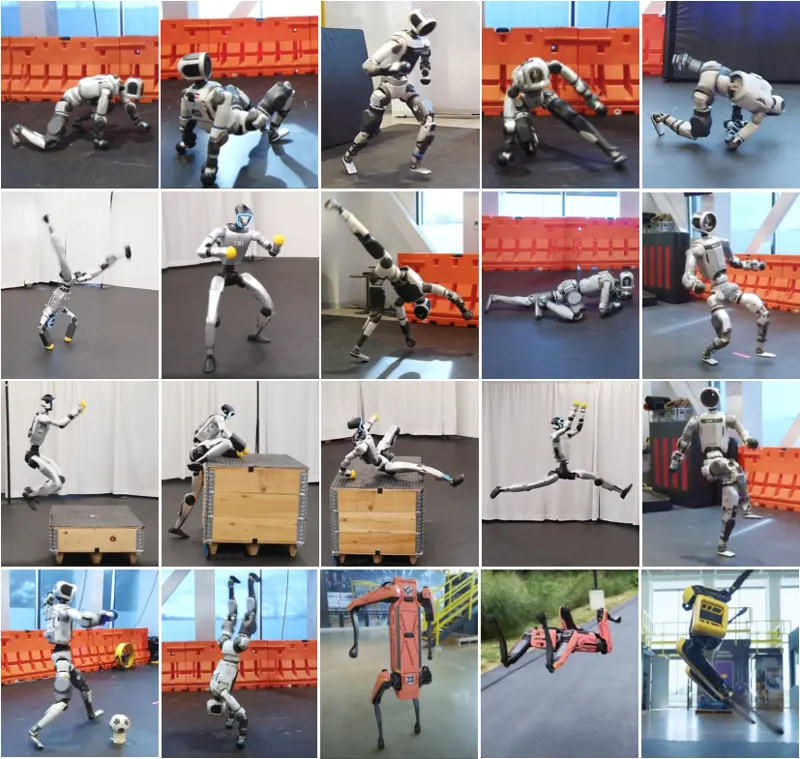
Achieving robust, human-like whole-body control on humanoid robots for agile, contact-rich behaviors remains a central challenge, demanding heavy per-skill engineering and a brittle process of tuning controllers. We introduce ZEST (Zero-shot Embodied Skill Transfer), a streamlined motion-imitation framework that trains policies via reinforcement learning from diverse sources – high-fidelity motion capture, noisy monocular video, and non-physics-constrained animation – and deploys them to hardware zero-shot. ZEST generalizes across behaviors and platforms while avoiding contact labels, reference or observation windows, state estimators, and extensive reward shaping. Its training pipeline combines adaptive sampling, which focuses training on difficult motion segments, and an automatic curriculum using a model-based assistive wrench, together enabling dynamic, long-horizon maneuvers. We further provide a procedure for selecting joint-level gains from approximate analytical armature values for closed-chain actuators, along with a refined model of actuators. Trained entirely in simulation with moderate domain randomization, ZEST demonstrates remarkable generality. On Boston Dynamics' Atlas humanoid, ZEST learns dynamic, multi-contact skills (e.g., army crawl, breakdancing) from motion capture. It transfers expressive dance and scene-interaction skills, such as box-climbing, directly from videos to Atlas and the Unitree G1. Furthermore, it extends across morphologies to the Spot quadruped, enabling acrobatics, such as a continuous backflip, through animation. Together, these results demonstrate robust zero-shot deployment across heterogeneous data sources and embodiments, establishing ZEST as a scalable interface between biological movements and their robotic counterparts.

Jean Pierre Sleiman, He Li, Alphonsus Adu-Bredu · 835 views · Jan 30, 2026
ZESTSim-to-Real
Jan 30, 2026

As an Amazon Associate, we earn from qualifying purchases.