
EgoScale: Scaling Dexterous Manipulation with Diverse Egocentric Human Data
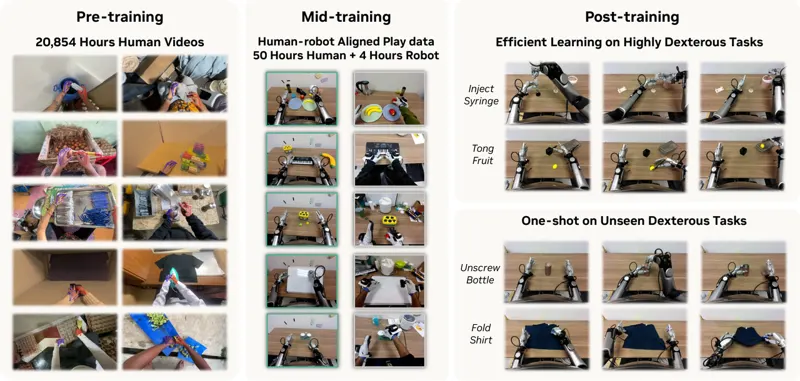
EgoScale is a human-to-dexterous-manipulation transfer framework. A VLA policy is pretrained on 20,854 hours of action-labeled egocentric human video, revealing a log-linear relationship between data scale and validation loss. Lightweight aligned human-robot mid-training then grounds the learned motor prior in robot control, improving average success by 54% over a no-pretraining baseline on a 22-DoF dexterous hand and transferring to lower-DoF hands.
Ruijie Zheng, Dantong Niu, Yuqi Xie · 22 views · Feb 18, 2026
Dexterous ManipulationVLA
Feb 18, 2026