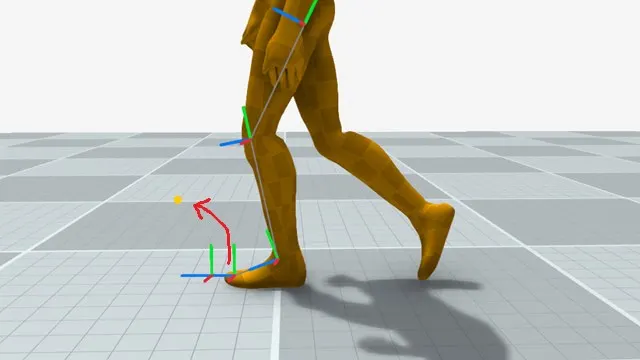
A practical recipe for foot sliding: solve the leg with soft-clamped two-bone IK and toe orientation, lock the toe target during contacts with inertialization, annotate contacts automatically, then use a position-based dynamics-style offline pass to distribute corrections. The key insight is velocity preservation, not sticking to the ground, and the toe—not the heel—is what should be locked.
BLOG
As an Amazon Associate, we earn from qualifying purchases.