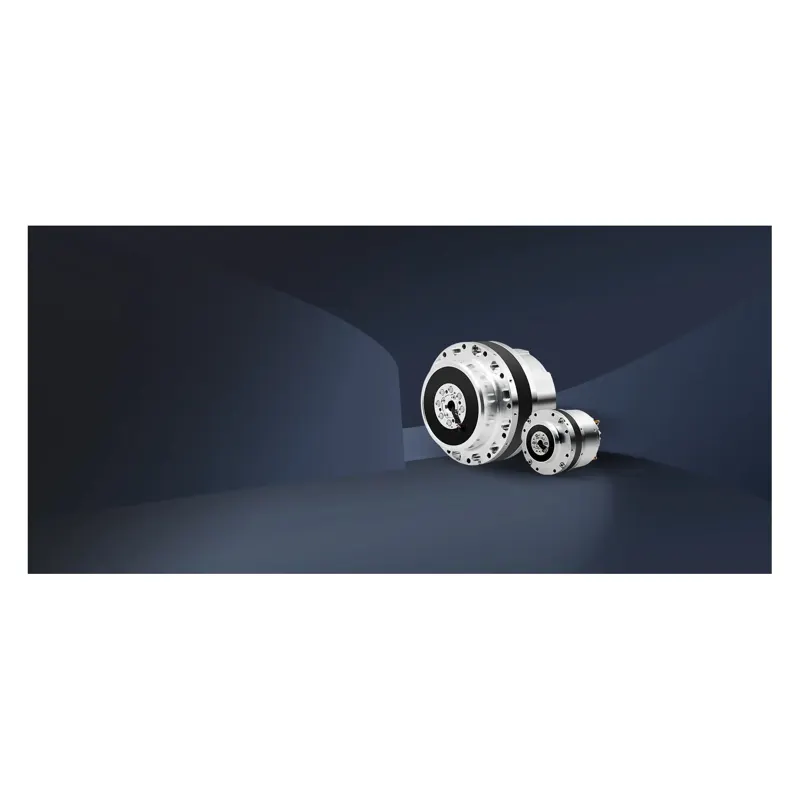
Integrated force-control joints combining an inner-rotor frameless torque motor, reducer, dual absolute encoders and a torque sensor; six sizes HSA-11 to 32 with 11-459 Nm peak torque, 100 Hz force loop, 32 kHz sampling and EtherCAT, delivering high torque density for humanoid and wheeled dual-arm robots.
COMPONENT
The MJBX series from Techsoft Robots (Shenzhen Techsoft Intelligent Robot Co., Ltd.) is a force-controlled rotary joint module family for humanoid robots, integrating a harmonic reducer, optional 1-axis torque sensor, driver, dual encoders, motor and permanent-magnet brake; four frame sizes span 70/80/90/110 mm diameters at 0.84-2.3 kg, with 13.5-133 N·m average load torque, 376 N·m peak instantaneous torque, 80 rpm max speed and <60 arcsec repeatability; 48 V supply, 17-bit absolute encoder, EtherCAT/CANopen, IP40, 20,000 h reducer life, OEM/ODM available for rapid humanoid, bipedal and heavy bionic robot builds.