METATRON: A Promptable Whole-Body Execution Layer for Humanoids
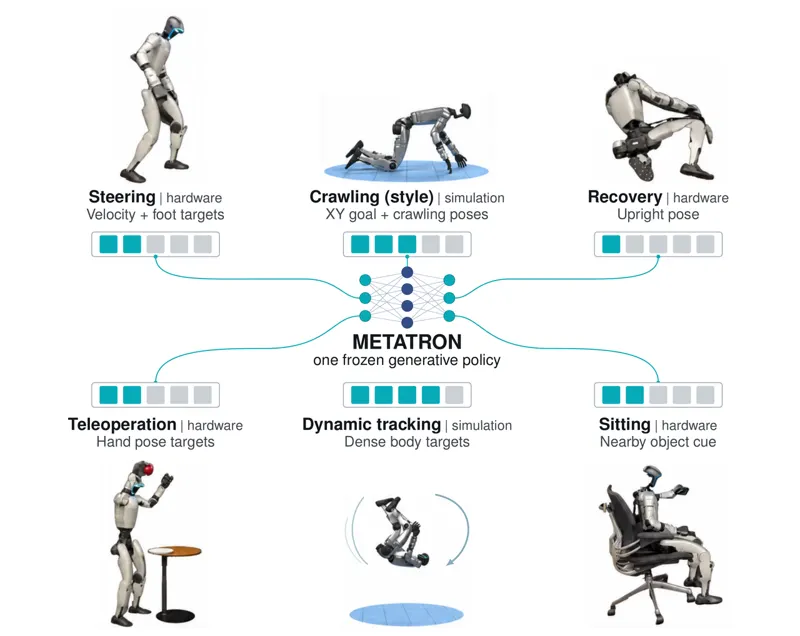
Humanoid controllers often require task-specific training despite sharing the need for balance and whole-body coordination. We present Metatron, a promptable whole-body execution layer combining a generative base policy with a programmable skill layer. The base policy receives partial goals, collectively called a prompt, that can combine timed body-part targets, velocity commands, and style cues. It produces diverse whole-body motions consistent with these goals. Training combines motion capture, synthetic recovery trajectories, and retargeted scene-interaction motions. After training, the policy is frozen. Stateful programs called skills express task intent as prompts at each control step, drawing rough geometric sketches that the policy turns into coordinated movement. Skills are ordinary code, refined by coding agents that analyze motion data and fit compact rules without task-specific policy training. On the physical Unitree G1, one frozen checkpoint supports walking, recovery, teleoperated object pickup, and sitting on furniture. Comparative evaluations show higher reaching success and push robustness than the tested reference-tracking pipelines. The same recipe produces climbing and acrobatics on a simulated character. Metatron enables coding agents to turn learned motor capabilities into new skills through code, without further policy training.