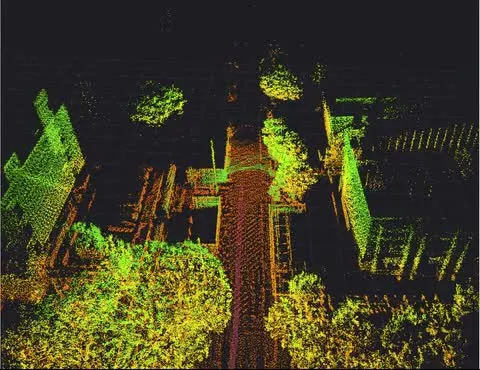
glass-LIO is an open-source scan-to-map LiDAR-inertial odometry for the Livox MID-360, described by its author as “written to be read”: each of its six pipeline stages has a deep-dive write-up, the manifold Gauss-Newton solver is under 200 lines of Eigen with no Ceres/GTSAM, and every bug that produces plausible output is documented — including the full failure post-mortem of tight coupling diverging on real data. It runs real time at 10 Hz on the test bag with zero dropped scans and steady RMSE around 0.13 m.
BLOG
As an Amazon Associate, we earn from qualifying purchases.