0:59Non-prehensile throwing lets a UR5e toss objects without grasping@heetezition · 1.2k views · 2026-09-02UR5eRobot Arms
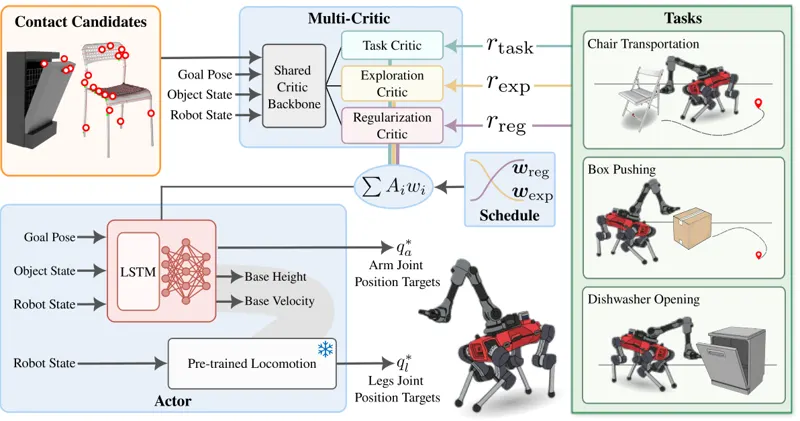
Contact-Guided Exploration for Non-Prehensile Locomanipulation with Multi-Critic RLThe paper turns 25 grasp-algorithm candidates into a retractable exploration objective, separates task, exploration, and regularization signals with three value heads, and schedules their advantages during training. The full method reaches 94.1% simulation success with 4.4% tipover and transports unseen IKEA objects in 40/58 zero-shot hardware trials. Simone Tolomei, Mayank Mittal, Franco Angelini · 858 views · Aug 28, 2026Multi-Critic RLIsaac LabAug 28, 2026
 0:59