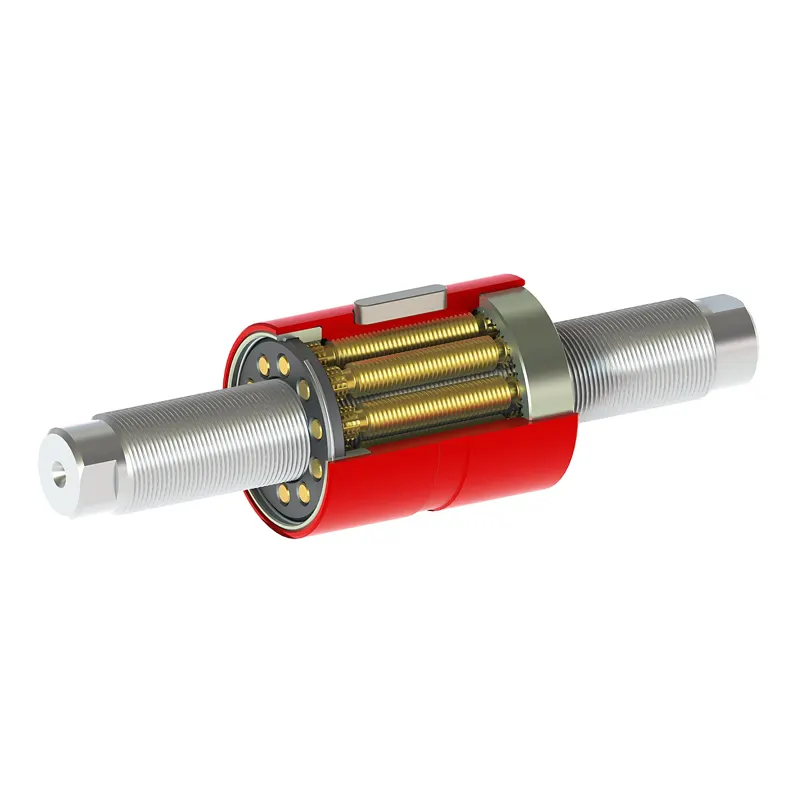
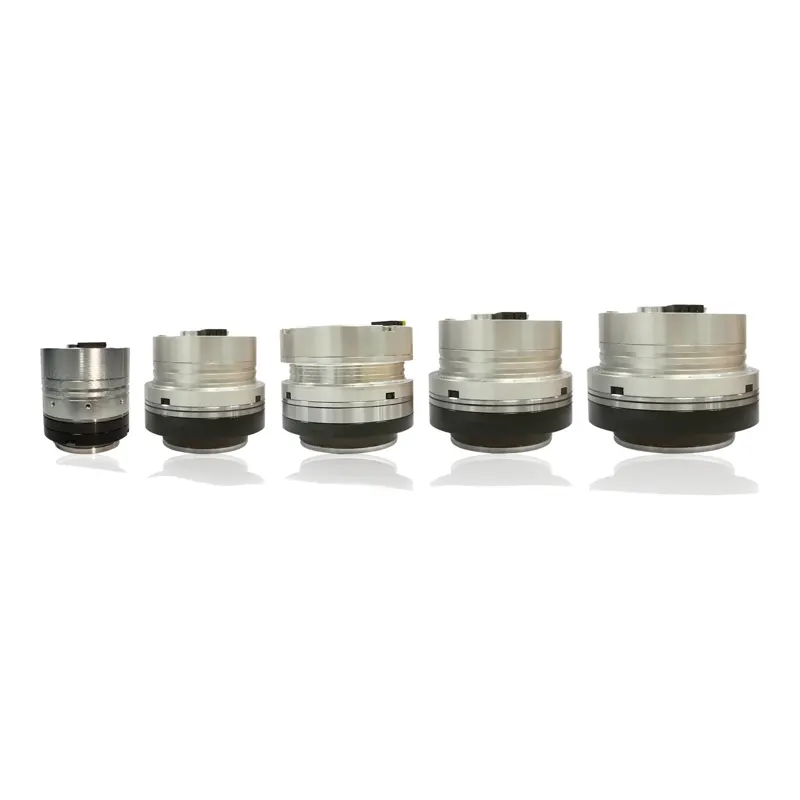
Swiss Rollvis (since 1970) focuses on planetary roller screws: 3.5-210 mm shaft diameters, 1.0-50 mm leads and 3.9-3800 kN dynamic load ratings; the HRV heavy-duty series starts at 60 mm shafts with even higher load density for electro-mechanical replacement of hydraulics. Internal synchronizing gears with precision-ground shaft, rollers and nut give up to 15x ball-screw life, >40 in/sec speed and 3G acceleration; ISO 9001:2015 and EN 9100:2018 certified for robotic joints, prosthetics, injection molding and aerospace.
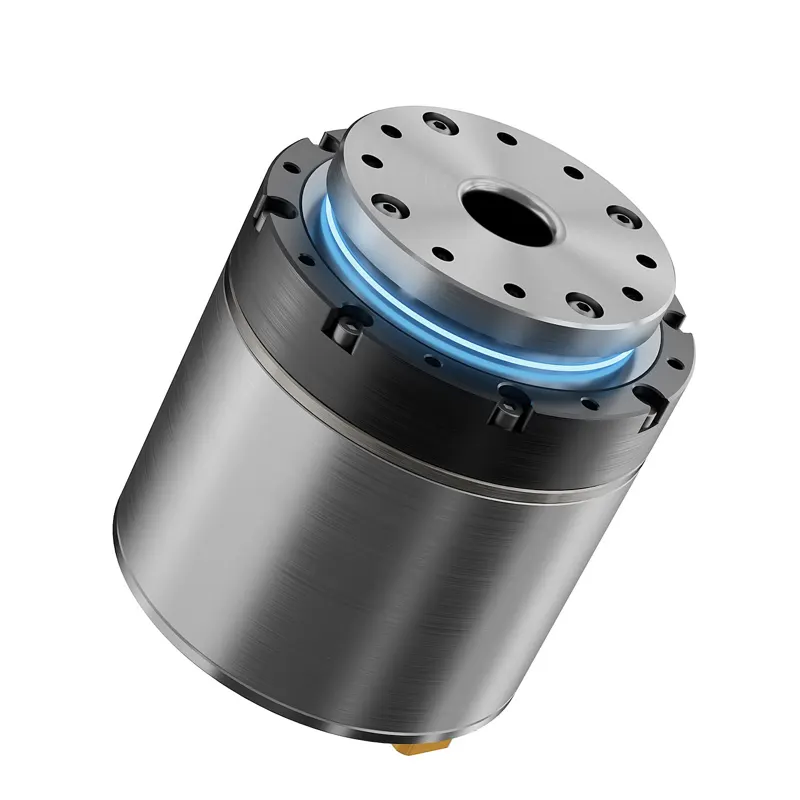
Laifual (03952.HK) DC low-voltage joint modules integrate a servo drive, frameless torque motor, dual absolute encoders (motor-side + output-side), precision harmonic reducer and safety brake in one unit; 48 VDC with CANopen / CAN FD / EtherCAT. Eight models L52I-L170I span 52-170 mm diameter and 0.55-9.48 kg, with 3.5-586 N·m rated and 11.5-1530 N·m peak torque at 51:1-161:1 ratios, targeting humanoid robots, cobots, medical devices and precision automation.
VMR (Hangzhou Lanxin Robotics) OmniHead is a head module built for embodied AI: three groups of ten RGB-D array cameras at the front and both rear sides form a 360°×90° panoramic field with 3 cm (1σ) accuracy, 0.1-18 m depth range and 20 Hz frame rate; a 2-DOF gimbal offers ±75° pan and ±45° tilt; a 6-mic ring array gives 5 m far-field pickup and 360° sound-source localization with DeepSeek/Qwen LLM integration for multi-turn dialogue; the 210×480×220 mm, 1200 g module ships a ROS2 SDK and adapts to humanoid platforms for office, manufacturing, smart-home and medical-care scenarios.
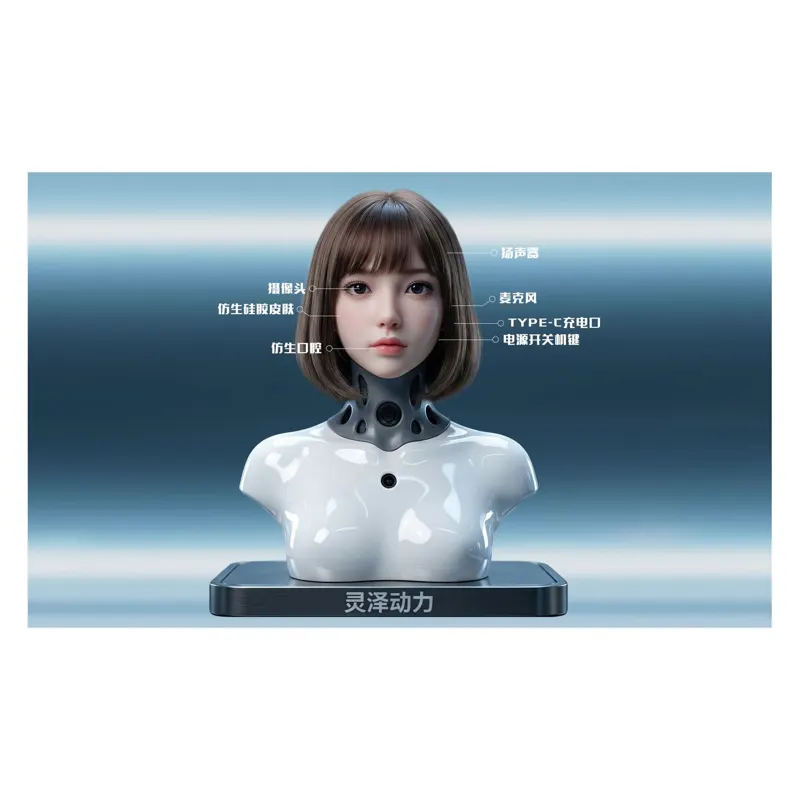
The Lingze Power Smart Bionic Head 3.0 is a 1:1 human-scale bionic head weighing 5.5 kg (head 3 kg + base 2.5 kg): a 6-DOF bionic neck reproduces natural cervical motion and a 5-joint facial system (eye up/down/left-right, lip open-close) delivers precise Chinese lip sync; a bionic e-skin array on cheeks, nose bridge and forehead gives real-time touch feedback; Horizon platform with 5 TOPS and 2G+32G on UBUNTU, 3000 mAh battery for 4 h runtime and ≤3 h charging, WIFI/Bluetooth, 0-50°C operating range, for reception, guiding, companionship and teaching scenarios.
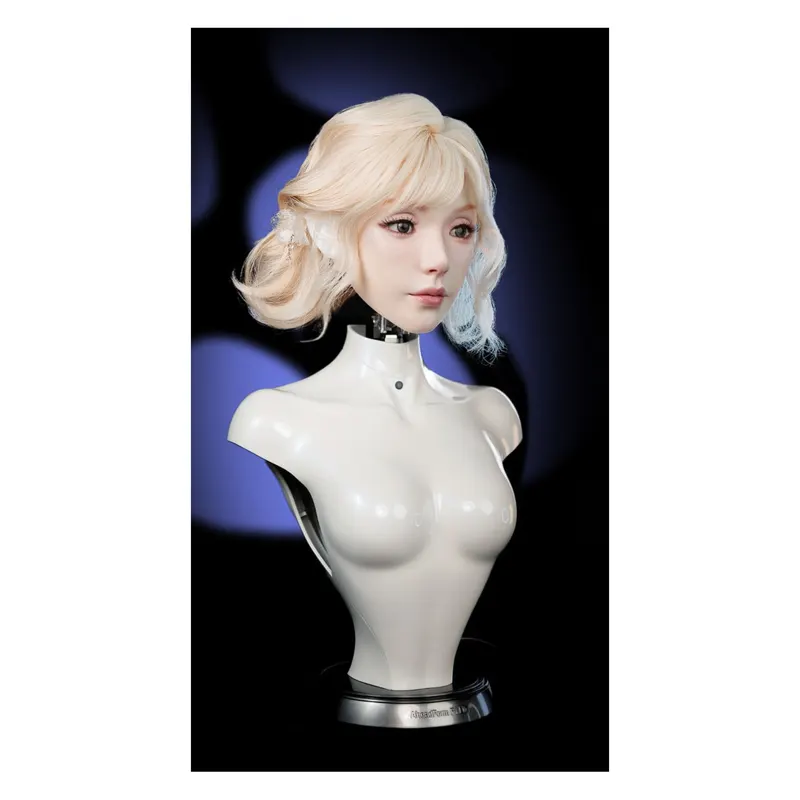
AheadForm Origin F1 is a desktop ultra-bionic humanoid robot for real human-interaction scenarios: 26 degrees of freedom across head, eyes and facial articulation, with 25+ micro brushless motors hidden under bionic silicone skin and a 10-DOF hinge-driven mouth for natural lip sync; high-resolution cameras embedded in the eyeballs enable active gaze tracking, and the in-house OmniAI multimodal model generates expressions, gaze and speech-driven behavior in real time with face recognition, ASR/TTS and natural dialogue; appearances can be replicated via 3D reconstruction and high-precision bionic skin for companionship, reception and education scenarios.
The HJ2 series from Shanghai Leadshine Robotics is a harmonic joint module family for humanoid robots with integrated motor, driver and encoder, a unified 101 reduction ratio and five frame sizes (52-110): 11-194 N·m start/stop peak torque and 8.9-133 N·m average load torque; the in-house FM2 frameless torque motor cuts heat by 25%, a 24-bit encoder and EtherCAT bus enable precise control, and the design is 65% lighter and 20% smaller for humanoid limbs, waist and neck joints.
The MJBX series from Techsoft Robots (Shenzhen Techsoft Intelligent Robot Co., Ltd.) is a force-controlled rotary joint module family for humanoid robots, integrating a harmonic reducer, optional 1-axis torque sensor, driver, dual encoders, motor and permanent-magnet brake; four frame sizes span 70/80/90/110 mm diameters at 0.84-2.3 kg, with 13.5-133 N·m average load torque, 376 N·m peak instantaneous torque, 80 rpm max speed and <60 arcsec repeatability; 48 V supply, 17-bit absolute encoder, EtherCAT/CANopen, IP40, 20,000 h reducer life, OEM/ODM available for rapid humanoid, bipedal and heavy bionic robot builds.
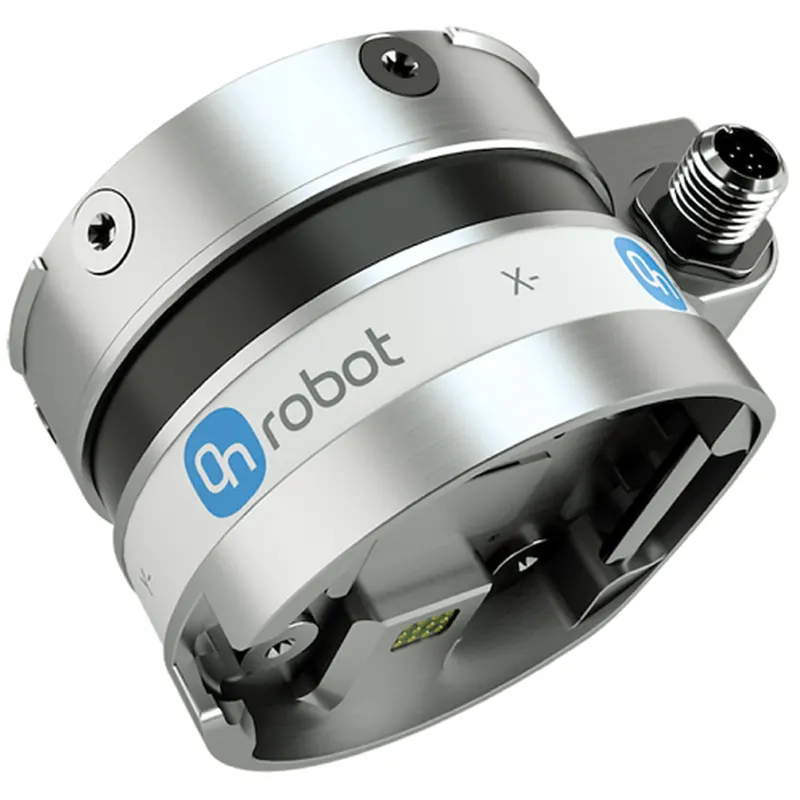
OnRobot HEX is an optical-technology 6-axis force/torque sensor for collaborative precision assembly, grinding and force-controlled gripping: HEX-E QC rates 200 N (Fxy/Fz), 10 N·m (Txy) / 6.5 N·m (Tz) with noise-free resolution of 0.2/0.8 N and 0.01/0.002 N·m and 500% overload protection; IP67 sealed, compact 50×71×93 mm / 0.347 kg body, 7-24 V supply, 0-55°C operating range and 30,000 h design life; higher-range HEX-H QC (Txy 20 / Tz 13 N·m) also available.
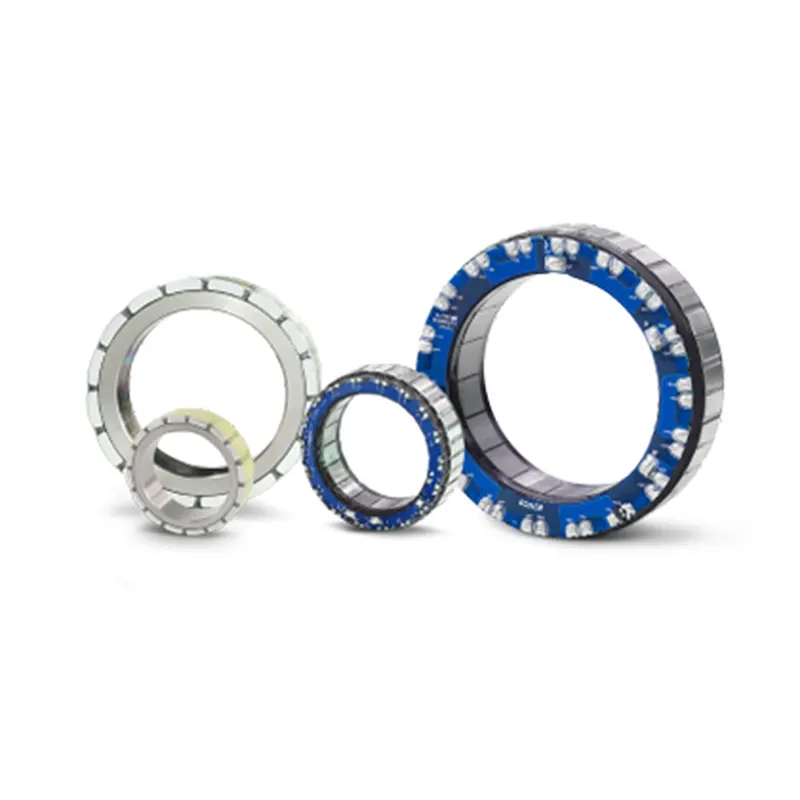
Kinco FMH frameless torque motors power humanoid rotary/linear joint modules: 38-120 mm outer diameters cover waist, shoulder, elbow, wrist, hip, knee and ankle joints; vacuum-potted stator for low temperature rise and segmented core with high-permeability silicon steel for high torque density; ultra-thin large-bore frame simplifies joint cabling; 48 VDC with 0.13/0.6/1.7 N·m rated torque (FMH03807/05014/08513), up to 4.26 N·m peak torque and 1500-3400 rpm rated speed.
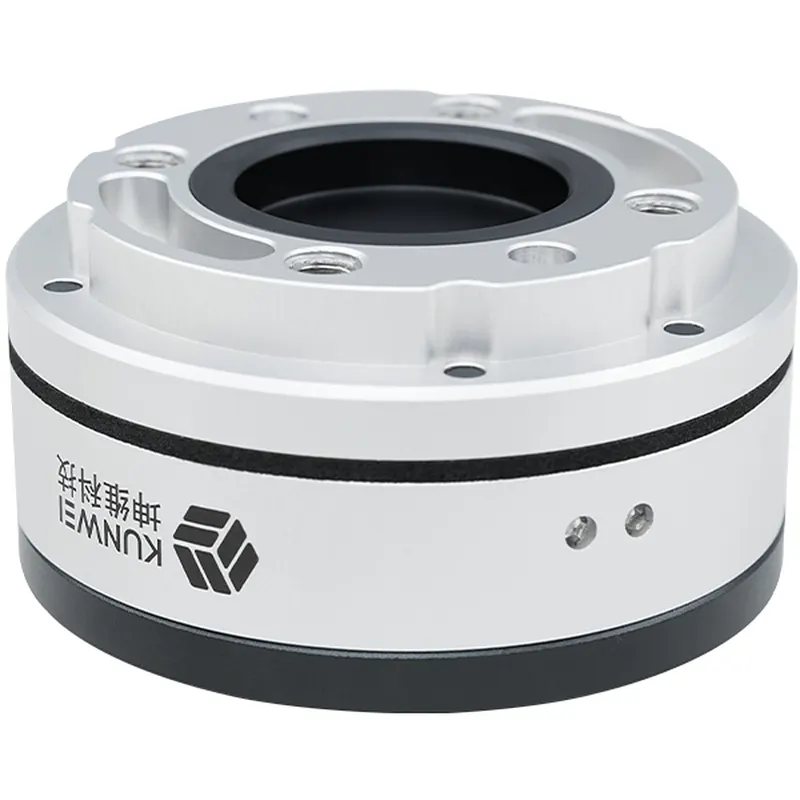
The Kunwei KWR75 series is a 75 mm-diameter general-purpose 6-axis force/torque sensor in aerospace-grade alloy with embedded high-precision smart electronics; eight range versions (Fz 30-3000 N, Mz 1.5-45 N·m) calibrated via six-axis combined calibration deliver 0.5%FS accuracy, 0.1%FS repeatability and 0.03%FS resolution, with 300%FS overload, IP64 protection and only 0.08-1.12 kg weight; full industrial-protocol support for robot joints, arm end-effectors and test rigs.
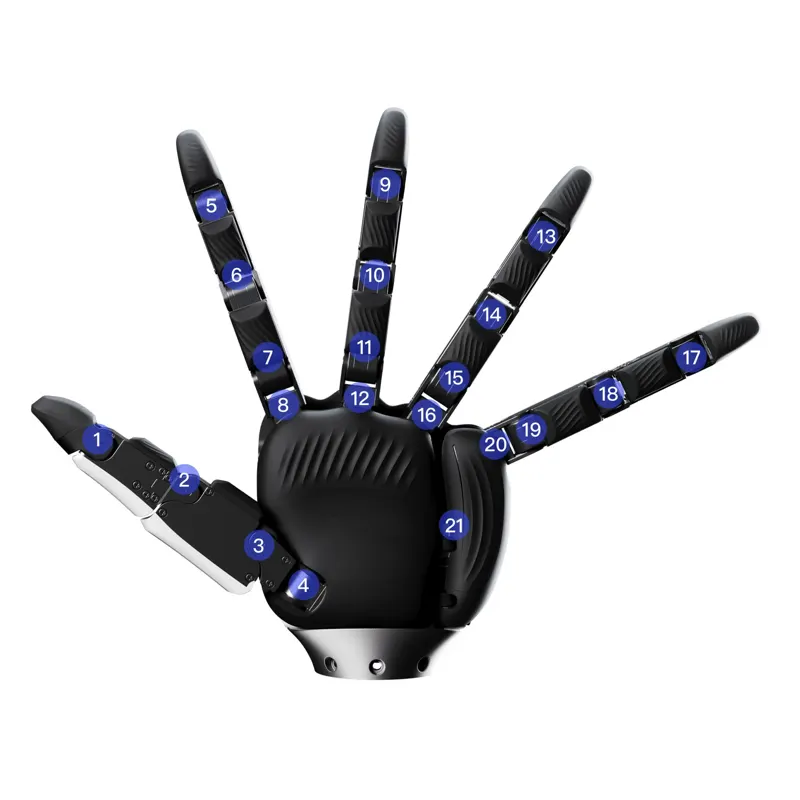
Flagship hand at 0.884 kg with 21 fully direct-driven and back-drivable active DoF, 160 mm maximum grasp diameter and 135° five-finger spread. 18 three-axis tactile sensors (5 fingertip, 10 finger-belly, 3 palm) cover 0.1-25 N at 0.01 N resolution with 10 mm proximity sensing; joint backlash under ±0.25 mm, ±0.1 mm repeatability, over 200k loaded cycles, above 5 Hz open-close and MIT, feedforward force, position and drag-teaching control modes.
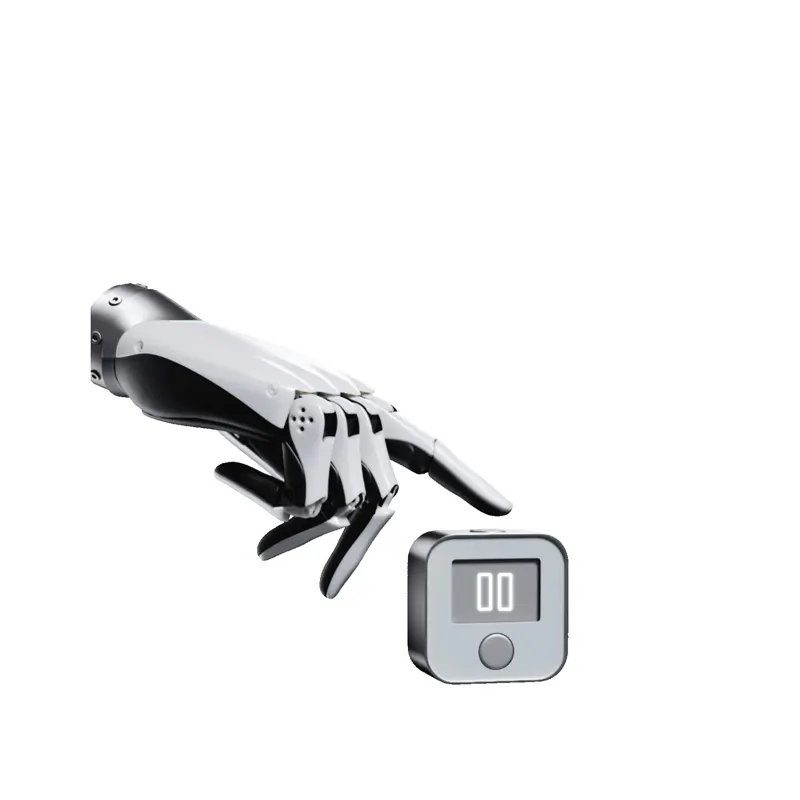
Lightweight variant at 730 g with 6 active plus 5 passive DoF and linkage transmission, 12 N fingertip load, 12 mm minimum grasp diameter, ±0.20 mm repeatability, ≤0.1 N·s/m back-drivable damping, one million no-load cycles and EtherCAT 100 Mbps / RS485 3 Mbps links, aimed at teleoperation and data collection.