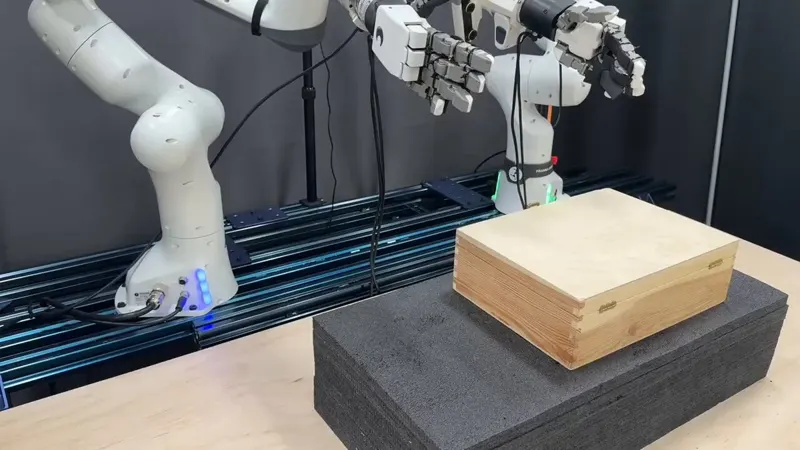
Splat-MOVER: A Robot That Updates Its 3D World After Every Move
Loading video
Loading videoThe Splat-MOVER stack from Stanford builds manipulation on editable Gaussian Splatting: ASK-Splat adds open-vocabulary semantics and grasp affordances to the scene, SEE-Splat updates that scene after objects move, and Grasp-Splat turns it into grasp candidates. The robot re-renders its 3D world after each action instead of reasoning from the original view.
3D Gaussian SplattingRobotic ManipulationGrasp GenerationScene EditingDigital twinsSplat-MOVERStanfordGaussian SplattingRobot Manipulation
Category: arm
Author: @Alacritic_Super
Date: 2026-09-20T00:00:00
Duration: 210.9s
Reference: https://arxiv.org/abs/2405.04378