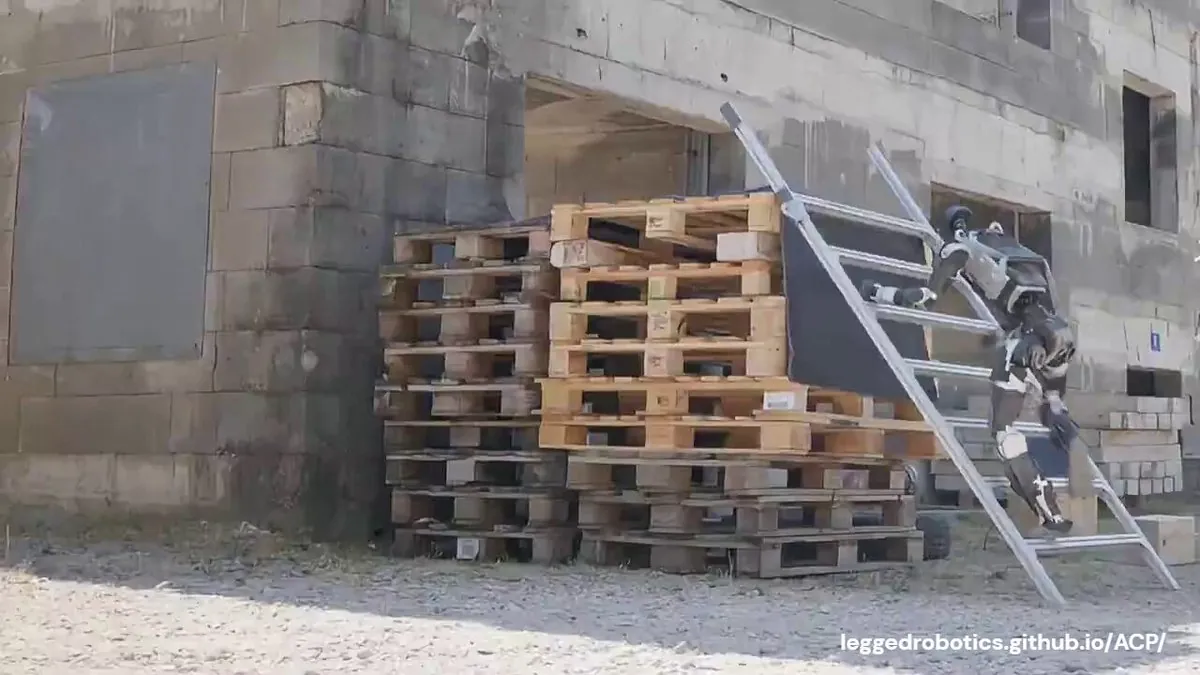
A Humanoid That Chooses Contact Points to Cross Terrain
Loading video
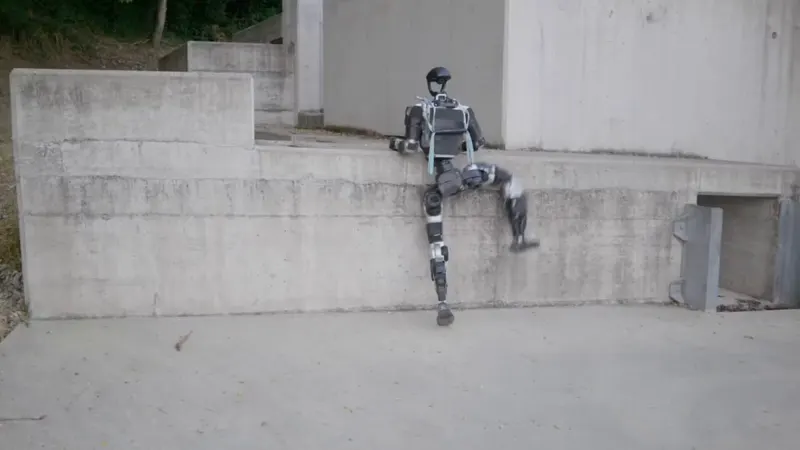
Loading videoUsing LiDAR terrain perception, this humanoid chooses hand, foot and knee contacts, then uses one control stack for climbing ladders, crawling and recovering after falls.
Category: humanoid
Author: @ZappyZappy7
Date: 2026-10-25T00:00:00
Duration: 72.733s
Reference: https://leggedrobotics.github.io/ACP/