Success-Guided Sampling: Mega-Scale RL for Contact-Rich Assembly
Loading video
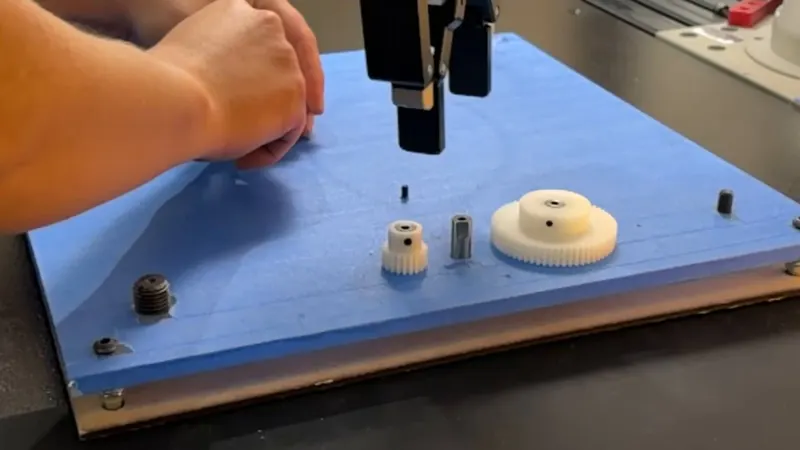
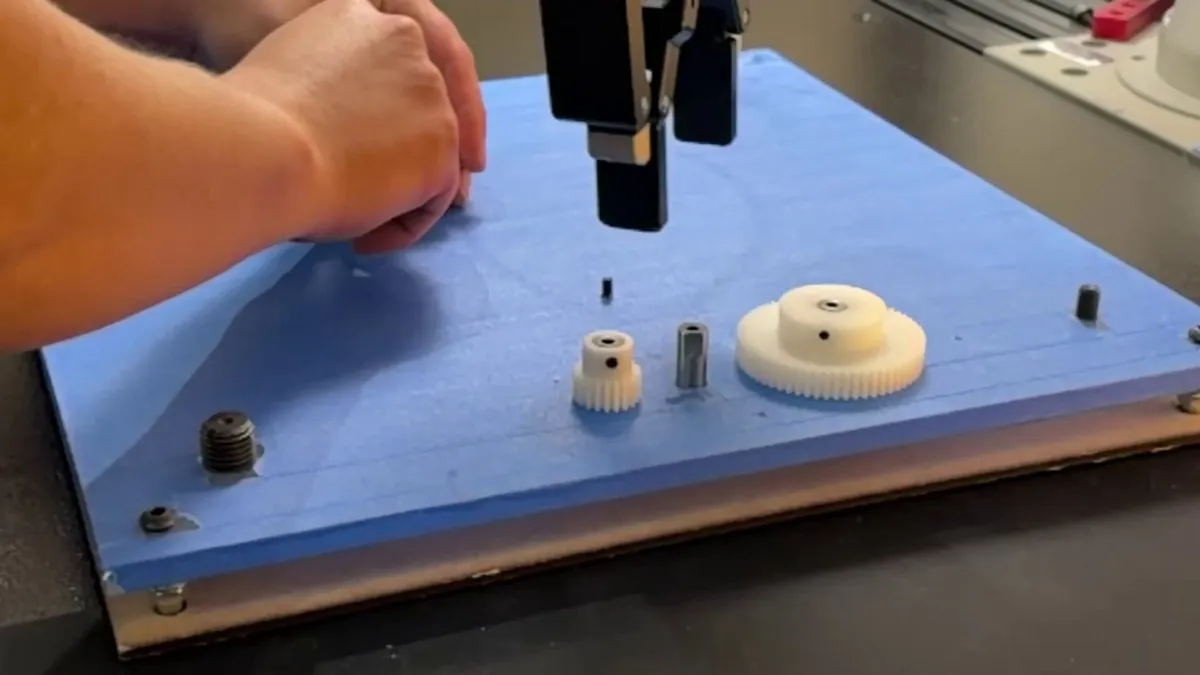
Loading videoSuccess-Guided Sampling picks task configurations near the frontier of what the policy can already do, so massively parallel simulation stops wasting experience on setups it has mastered or cannot attempt yet. Across runs with over one million parallel environments it solves multi-terrain quadruped locomotion and contact-rich assembly that prior pipelines fail, then distills the manipulation policies into RGB-based ones that transfer zero-shot to real hardware.
Success-Guided SamplingSGS-RLReinforcement LearningContact-Rich ManipulationSim-to-RealMassively Parallel SimulationQuadruped LocomotionSimulation to Real Machine
Category: manipulation
Author: @ctorobotics
Date: 2026-10-11T00:00:00
Duration: 7.221s
Reference: https://arxiv.org/abs/2610.12465