ROBOTIS Mission Canvas: Composing Reusable Robot Skills into Repeatable Mobile Missions
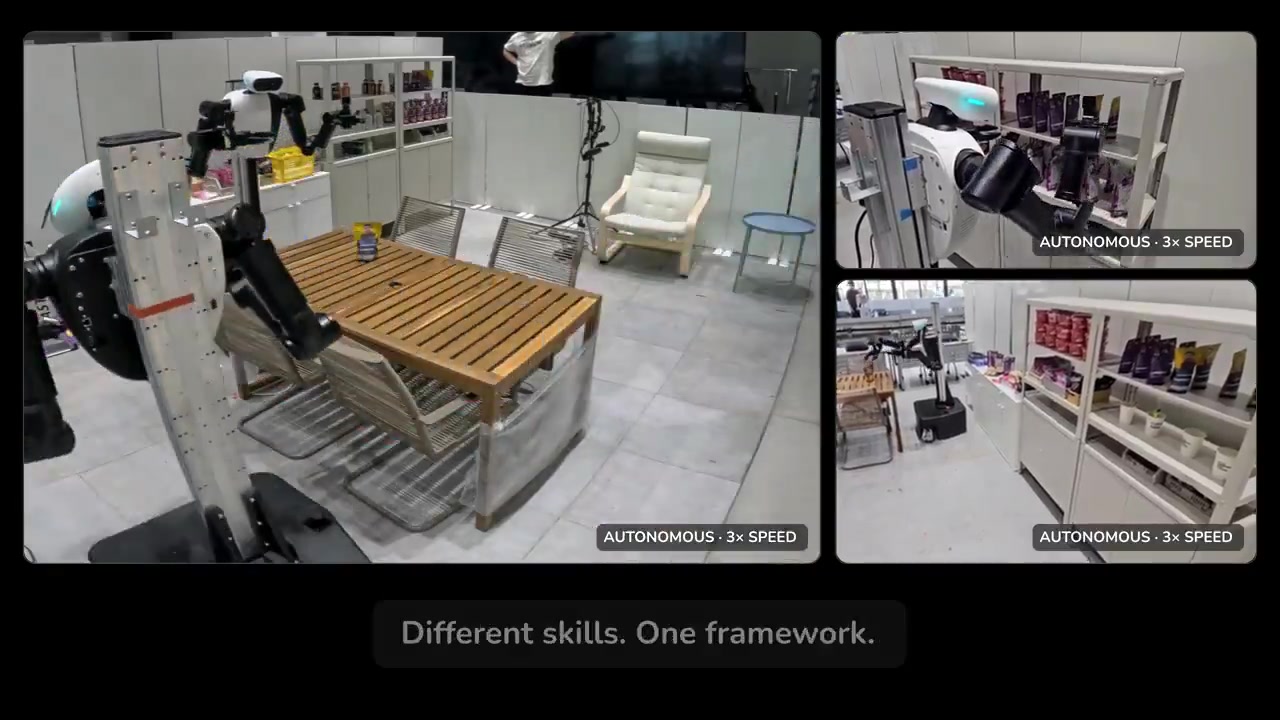
ROBOTIS released Mission Canvas, the mobile workspace of Autonomy Studio: define waypoints on a map, specify their order, and bind a Task to each location so navigation and robot actions execute as one Mission. The relationship to the earlier Action Canvas video is direct — Action Canvas defines what the robot does within a work area (VLA whole-body control, stationary manipulation); Mission Canvas extends that to where the robot should go and what to do there. Tasks can be deterministic robot actions or AI/VLA-based behaviors, so reusable robot skills compose into repeatable workflows across multiple real-world locations. Together the two videos show the progression from building individual tasks to deploying them as a mobile, repeatable Mission. Fully open source (Apache 2.0, cyclo_intelligence, 33 stars) with code, tutorial videos and technical docs for reproduction and extension. Docs note current support is limited to the ffw_sg2_rev1 robot type; Autonomy Studio combines autonomous navigation, Behavior Trees and VLA models in one visual tool — validate in simulation, then deploy to a physical AI Worker.