AMB3R-SLAM: kilometer-scale real-time SLAM on a single consumer GPU, no bundle adjustment needed
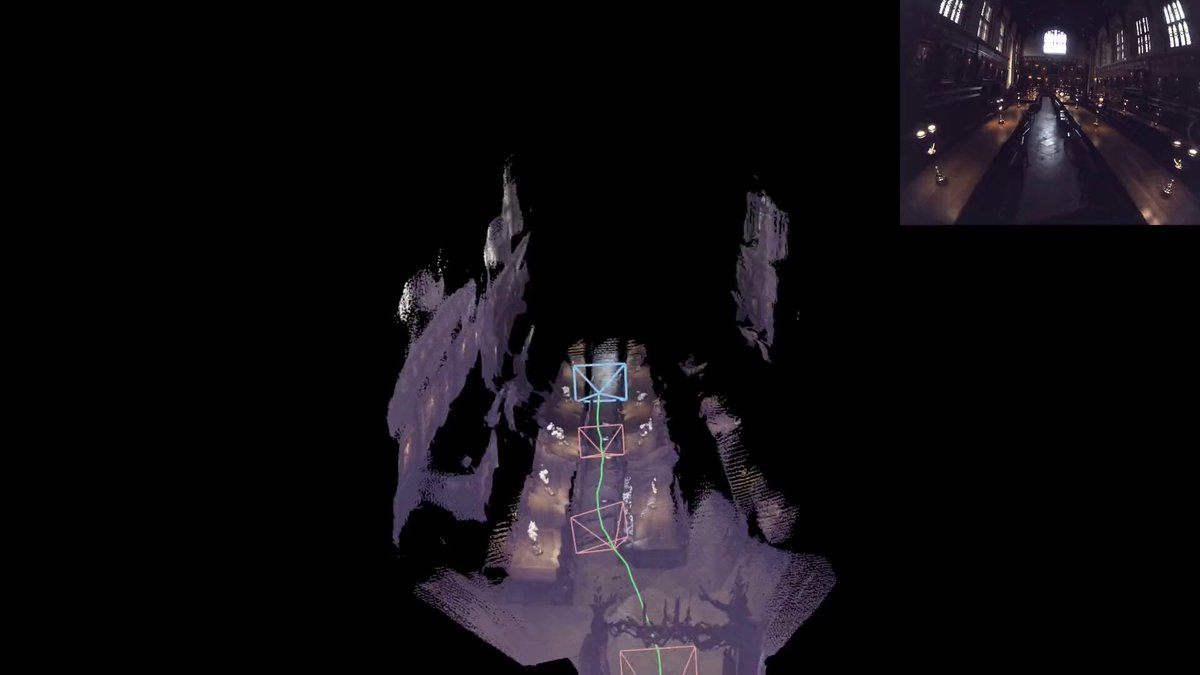
AMB3R-SLAM (arXiv:2609.19518) by Hengyi Wang and Lourdes Agapito at UCL: a training-free, model-agnostic real-time monocular SLAM that reconstructs kilometer-scale trajectories over 10k frames on a single consumer GPU. A hierarchical backend (span-2, long-context, and loop-closure pose-graph edges) progressively enforces local, mid-level, and global consistency while avoiding bundle adjustment and its static-world assumption, so dynamic scenes work out of the box; the same framework extends to stereo, RGB-D, and LiDAR inputs. Across 9 datasets it cuts ATE of prior state of the art by over 70% on VBR and Oxford Spires, and reaches sub-meter ATE on KITTI and VBR with LiDAR input. Shared by Ryohei Sasaki, localization & mapping engineer at MAP IV (TIER IV group).