SERF: Spatial Memory for Long-Horizon Mobile Manipulation
Loading video
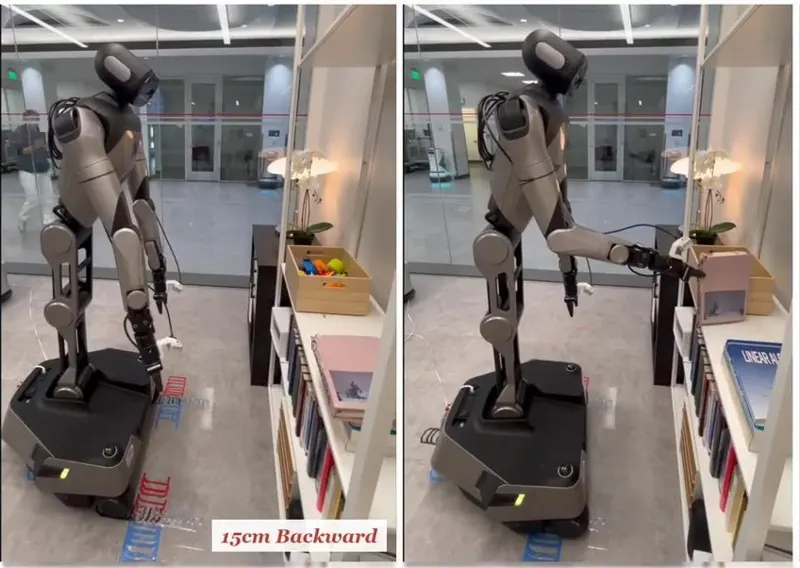
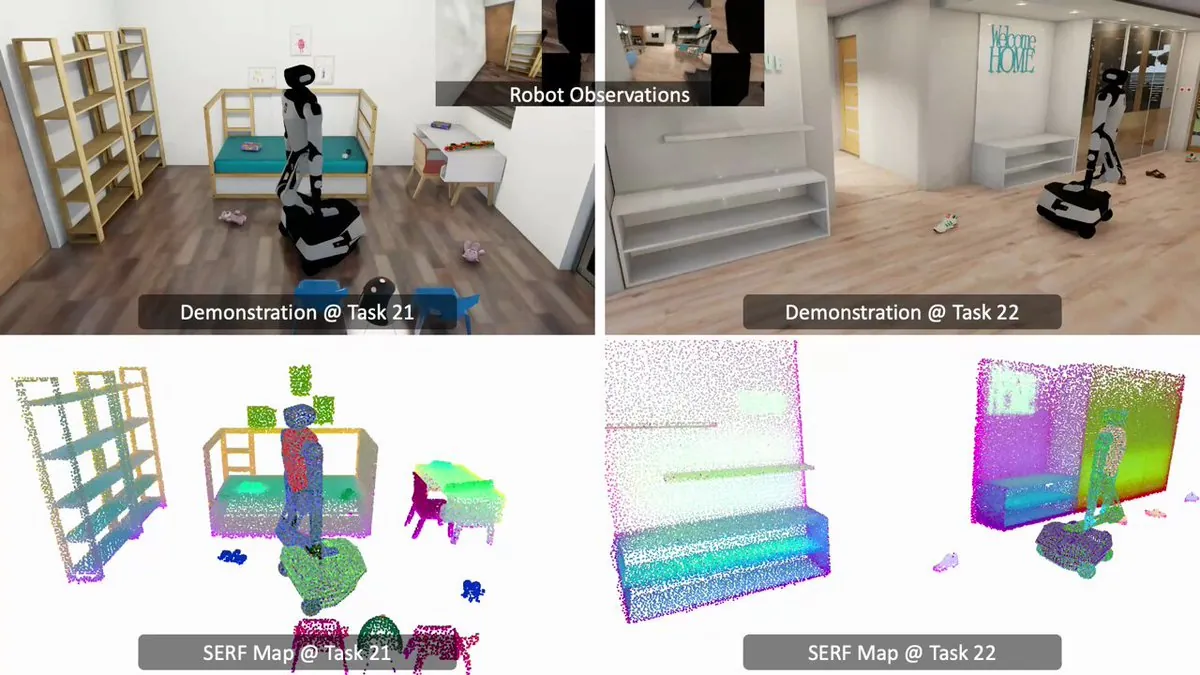
Loading videoSERF conditions a VLA policy on an online-updated latent map of the environment and robot body, improving long-horizon mobile manipulation.
Category: humanoid
Author: @sssssshwan
Date: 2026-06-24T00:00:00
Duration: 16.038s
Reference: https://arxiv.org/abs/2606.12956