A wheeled humanoid waters flowers: agentic planning meets RL control
Loading video
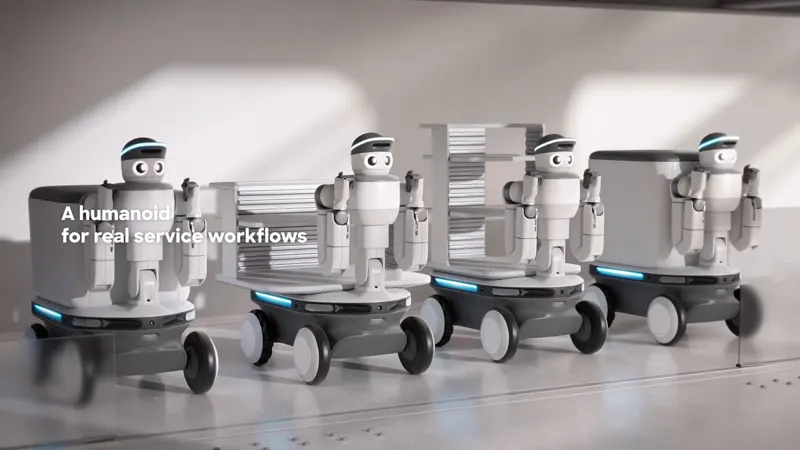
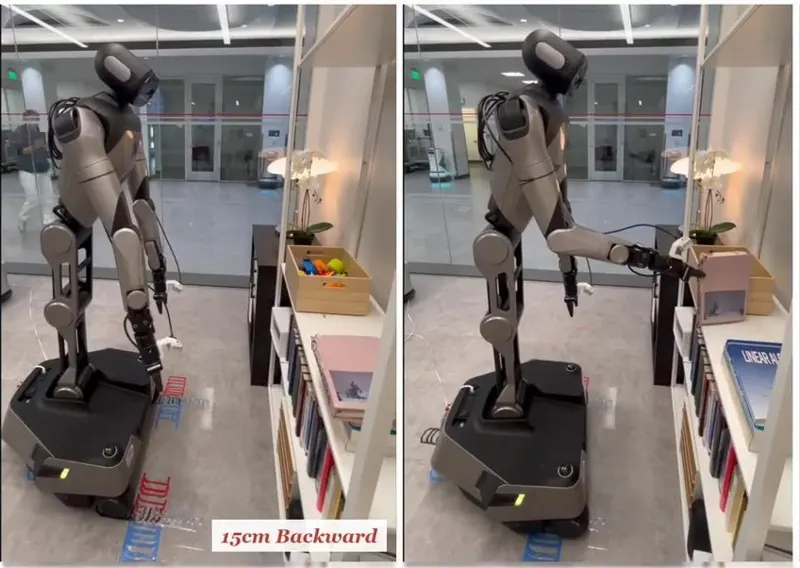
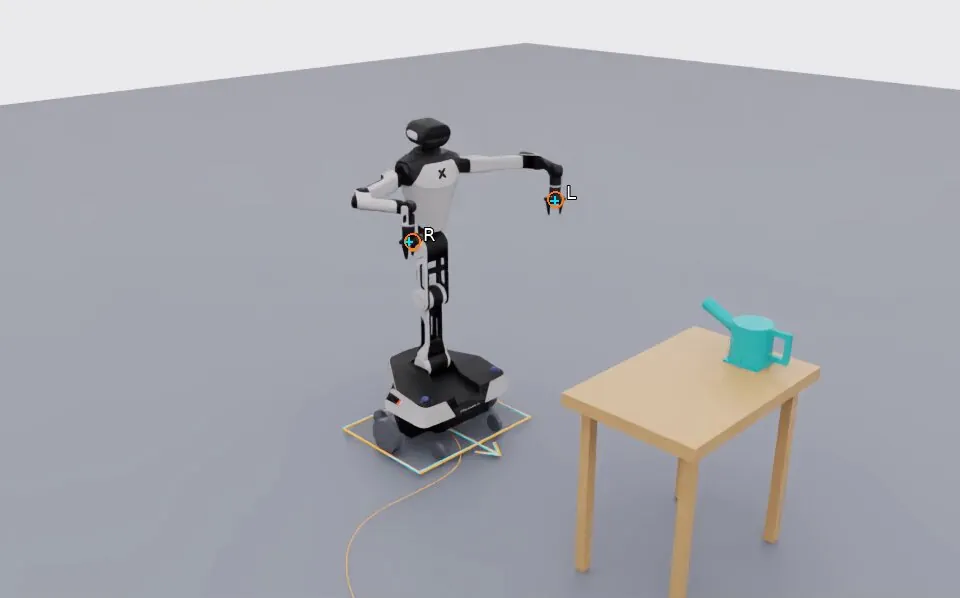
Loading videoA simulation demo where an agent plans trajectories for a wheeled humanoid: walk to the table, pick up the kettle, then pour water on the flower bed. Dyna2-style RL runs the low-level control with precision and robustness to disturbances, going beyond motion planning alone.
Category: humanoid
Author: @MPriosin71748
Date: 2026-10-17T00:00:00
Duration: 51.77s