Nav Arena "Can Jev Nav?": 133 environments and 2,000+ tasks benchmark System-1 language models driving robots; a WorldState rewrite lifts Jev from 40% to 90%
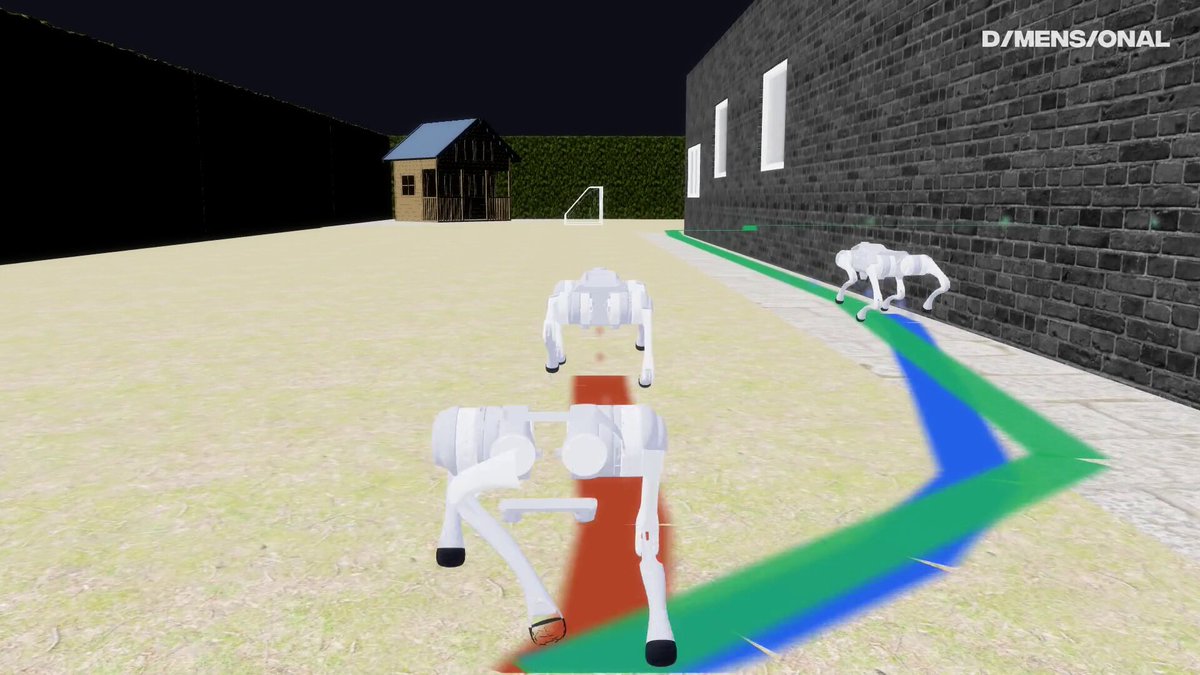
Dimensional Research (Stash Pomichter, Ruthwik Dasyam, Henry Ventura) launches Nav Arena "Can Jev Nav?": 133 HSSD/Habitat home environments (doors removed for full reachability), 327 navigation tasks, 6 model+harness combos, 1,962 recorded runs — fully open source via the dimOS framework. Key findings: (1) System-1 language models like Jev can drive a 2-5 Hz control loop — rewriting WorldState from world-frame numbers to robot-frame strings with natural-language tokens (ahead_left/near/blocked/tight/clear etc.) jumps task completion from 40% to 90%; (2) Dimensional's own dimcode with navigation skills leads at 0.743 SPL / 88.4% arrival, Astra second at 0.522, Jev scores 0.263 overall but reaches 71.1% on short routes (<10 m) — near Fable 5.1 — at the lowest cost ($0.081/run) and fastest median time (51 s vs Astra's 132 s); (3) real-robot multi-room navigation is the bottleneck, blamed on clean wall/doorway labeling rather than Jev itself.