GaussLite: Online Task-Conditioned 3D Gaussian Splatting for Real-Time Robotic Mapping
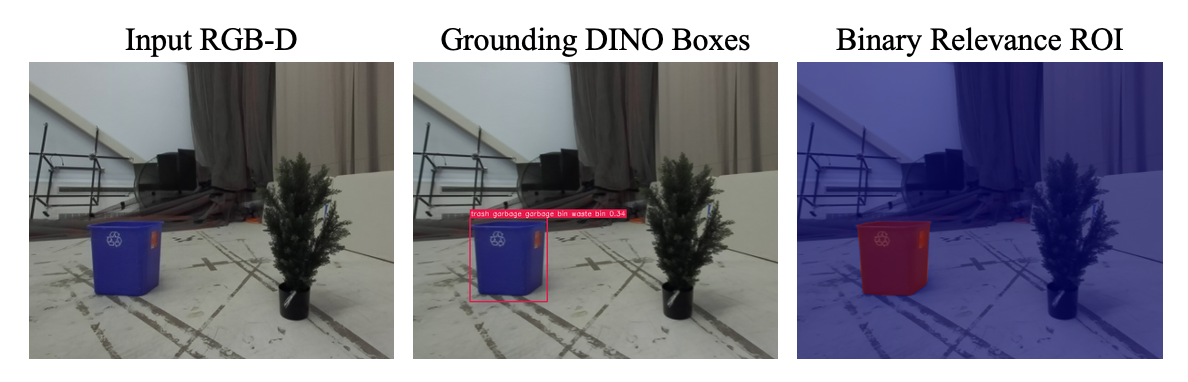
MIT presents GaussLite, the first 3DGS mapping system that takes a natural-language task and allocates representation capacity online by task relevance: a one-shot LLM parser extracts target and anchor objects, Grounding DINO + FastSAM ground them per frame into relevance masks that steer seeding density, gradient flow and initial scale. At matched Gaussian budget and real-time 4 Hz mapping, ROI PSNR improves by +2.72 dB on Replica and +2.23 dB on real campus scenes; multi-agent maps fuse via per-voxel voting on active-optimization counts, beating concatenation by +3.42 dB while sharing only 7.08% of the map.
Thomas, Annika, Peterson, Mason, How, Jonathan P.Jun 29, 2026
3D Gaussian SplattingSLAMRobotic MappingJun 29, 2026