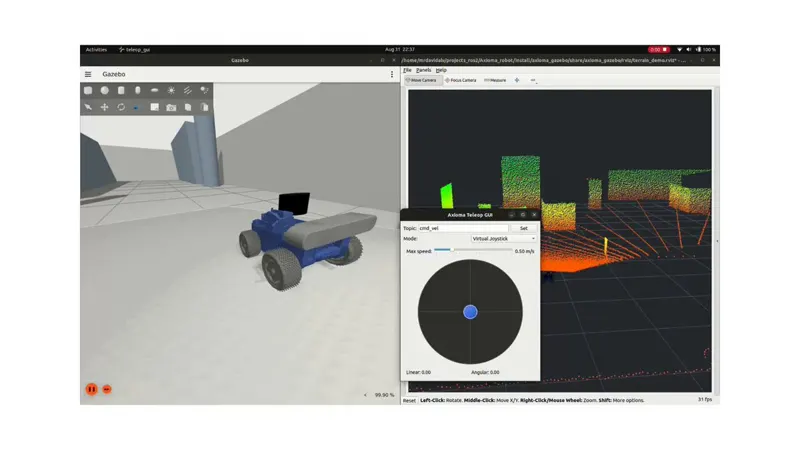
0:47Axioma: Open-Source ROS 2 Robot for Mapping and Autonomous Navigation@Alacritic_Super · 1.4k views · 2026-09-03ROS2SLAM
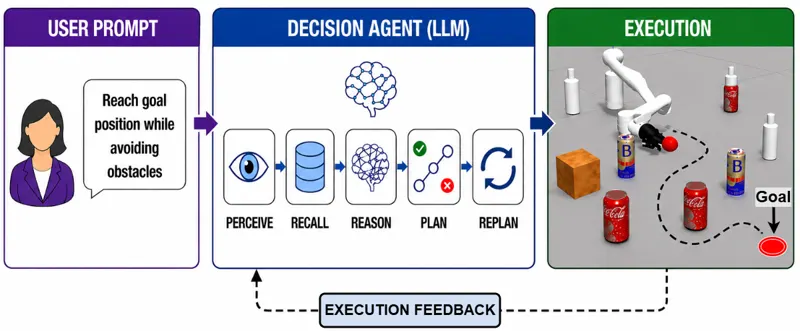
RoboNav-Arm: Agentic AI-Driven Navigation and Obstacle Avoidance for Robotic Manipulators in Cluttered EnvironmentsRoboNav-Arm lets an LLM decision agent orchestrate scene understanding, contextual memory and trajectory planning modules, adaptively selecting RRT-family planners with safety-inflated collision validation; collision-free success rates range from 100% to 83.3% across four clutter scenarios.Aachal Sharma, Narendra Kumar Dhar · 567 views · Jun 25, 2026Robotic ArmObstacle AvoidanceJun 25, 2026
 0:47