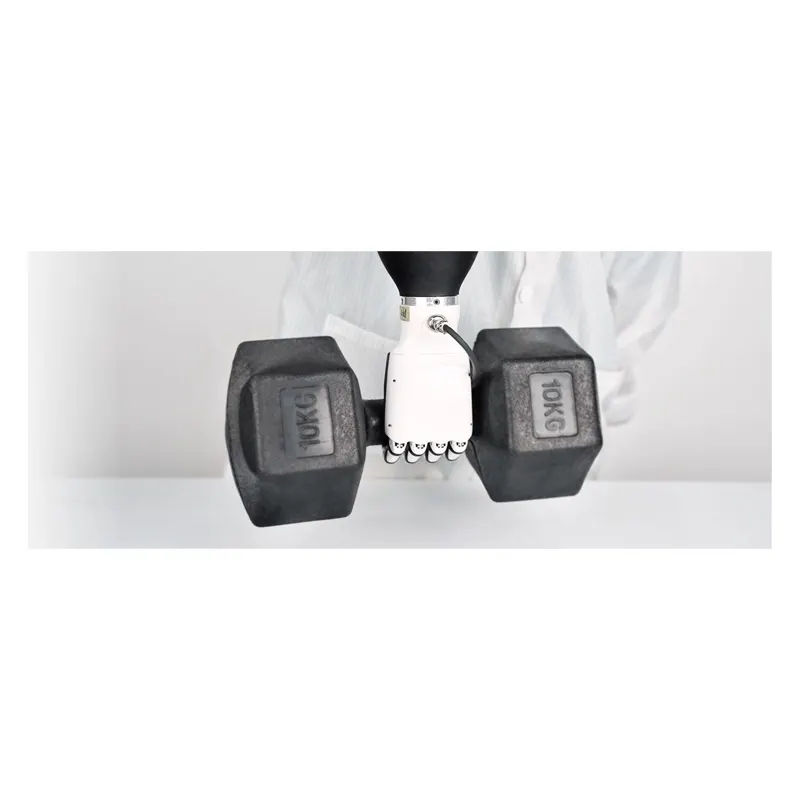
Inspire Robots RH56DFX series humanoid five-finger dexterous hand, offered in wrist-less (RH56DFX-2L/2R) and wrist-equipped (RH56DFXW-2L/2R) variants with 6 DoF (6+2 with wrist), 12 finger joints and an RS485 control interface. Human-hand sized at only 540 g / 650 g. Up to 1.5 kg single-finger active force, 15 N max thumb grip, 10 N max four-finger grip with 0.5 N grip-force resolution, and ±0.20 mm repeatability. Thumb lateral rotation >65°, thumb lateral speed 107°/s, thumb flexion 70°/s, four-finger flexion 260°/s; wrist models add ±27° lateral and ±22° pitch with 2 N·m torque (excluding hand weight). Runs on DC24V±10% with 0.09 A / 0.1 A quiescent and 2 A max current — a compact end-effector for humanoid robots.
COMPONENT