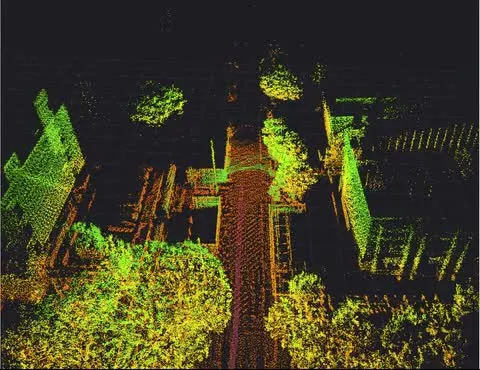
glass-LIO is an open-source scan-to-map LiDAR-inertial odometry for the Livox MID-360, described by its author as “written to be read”: each of its six pipeline stages has a deep-dive write-up, the manifold Gauss-Newton solver is under 200 lines of Eigen with no Ceres/GTSAM, and every bug that produces plausible output is documented — including the full failure post-mortem of tight coupling diverging on real data. It runs real time at 10 Hz on the test bag with zero dropped scans and steady RMSE around 0.13 m.
BLOG