SSTG-Nav: Metric-Grounded Spatial-Semantic Topological Graphs for Reusable Object Navigation
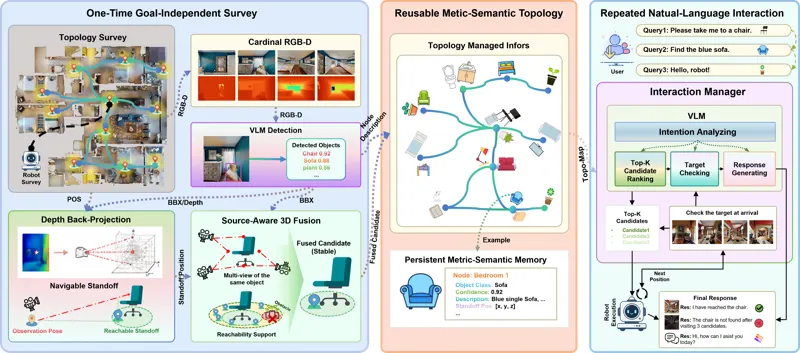
Service robots that live for months in the same homes and facilities should get more reliable with experience instead of re-exploring familiar space for every request. SSTG-Nav turns a one-time, goal-independent survey into a persistent metric-semantic topology: farthest-point sampling builds the graph (6,642 nodes / 21,845 edges, 0.8 m cover radius), view-local VLM detections are depth-back-projected into reachable 0.8 m standoff stopping poses, and source-aware noisy-OR fusion consolidates evidence across viewpoints while retaining residual standoffs for recovery. On 1,000 HM3D-v2 episodes the goal-independent topology reaches a 99.4% geometric success ceiling; holding semantic responses fixed, metric grounding raises SR/SPL from 0.835/0.560 to 0.920/0.603, fusion reaches 0.926/0.586, and fusion-aware Top-3 recovery reaches 0.975/0.601, with a ROS 2/Nav2 realization closing the query-to-execution loop on a physical robot.