StereoPolicy: Improving Robotic Manipulation Policies via Stereo Perception
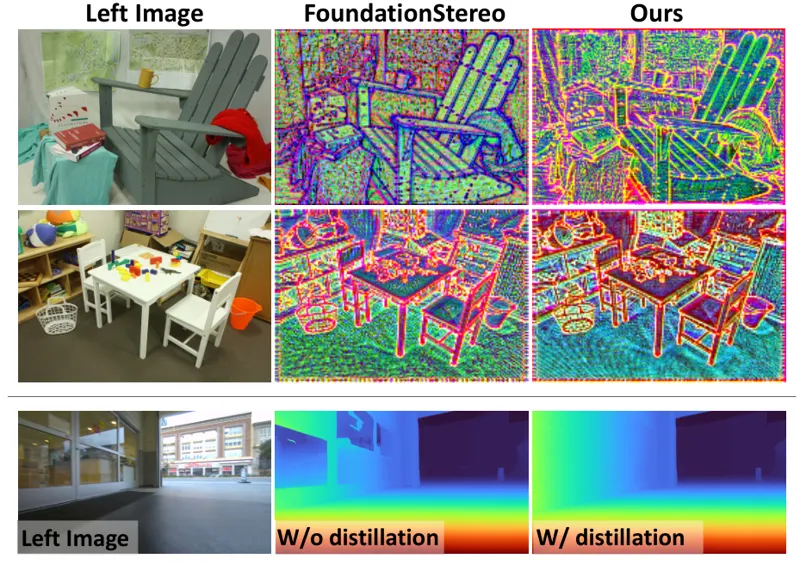
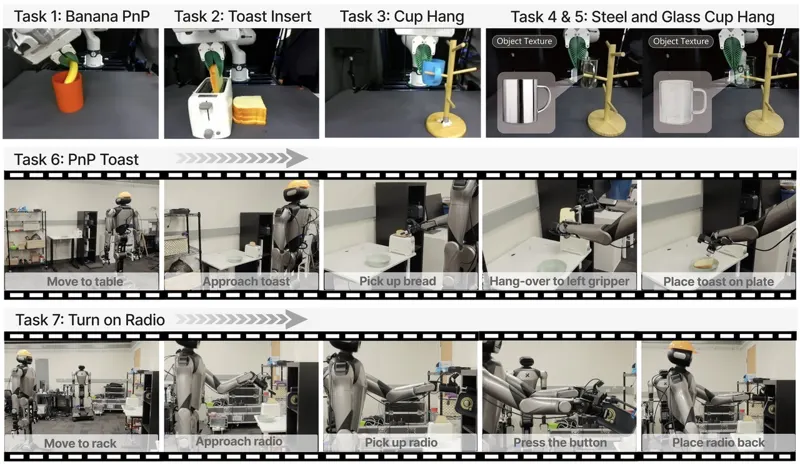
StereoPolicy learns task-conditioned binocular representations directly from synchronized stereo pairs instead of reconstructing explicit depth or point clouds. A Stereo Transformer alternates within-image and cross-image attention over shared 2D features, and the fused representation integrates with diffusion policies, pi0.5, and GR00T-N1.5. Experiments across simulation and real tabletop and bimanual mobile manipulation show consistent gains over RGB, RGB-D, point-cloud, and multi-view baselines, together with practical guidance on stereo baseline and working distance.
Evans Han, Yunfan Jiang, Yingke Wang · 50 views · May 11, 2026
Stereo visionRobot Manipulation
May 11, 2026