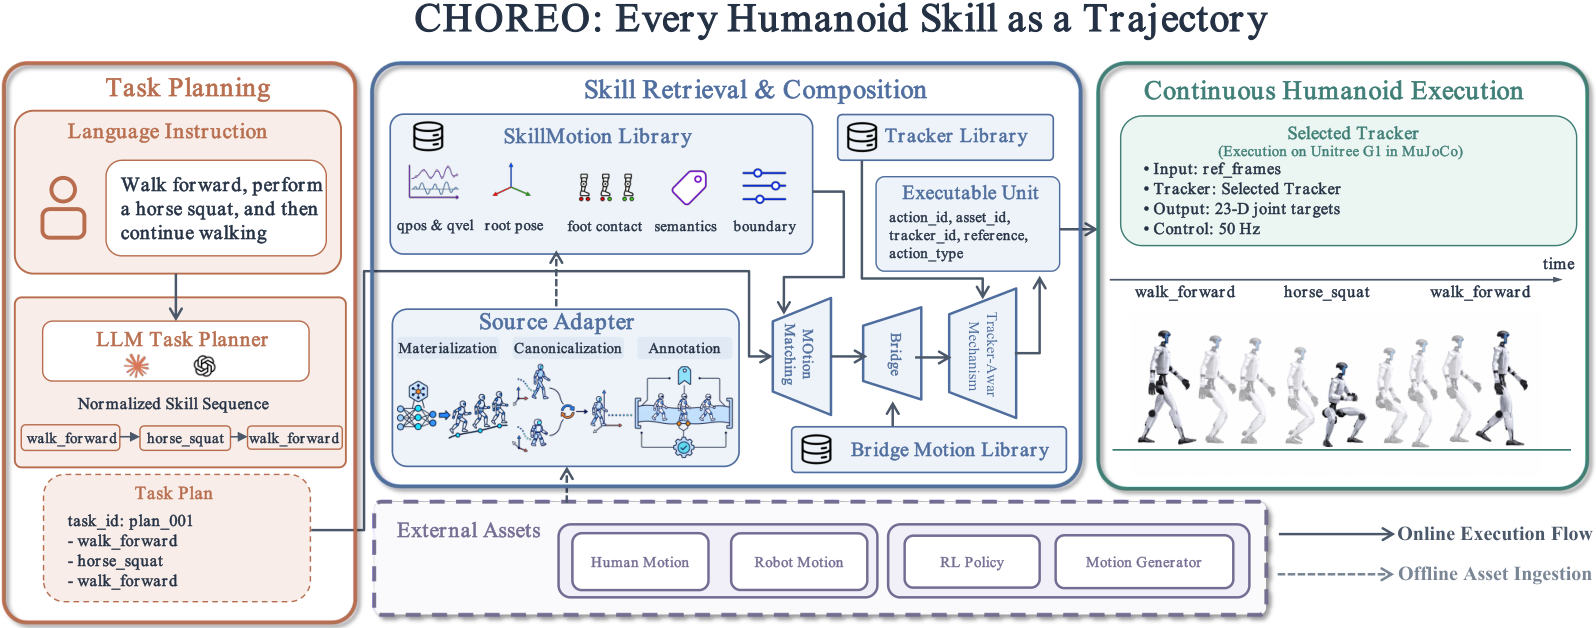
CHOREO: Every Humanoid Skill as a Trajectory — training-free composition of 2,950 heterogeneous skills, 93.8% on 8-action long-horizon sequences on Unitree G1
CHOREO (Ocean University of China & CASIA) unifies outputs of RL policies, mocap data and generative models into SkillMotion trajectory assets, then composes long-horizon skills training-free via LLM planning, boundary-mismatch scoring, quintic polynomial seams and a standing bridge: 96.7% success over 552 skill boundaries, 4.6% fall rate (best baseline 41.5%), and 93.8% on 8-action sequences vs 41.7% for the strongest baseline; plus compatibility with 6 trackers and 100% ingestion of 3,069 heterogeneous instances. All experiments in simulation; real-robot deployment is left open.
Ziyi Sun, Jingwen Chen, Yuxi WangSep 11, 2026
HumanoidEmbodied AIMotion PlanningSep 11, 2026