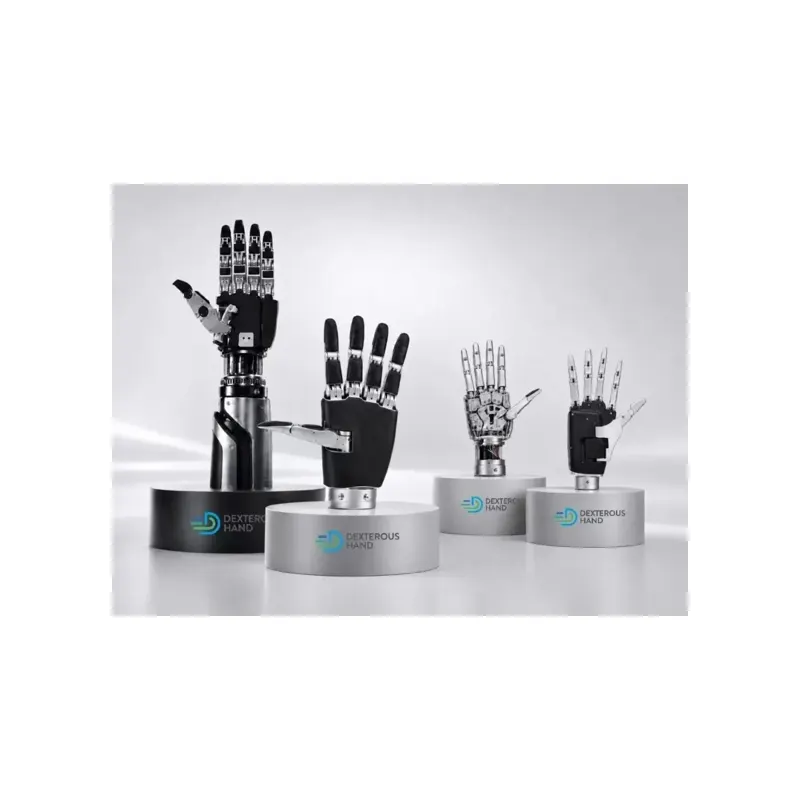
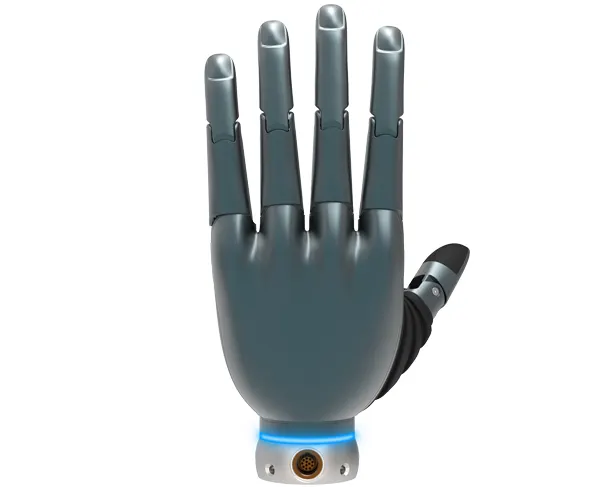
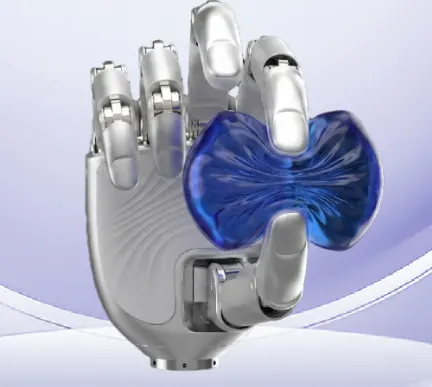
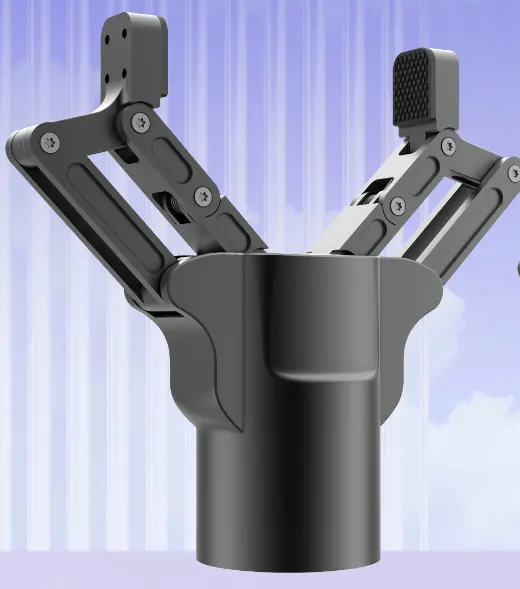
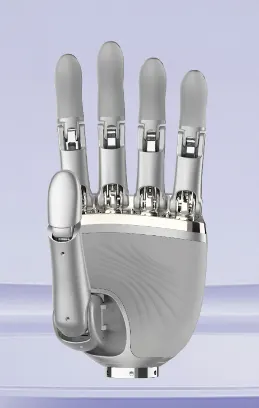
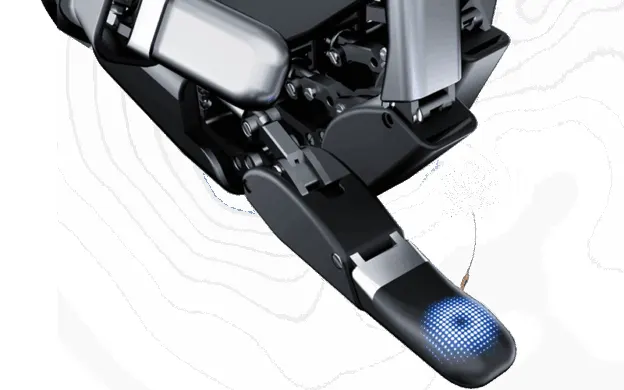
The LZ-Pro V2 is an industrial multi-finger dexterous hand from Wuxi Lingzhang Robotics, built for precision industrial assembly, complex object grasping and research. Its five-finger bionic design provides 11 degrees of freedom (6 active + 5 passive) driven by tendon actuation for efficient power transmission in a compact palm; 13 high-resolution pressure sensors deliver real-time per-finger force feedback, with up to 50 N pinch force, ±0.1 mm repeatability and a 5 kg payload. Machined from 6061-T6 aluminum and TC4 titanium, it runs on 48 V (max 60 V), communicates over RS485 / EtherCAT / CANOpen plus standard Modbus RTU for easy PLC integration, and ships with a C SDK plus full ROS/ROS2 drivers, URDF models and simulation environments. Founded in 2024 and incubated by the Wuxi Industrial Technology Research Institute, Lingzhang targets real industrial duty cycles rather than demo routes, covering 90%+ of industrial scenarios from precision assembly to hazardous handling and flexible grasping; in August 2026 it closed a tens-of-millions-RMB angel round backed by Kailong High Technology, AUBO Intelligent, the Wuxi Future Angel Fund and Renzheng Fund to scale multi-scenario product iteration and commercial delivery.
RS485 dexterous hand with 11 degrees of freedom A five-finger robotic hand driven by brushless coreless motors and worm gearing. This RS485 variant has 11 degrees of freedom, including 6 active degrees of freedom.
Six-degree-of-freedom modular hand with 175 N grasping force RY-H5 is a six-degree-of-freedom, 15-joint dexterous hand designed for high gripping force and reliable industrial operation. Its coreless brushless motors, ball-screw transmission and modular finger structure combine stiffness, precision and fast response.
Sixteen-degree-of-freedom bionic hand with optional tactile sensing RY-H1 is a highly bionic dexterous hand with 16 degrees of freedom and 21 motion joints. Sixteen high-speed precision coreless brushless motors and a proprietary force-position control algorithm enable adaptive grasping and detailed human-like gestures; a tactile version is also available.
Compact six-degree-of-freedom hand with standard and high-speed configurations RY-H2 is a compact dexterous hand with six degrees of freedom and 11 motion joints. Six high-speed, high-power-density coreless brushless motors provide rapid response, while standard and high-speed configurations address heavy-duty grasping and fast manipulation needs.
Long-stroke parallel gripper for stable high-load handling RY-G1 is a long-stroke force-controlled electric gripper family for stable handling of objects with different sizes and loads. Three configurations combine wide opening travel, precise repeatability and screw-driven transmission for industrial robot applications.
278 g compact hand for confined-space and small-robot manipulation RY-H6 is a compact and lightweight dexterous hand for small humanoid robots, confined spaces and light-duty mechanisms. A coreless brushless motor architecture combines compliant transmission, force sensing and precise force control in a 278 g package.
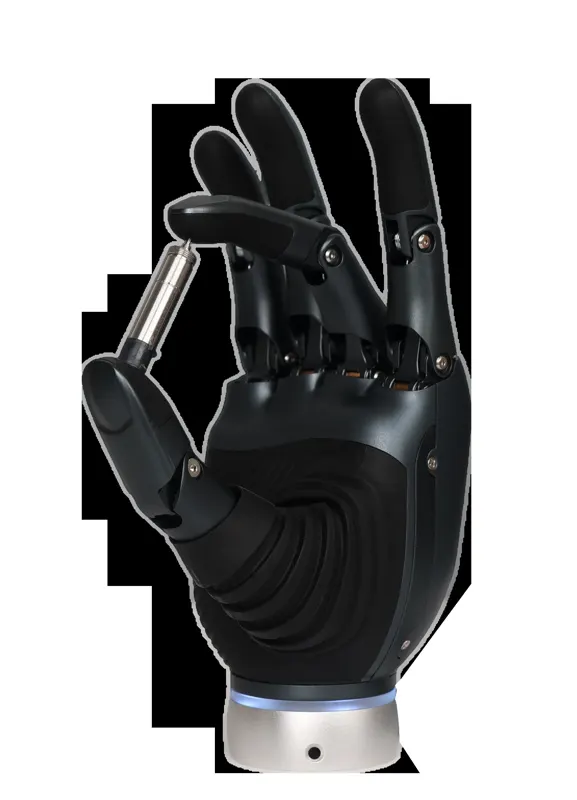
Touch the Future, Unleash Dexterity Without Limits An 11-DOF five-finger dexterous hand designed for reliable, high-frequency manipulation, with optional tactile sensing for adaptive gripping.
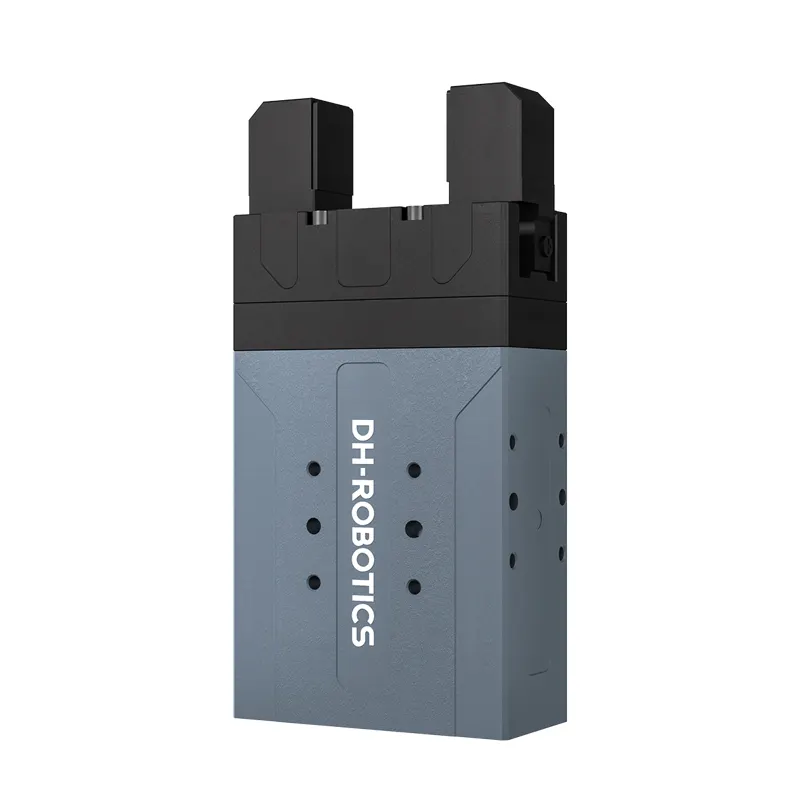
Industrial Slim-type Electric Parallel Gripper A slim industrial electric parallel gripper for precise, high-speed handling in confined automation spaces.
Talls Gear TS-DH02. Proprietary micro-enveloping multi-tooth mesh reducer technology. Full-hand 20 DOF, grip 25kg, precision <±0.015mm, single joint torque 3kg. For humanoid dexterous hands and precision automation.
Talls Gear TS-DH01. Proprietary micro-enveloping multi-tooth mesh reducer technology. Full-hand 20 DOF, grip 20kg, precision <±0.015mm, single joint torque 3kg. For humanoid dexterous hands and precision automation.
DH116 is a second-generation production five-finger dexterous hand: 11 DoF, 545 g, brushless coreless servo motors with worm-gear transmission and hybrid force-position control. 30 kg whole-hand payload, 5 kg per finger, 100 Mbps EtherCAT (CANFD/RS485), six multimodal tactile sensors, 1M-grasp lifespan.