Skip to content
←Back to Papers

PAPER DEEP DIVE

Open SourceTransformerGeneral Purpose Strategy

Octo: An Open-Source Generalist Robot Policy Based on Transformers

Octo is an open-source generalist robot policy using Transformers, enabling rapid fine-tuning across diverse robot platforms with multimodal inputs.

Octo is an open-source generalist robot policy using Transformers, enabling rapid fine-tuning across diverse robot platforms with multimodal inputs.

Related Papers

Scalable Open-Source Visuotactile Sensor for 6-Axis Contact Wrench Estimation in Tensegrity Robots

Scalable Open-Source Visuotactile Sensor for 6-Axis Contact Wrench Estimation in Tensegrity Robots

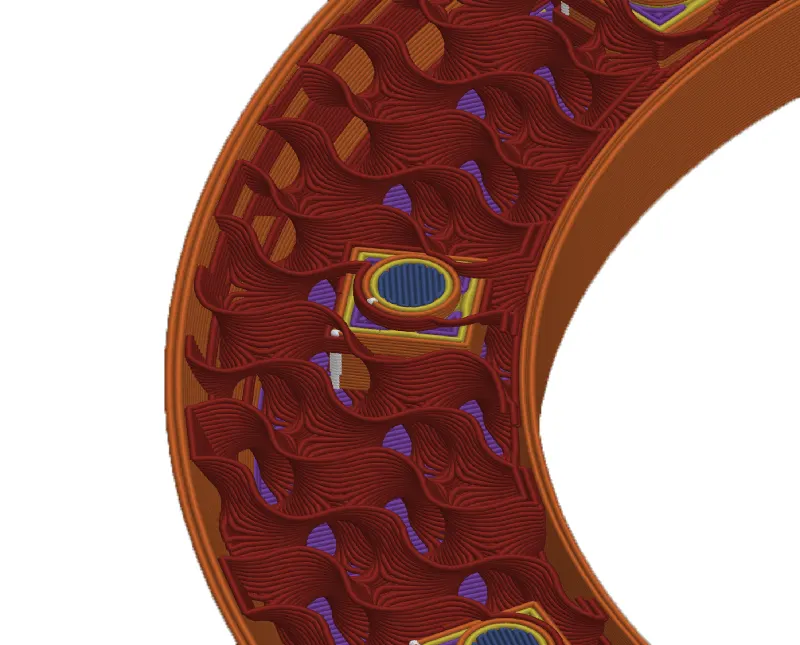
This paper presents a scalable, open-source visuotactile sensing system for tensegrity robots that enables six-axis wrench estimation and contact detection. The proposed endcap sensor integrates an elastomeric shell, a 3D-printed thermoplastic polyurethane (TPU) interface, and a rigid base housing an embedded camera and LED illumination ring. A novel gyroid-infill bonding technique is introduced to form a durable elastomer-TPU interface without adhesives, yielding a lightweight and modular design compatible with large-scale tensegrity structures. A tactile-to-wrench neural network maps shear vector fields to six-dimensional force and torque measurements. Experimental results demonstrate accurate and stable wrench estimation with a mean squared error (MSE) of 0.1531 on static validation data and out-of-domain generalization under dynamic motion. Furthermore, full-system integration on a 12 kg tensegrity robot confirms the sensor's ability to reliably identify ground contacts. The system substantially improves the practicality of tactile feedback for tensegrity robots, offering a low-cost, reproducible, and physically interpretable pathway toward contact-aware proprioception and state estimation. Open source files are available at https://github.com/Jonathan-Twz/tensegrity-gelfoot

Wenzhe Tong, Jonathan Mi, Xili Yi · 288 views · Jul 17, 2026
Tactile SensingTensegrity6-Axis ForceJul 17, 2026
MEVION: Low-Cost Open-Source Data Collection System for Powerful and High-Speed Dual-Arm Manipulation

MEVION: Low-Cost Open-Source Data Collection System for Powerful and High-Speed Dual-Arm Manipulation

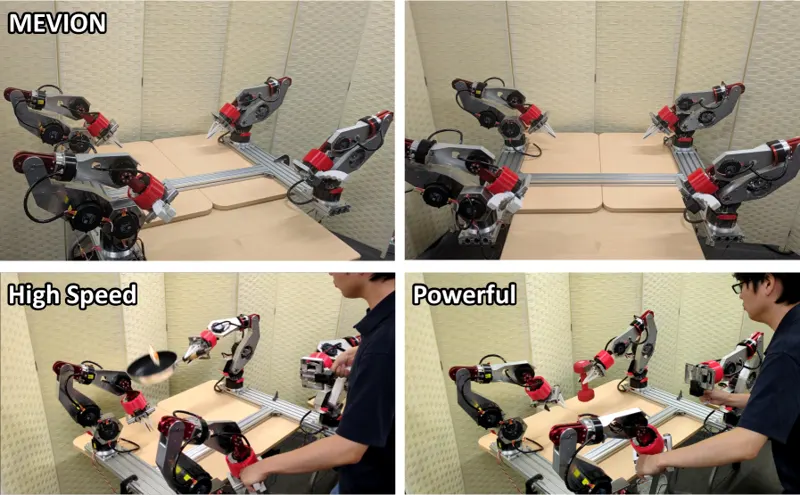
The global competition for developing robotic foundation models is intensifying. Among the data collection systems used for dual-arm robots, ALOHA is representative of being low-cost and open-source, and is widely adopted by researchers as a de facto standard. However, due to its limited ability to generate high forces and speeds, it is difficult to handle heavy objects or perform fast manipulations. To address this, we developed MEVION, a low-cost and open-source dual-arm robot data collection system capable of generating greater force and speed. All parts of this robot can be sourced through e-commerce, and by extensively utilizing sheet metal welding, its large body structure is constructed with a small number of components at low cost, while also simplifying assembly. MEVION is equipped with four 6-DoF arms with parallel grippers. Each arm weighs 7.0 kg and has a maximum torque of 60 Nm, and the entire system can be constructed for about USD 14,000. The elbow joint adopts a closed-link mechanism similar to those used in quadruped robots, which reduces the distal mass and enables higher force and speed output at the end-effector. We demonstrate that MEVION enables data collection for object manipulation tasks not previously possible and supports imitation learning-based motion generation. All hardware and software of this work are included in the Supplementary Materials or https://github.com/haraduka/mevion.

Kento Kawaharazuka, Yoshiki Obinata, Hirokazu Ishida · 351 views · Jul 20, 2026
Data CollectionDual-ArmOpen SourceJul 20, 2026
PAPERdexpoint-2024DexPoint:Generalizable PointCloud Policies forDextero…Point c…Manipul…

DexPoint: Generalizable Point Cloud Policies for Dexterous Manipulation

DexPoint uses point cloud representations for generalizable dexterous manipulation without CAD models, showing strong sim-to-real transfer.

CMU, UC Berkeley · 429 views · Nov 17, 2022
Dexterous HandPoint cloudsManipulationNov 17, 2022
GigaBrain-WBC-0.5: A Behavior World Model for Robust Whole-Body Control with Environment Interaction

GigaBrain-WBC-0.5: A Behavior World Model for Robust Whole-Body Control with Environment Interaction

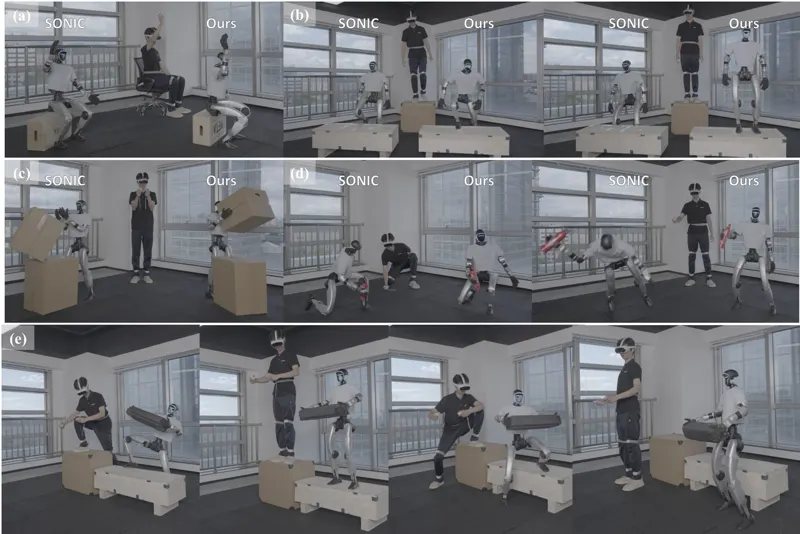
The first Behavior World Model (BWM) for humanoid whole-body control. A causal Transformer jointly predicts next action, state, and latent behavior command distribution, enabling the policy network to model how the environment shapes actions. Automatic terrain-annotation pipeline recovers 3D contact geometry from retargeted motion. At deployment, implausible commands are detected and retracted onto learned behaviors. Achieves highest success rate across all four regimes: 81.3% terrain interaction, 83.1% under implausible commands, 99.3% fall recovery. Unitree G1 checkpoint transfers to Maker L01 robot.

Ziyang Cheng, Tianshu Tang, Jinxin Lan · 535 views · Aug 18, 2026
HumanoidWorld ModelsWhole-Body ControlAug 18, 2026

As an Amazon Associate, we earn from qualifying purchases.