A MuJoCo Sim of a Unitree G1 Visualizes the Zero-Moment Point
Loading video
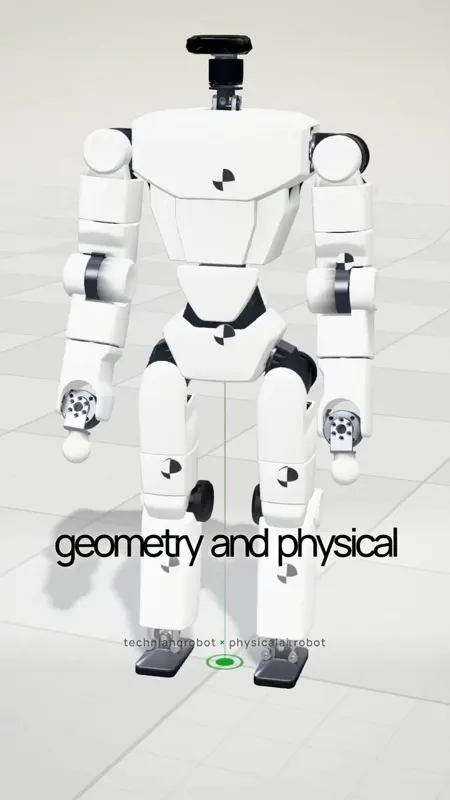
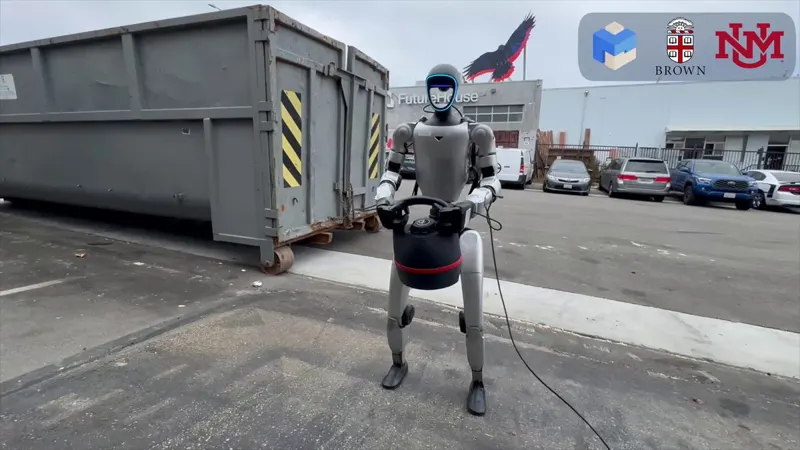
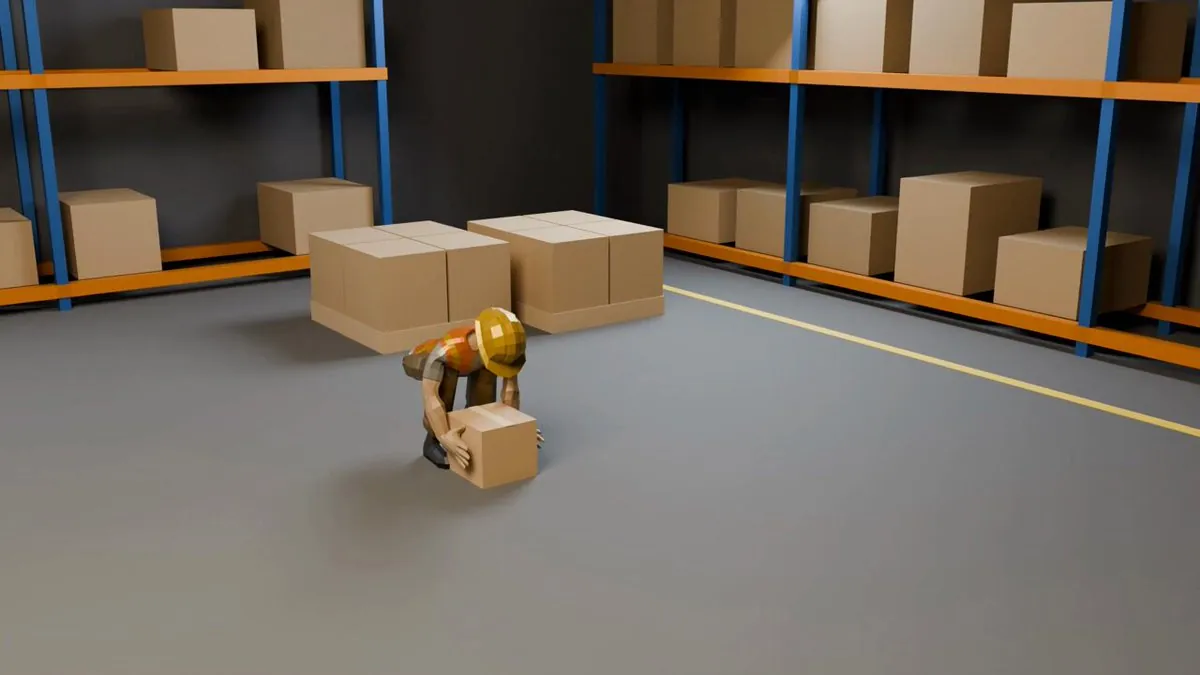
Loading videoA MuJoCo simulation of a Unitree G1 visualizes the Zero-Moment Point paper by Vukobratovic and Borovac: at 6 kg payload the ZMP slides toward the toes and the robot leans back to recover; at 16 kg it crosses the toe edge and no foot support remains.
Category: humanoid
Author: @AlloyRobotics
Date: 2026-10-14T00:00:00
Duration: 29.0s
Reference: https://doi.org/10.1142/S0219843604000083