OTRetarget: joint robot-and-object motion retargeting via optimal transport preserves contacts across morphologies
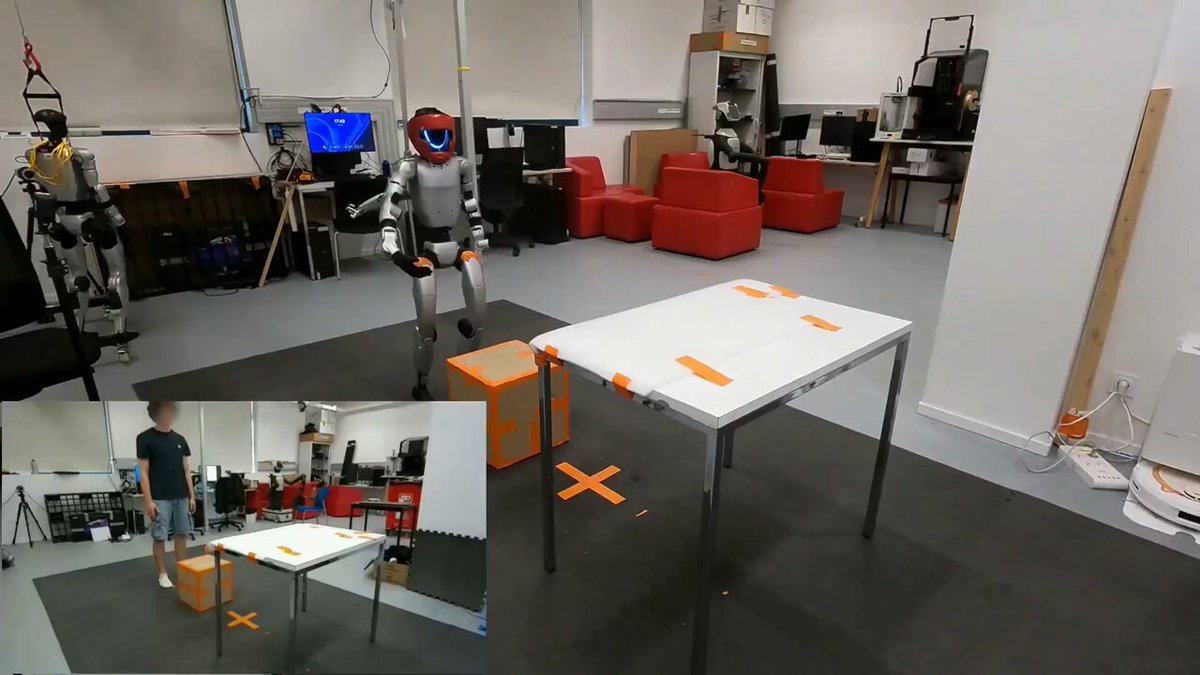
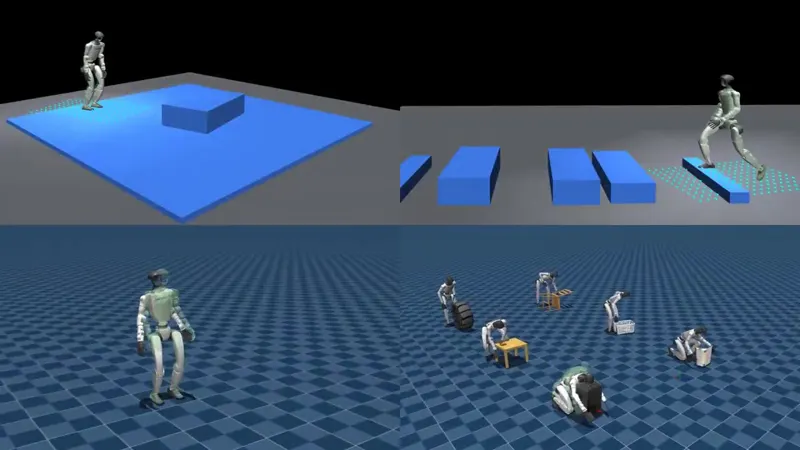
OTRetarget (arXiv:2609.36602) by the Simple Robotics team (Guillaume Besset, Erwann Carn et al.) jointly retargets robot and multi-object motion from human demonstrations: surface interactions are described by signed distances, closest witness points, and relative directions; one entropic optimal-transport plan per human part and robot link (solved once in a T-pose) carries these targets across morphologies so fingertips and heels are not left behind. Interaction targets feed a constrained inverse-kinematics formulation that jointly optimizes robot and every object pose per frame, balancing contact preservation with motion style — robot-object and object-object interactions without rescaling the scene. On OMOMO it reaches 87% robot-object interaction Jaccard and 8.7 mm depth error vs OmniRetarget's 28% and 29.3 mm; one demonstration replays onto unseen object shapes (ball to beam), and a policy blind to the object completes pick-and-place on a physical Unitree G1.