RoboParty ROBOTO_ORIGIN: the second fully open-source humanoid shown at IROS — Taobao parts + JLCPCB prototyping, all structure/training/deployment code public
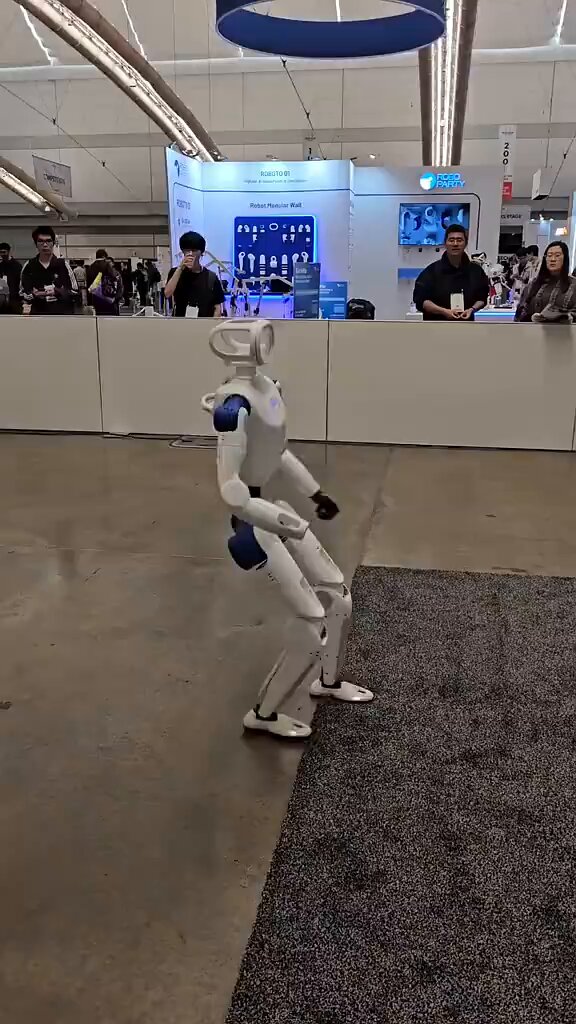
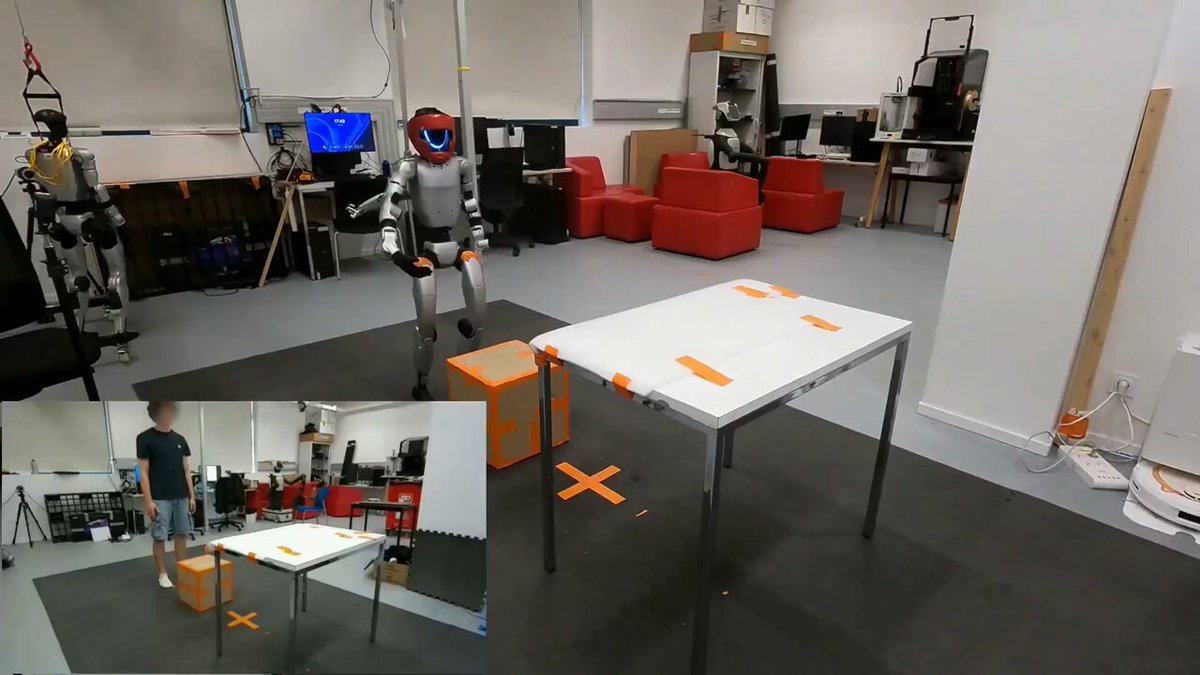
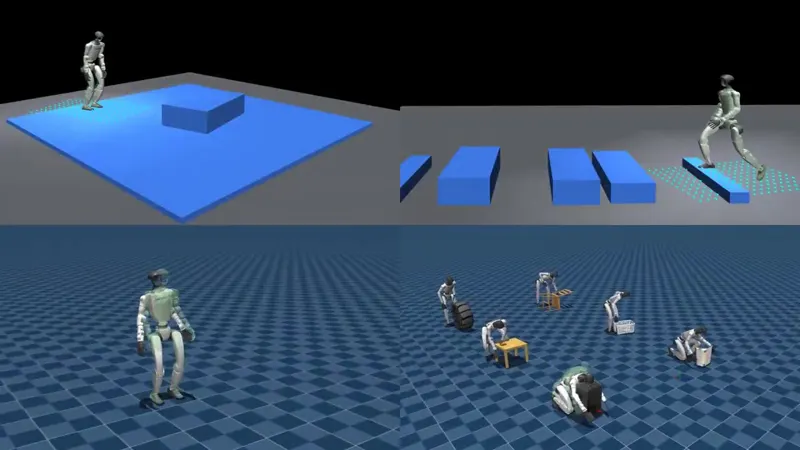
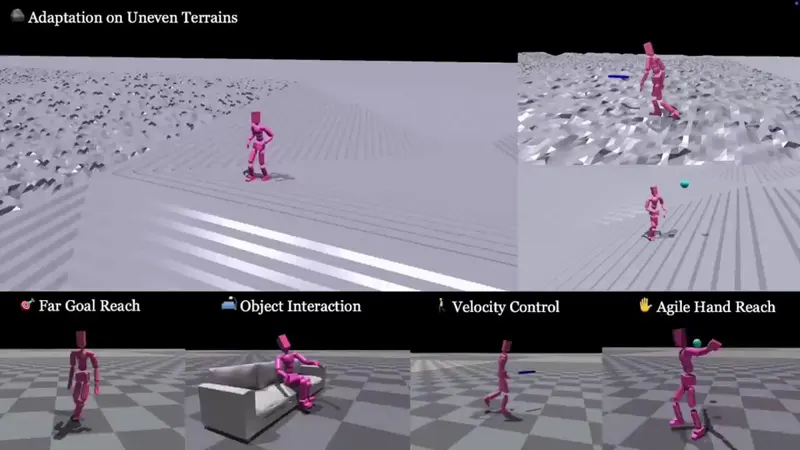
RoboParty (Shanghai, founded Feb 2025, prototype in 4 months) showed ROBOTO_ORIGIN at IROS — a fully open-source DIY humanoid (2,360 GitHub stars, GPL-3.0): the entire R&D process including structures, electronics, training and deployment is open; the robot can be fully assembled via Taobao procurement and JLCPCB prototyping, and the open training/deployment code gets it walking and running. Full ecosystem repos: rpo_hardware (structural drawings), roboparty_deploy (ROS2 modular middleware for IMU/motor drivers/inference), roboparty_train (direct IsaacLab training with Sim2Sim transfer to MuJoCo), navigation, xr_teleop, dexhand (CAN-FD dexterous-hand drivers), UFO (unsupervised RL for humanoid control with FB/TeCH training, robot-aware motion import and real-world teleoperation), and human-humanoid-tools (hhtools: retarget parkour/dance/interaction clips onto any humanoid in ~30 s, with robot-to-robot retargeting and Web-UI dataset analysis). Commentator clankrmedia notes that with ROBOTIS AI Sapiens, Asimov 1 and RoboParty all open this year, it feels like the early Llama era of open-source LLMs.