Isaac Lab-Arena 0.3: Scale Robot Policy Evaluation in Simulation
Loading video
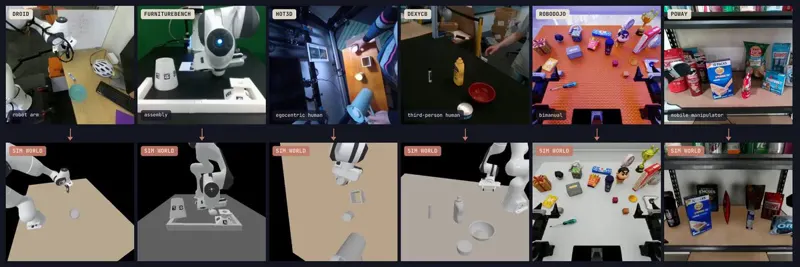
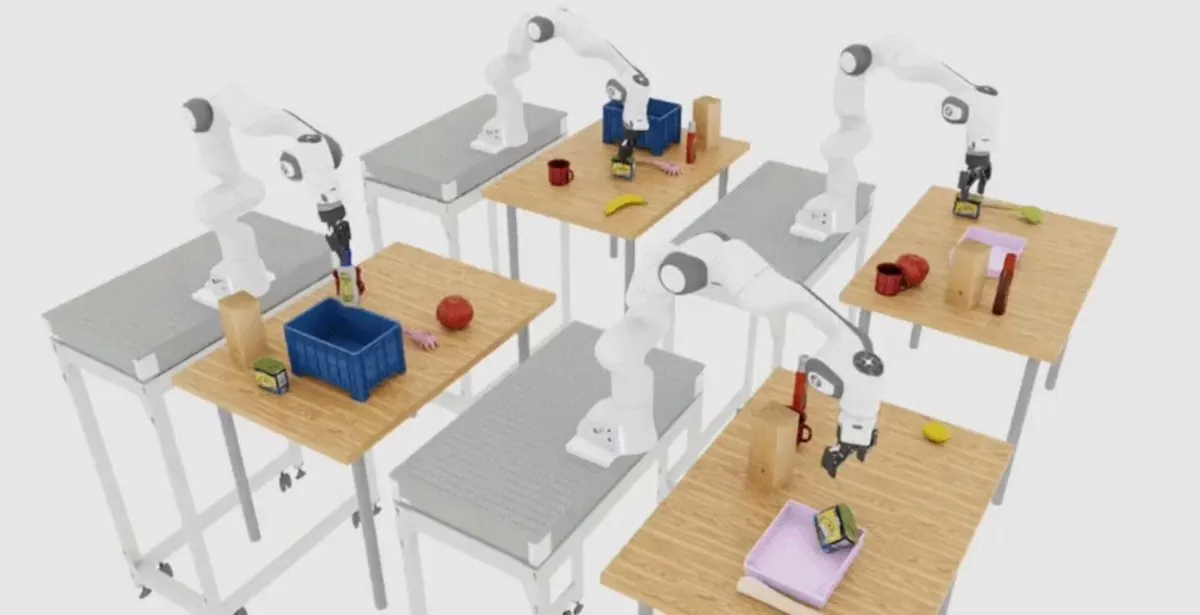
Loading videoA policy that succeeds in a demo can still fail as tasks, environments, and conditions change. Open-source Isaac Lab-Arena 0.3 adds an experimental agentic workflow that generates simulation environments from natural language, evaluates policies across thousands of parallel GPU environments, and pinpoints where and why failures occur.
Robotics SimulationPolicy EvaluationBenchmarksManipulationIsaac LabNVIDIAAgentic WorkflowRobot simulation
Category: research
Author: @NVIDIARobotics
Date: 2026-09-15T00:00:00
Duration: 14.421s
Reference: https://github.com/isaac-sim/IsaacLab-Arena