PiPER recovers after moving-target tests
Loading video
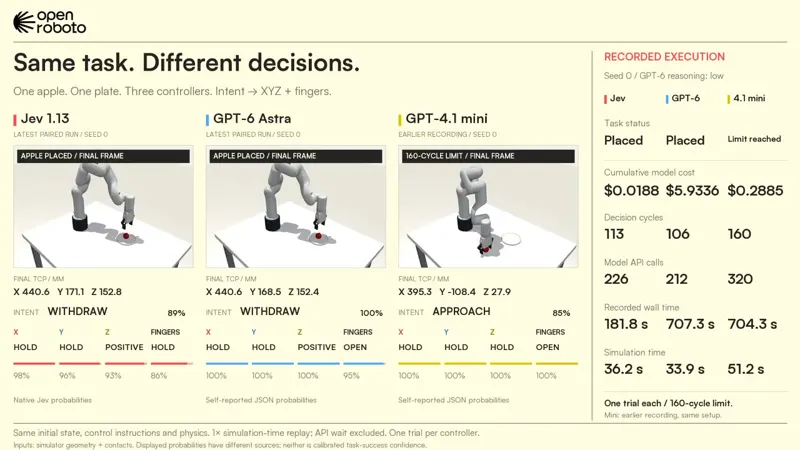
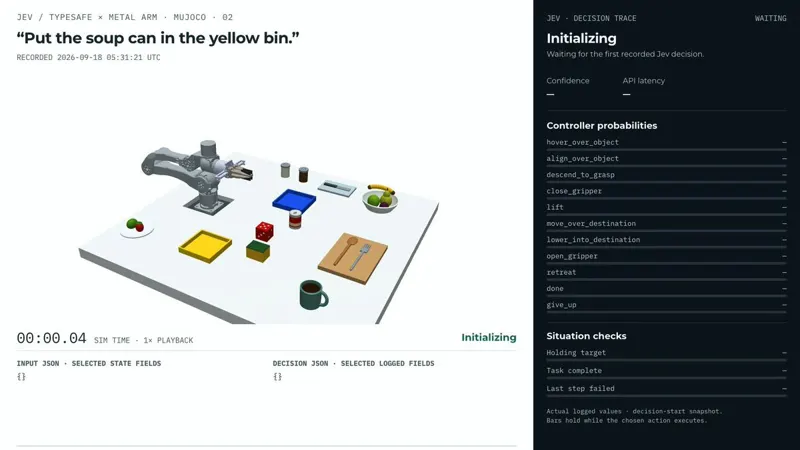
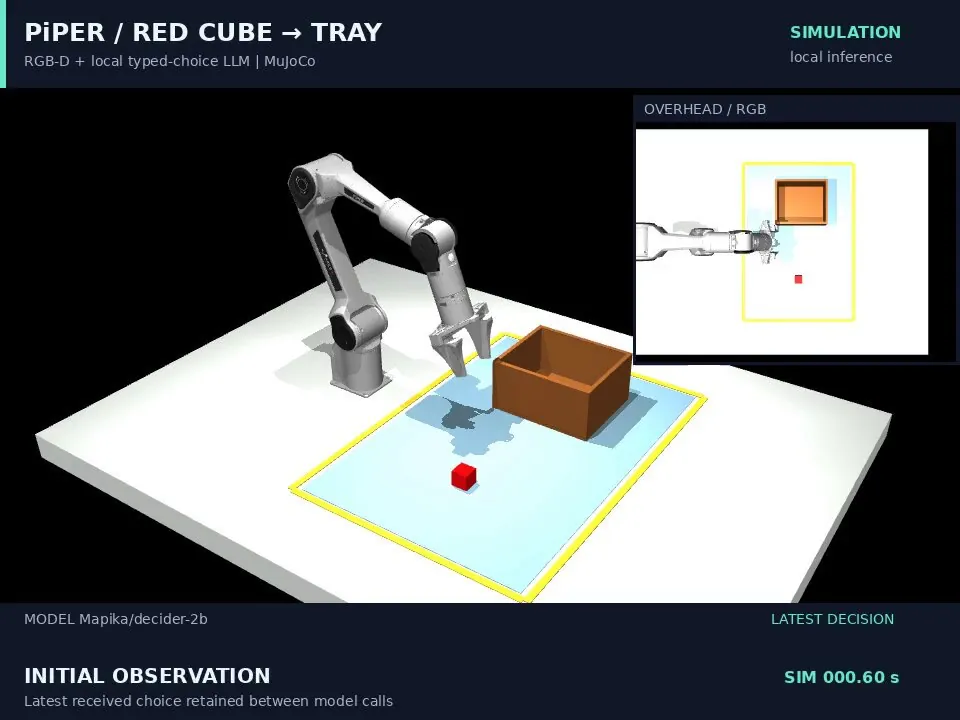
Loading videoIn an open-source MuJoCo sim, a local 2B model drives a PiPER arm through three target relocations per run, succeeding on 10/10 seeds at 32.6 ms median decision latency.
Category: arm
Author: @huxiao93612565
Date: 2026-09-21T00:00:00
Duration: 38.5s
Reference: https://github.com/Hu-xiao-max/jev_robot