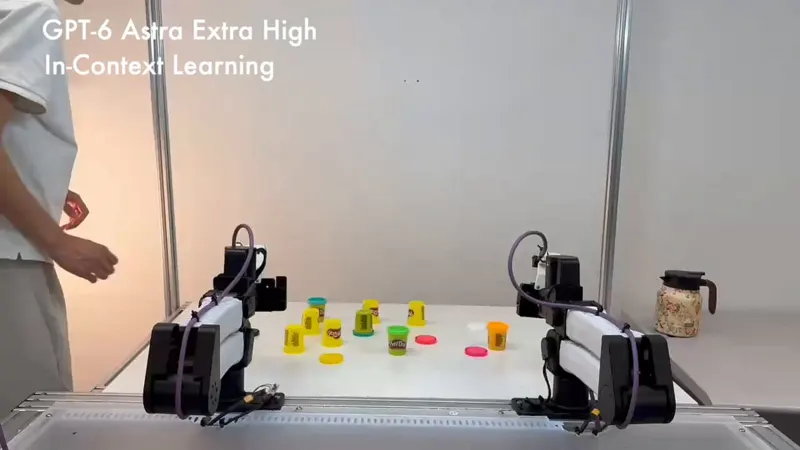
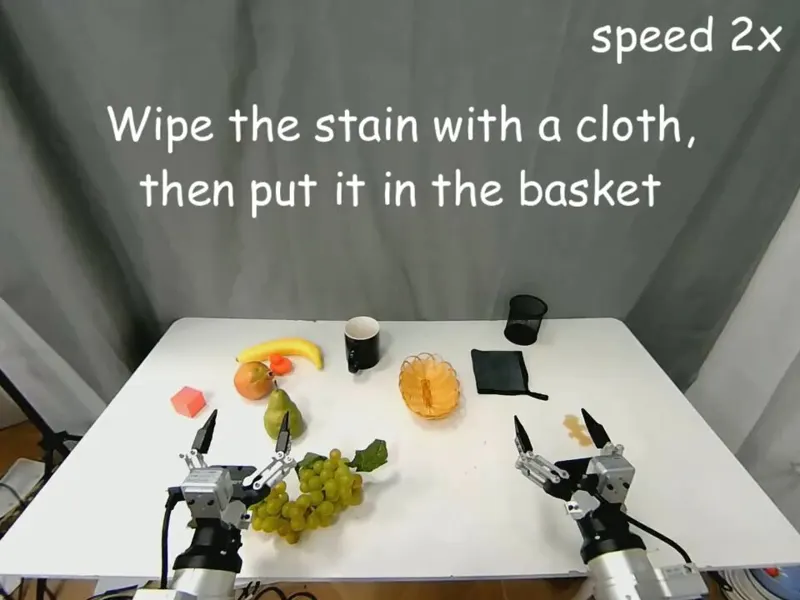
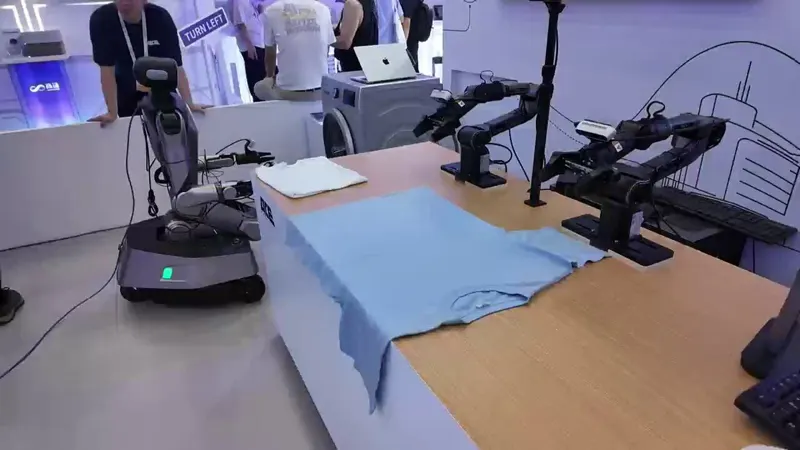
GPT-Policy: Dual-Arm Manipulation Learned In-Context from Demos
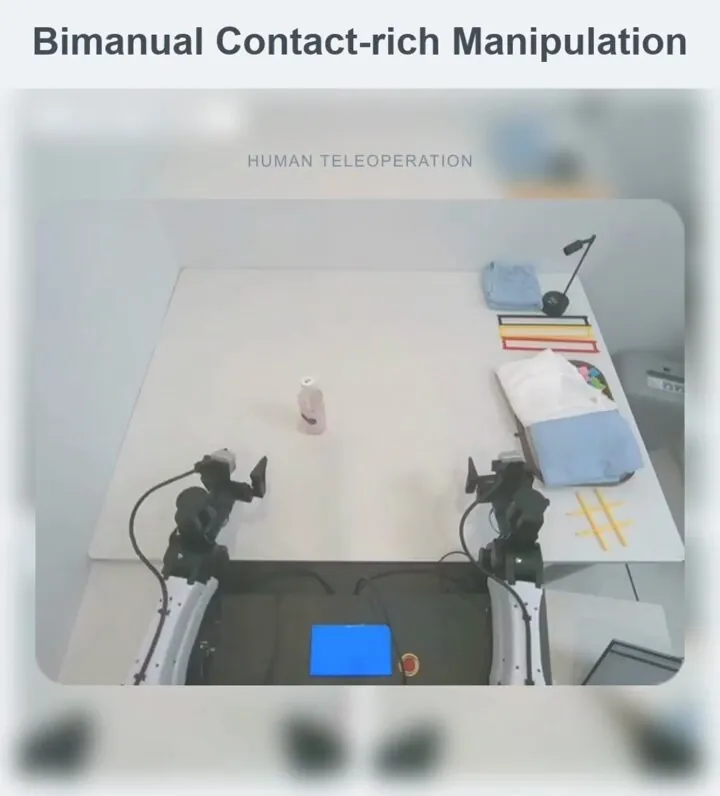
Loading video
Loading videoGPT-Policy releases code and new results: a fixed GPT-6 VLM, wrapped in a context compiler and a constrained Cartesian controller, drives dual arms in closed loop. Human video, goal images or a single demonstration let it perform occlusion-aware picking, bimanual contact-rich manipulation and gesture imitation zero-shot, with no gradient updates.
Category: arm
Author: @z_code68632
Date: 2026-09-15T00:00:00
Duration: 54.1s
Reference: https://github.com/cheng-haha/GPT-Policy