PragmaBot: Learning to Plan Tasks by Experiencing the Real World
Loading video
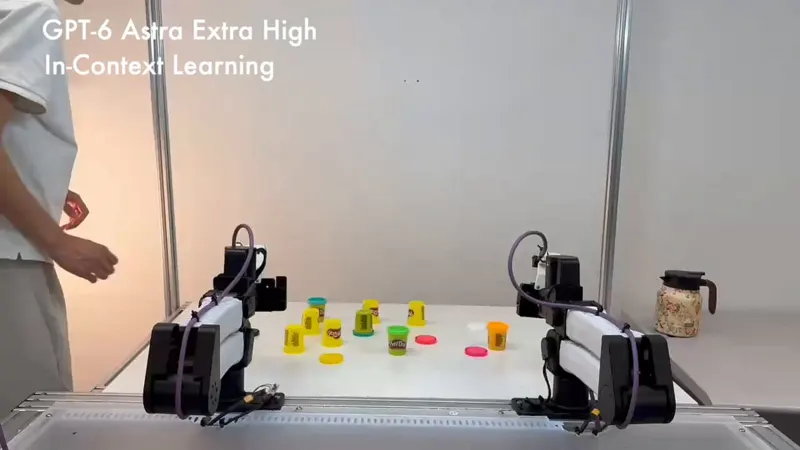
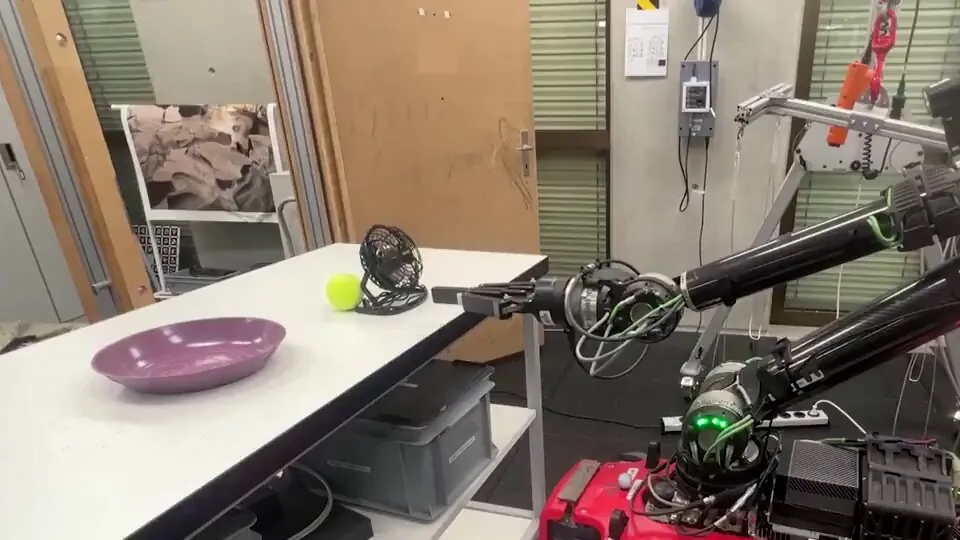
Loading videoPragmaBot uses a VLM as the robot eye and brain: it visually evaluates outcomes, self-reflects on failures and stores lessons in short- and long-term memory, then retrieves them via RAG to plan new tasks without any parameter update. Short-term reflection lifts success from 35% to 84%; long-term memory lifts single-trial success from 22% to 80% across 12 real-world scenarios. RA-L, IROS 2026.
VLMIn-Context LearningRobot ManipulationTask PlanningRA-LETH ZurichVision-language modelsRobotic Arm
Category: arm
Author: @leggedrobotics
Date: 2026-09-22T00:00:00
Duration: 42.389s
Reference: https://arxiv.org/abs/2507.16713