Jev drives a MuJoCo metal arm with nine typed decisions
Loading video
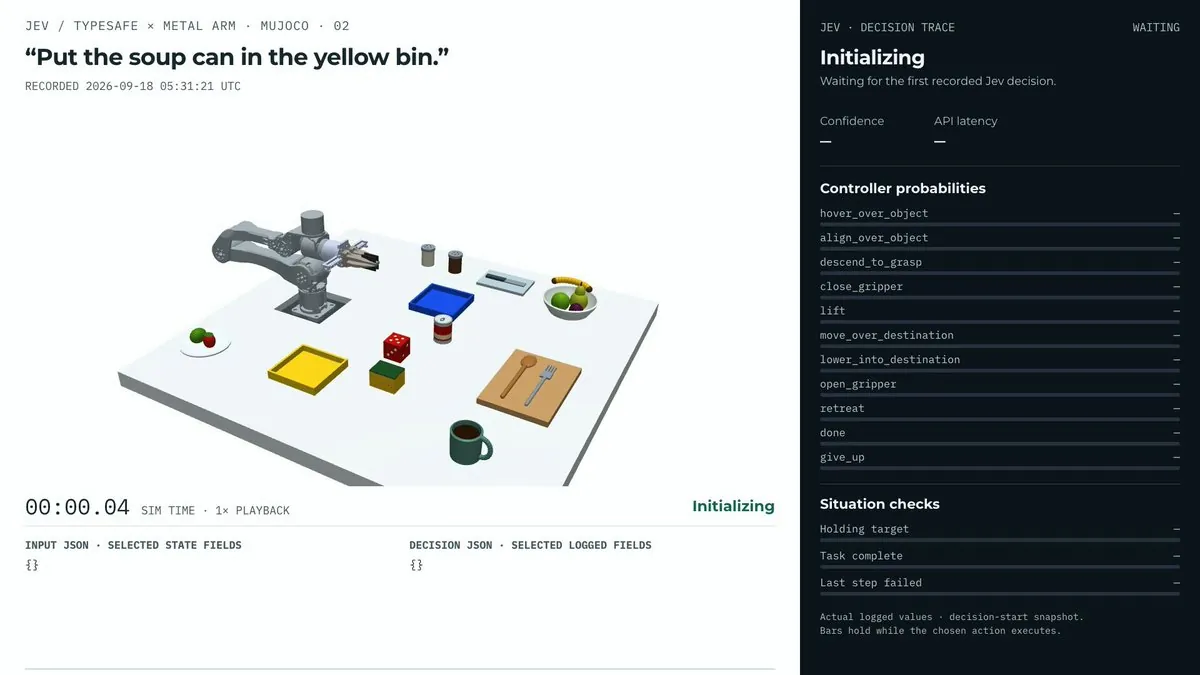
Loading videoJev (typesafe.ai) never sees the sim camera: MuJoCo hands it the environment state as JSON and it answers with bounded typed actions (hover, descend, grasp, lift, place) plus a confidence score. Put the soup can in the yellow bin takes 9 decisions at ~150 ms each, and unmappable tasks are refused rather than guessed.
Category: arm
Author: @IsaacSin12
Date: 2026-09-18T00:00:00
Duration: 36.333s